Related Experiment Video
Updated: Jul 4, 2026
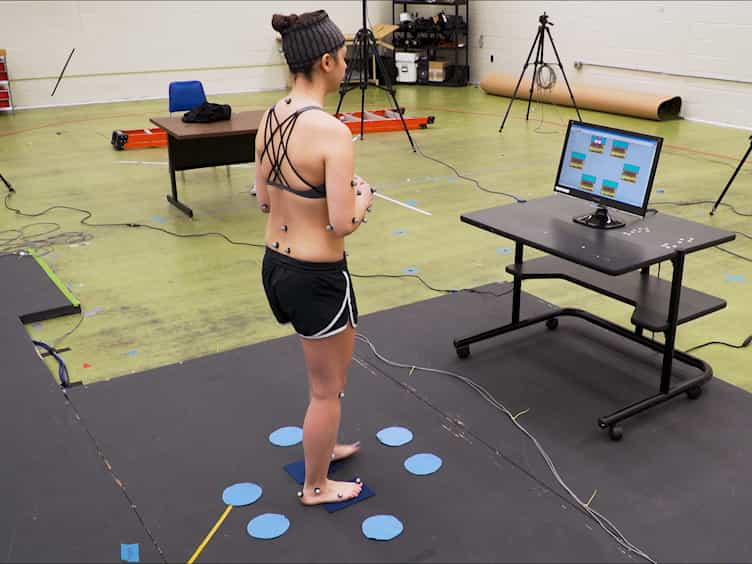

The "Motor" in Implicit Motor Sequence Learning: A Foot-stepping Serial Reaction Time Task
Published on: May 3, 2018
Dissociating the behavioral and computational features of implicit motor learning and explicit perturbation detection
Hyosub E Kim1,2, Jack O Darley1, Michael S Landy3
1School of Kinesiology.

Abstract:
The human sensorimotor system is remarkably effective at automatically parsing total movement error into its constituent parts, the error component due to a perturbation, or externally-generated error (EGE), versus the error component due to motor noise, or internally-generated error (IGE). Participants robustly, and implicitly, adapt to minuscule (2°) EGEs in the form of randomized visuomotor rotations while ignoring identically-sized errors caused by IGE. This error parsing, and its associated perceptual processes, directly contrasts previous work showing that humans must observe rotations that are > 1.5x the standard deviations of their motor variability, or ≥ 4°, before explicitly reporting their presence. While the combined results suggest a dissociation between perception for action-which allows for precise and automatic error parsing-and perception for conscious detection, this must be inferred across studies using different methodologies. Here, we combined a within-subjects study design and computational modeling to shed light on the principles underlying implicit adaptation to a perturbation and explicit perturbation detection. Neuro-typical adults participated in two experiments consisting of pseudo-randomized rotations during reaches to a single target, with one session requiring explicit reports after each reach of whether a perturbation was detected. Participants demonstrated a clear dissociation between implicit responses to a perturbation and explicit detection, with robust adaptation to 1° EGEs, but an inability to reliably report the presence of an EGE until it reached ~ 4°. For the adaptation task, a model that assumes the participant compares proprioceptive and visual cues to detect a perturbation and corrects for a proportion of this error best fit the data. For signal-detection, a Bayesian causal-inference model in which sensory cues are optimally integrated with a prior on their cause best fit those data. These results indicate that implicit adaptation is dissociated from explicit perturbation detection and the sensorimotor system applies distinct computational strategies to these behaviors.

Related Concept Videos
 01:24
Implicit Memories
One key aspect of implicit...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:22
Purposive Learning
 01:21
Cognitive Learning
E. C. Tolman's theory of purposive behavior emphasizes that much behavior is goal-directed. He argued that to understand behavior, we must look at the entire sequence of actions leading to a goal. For instance, high school students study hard, not just due to past reinforcement but also to achieve the goal of getting into a good college.
Tolman introduced the idea that behavior is influenced by...