Cooperative search algorithm for UAV swarm based on heterogeneous sensor fusion
Related Experiment Video
Updated: Jul 5, 2026
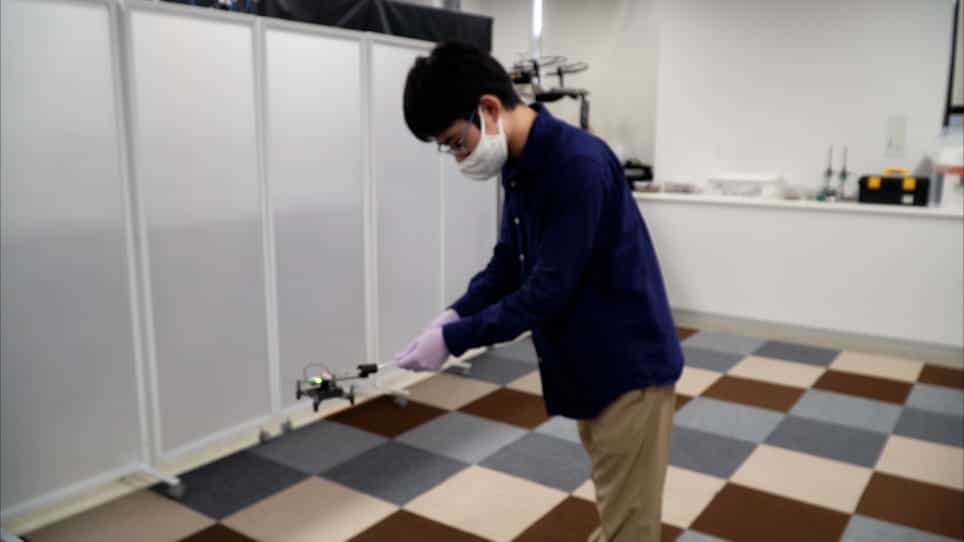
Electroantennography-based Bio-hybrid Odor-detecting Drone using Silkmoth Antennae for Odor Source Localization
Published on: August 27, 2021
Jingzhi Guo1,2, Zhe Li1,2, Zhihao Zhang3,4
1Air Traffic Control and Navigation School, Air Force Engineering University, Xi'an, 710051, China.

Abstract:
To address the limited robustness of single-sensor detection in complex environments, this paper proposes a cooperative search algorithm for unmanned aerial vehicle (UAV) swarm based on heterogeneous sensor fusion (HS-CS). The algorithm leverages the complementary detection capabilities of visible-light and infrared sensors as its core, and establishes a framework tailored to heterogeneous detection characteristics. Initially, the mission area is discretized into a grid, and a four-state map model-comprising undetected, visible-only, infrared-only, and heterogeneous fusion coverage-is constructed. Collaborative update and distributed fusion operators are designed to achieve accurate map updates. Subsequently, dual optimization objectives, total coverage and fusion coverage, are established, and a fast non-dominated sorting approach is employed to derive the Pareto optimal solution set. Finally, a multi-dimensional evaluation index is defined, and a four-stage adaptive evaluation function, integrated with a stochastic exploration mechanism, is developed to determine optimal actions for the UAVs. Simulation results demonstrate that, in a scenario containing 50 targets, 25 of which require fused detection as difficult targets, the proposed algorithm achieves an average fusion coverage rate of 97% and an average difficult target detection rate of 97.1% over 50 independent repeated experiments. These results indicate the potential of the HS-CS algorithm for cooperative search tasks.
Related Concept Videos
 01:30
Types of Global Positioning System Surveys
 01:30
Vector Functions and Motion: Problem Solving
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
 01:18
Uniform Depth Channel Flow: Problem Solving
 01:26
Vectors in Space: Problem Solving
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...