Related Experiment Video
Updated: Jul 9, 2026

Performing Microscope-Mounted Y-Shaped Cutting Tests
Published on: January 20, 2023
Dynamics of the cutting apparatus drive of a front-mounted header for grass harvesting
A Adilsheyev1, Zh Zhumagulov2, O Zhortuylov1
1"Scientific and Production Center of Agroengineering" Limited Liability Partnership, Almaty, the Republic of Kazakhstan.

Abstract:
In grass headers of self-propelled and trailed mower-conditioners, the drive of a double-knife cutting apparatus is implemented by two wobble-plate mechanisms mounted on the sidewalls of the header platform and interconnected by long intermediate shafts and couplings. This drive configuration is structurally complex and material-intensive, as it consists of two independent mechanisms. Based on an analysis of existing designs and studies of cutting apparatus drive mechanisms, a new crank-rocker mechanism with flexible elastic links is proposed for driving two knives. A distinctive feature of the proposed mechanism is that the movable flexible elastic links form a closed-loop contour. The use of flexible links makes it possible to reduce the weight and material consumption of the mechanism. Owing to the presence of flexible links, the mechanism does not require high manufacturing and assembly accuracy and is insensitive to frame deformations, which contributes to improved operational reliability. The principal advantage of the proposed crank-rocker mechanism with flexible elastic links is that a single mechanism provides the drive for both knives of the cutting apparatus. Differential equations of knife motion were derived, taking into account the elastic and damping properties of the flexible elastic links of the mechanism. Solving these equations made it possible to determine the kinematic parameters of the cutting apparatus, including knife displacement, speed, and acceleration, while accounting for technological and inertial loads. During the reciprocating motion of the two knives in antiphase, the inertial forces of the knives are not completely balanced. The unbalanced inertial forces caused by the elastic compliance of the flexible links are insignificant. The operating mode of the mechanism lies in the subresonant region of the amplitude-frequency response.
More Related Videos
 09:35
Measurement of the Hand Transmitted Vibration of the Human Hand Arm System During Operation of a Hand Tractor
Published on: June 16, 2021
 10:08
A Labor-saving and Repeatable Touch-force Signaling Mutant Screen Protocol for the Study of Thigmomorphogenesis of a Model Plant Arabidopsis thaliana
Published on: August 6, 2019
Related Concept Videos
 01:17
Rolling Resistance: Problem Solving
 01:09
Transmission Shafts: Problem Solving
Next, use bending moment diagrams for the shaft to...
 01:19
Machines
A free-body diagram of the...
 01:14
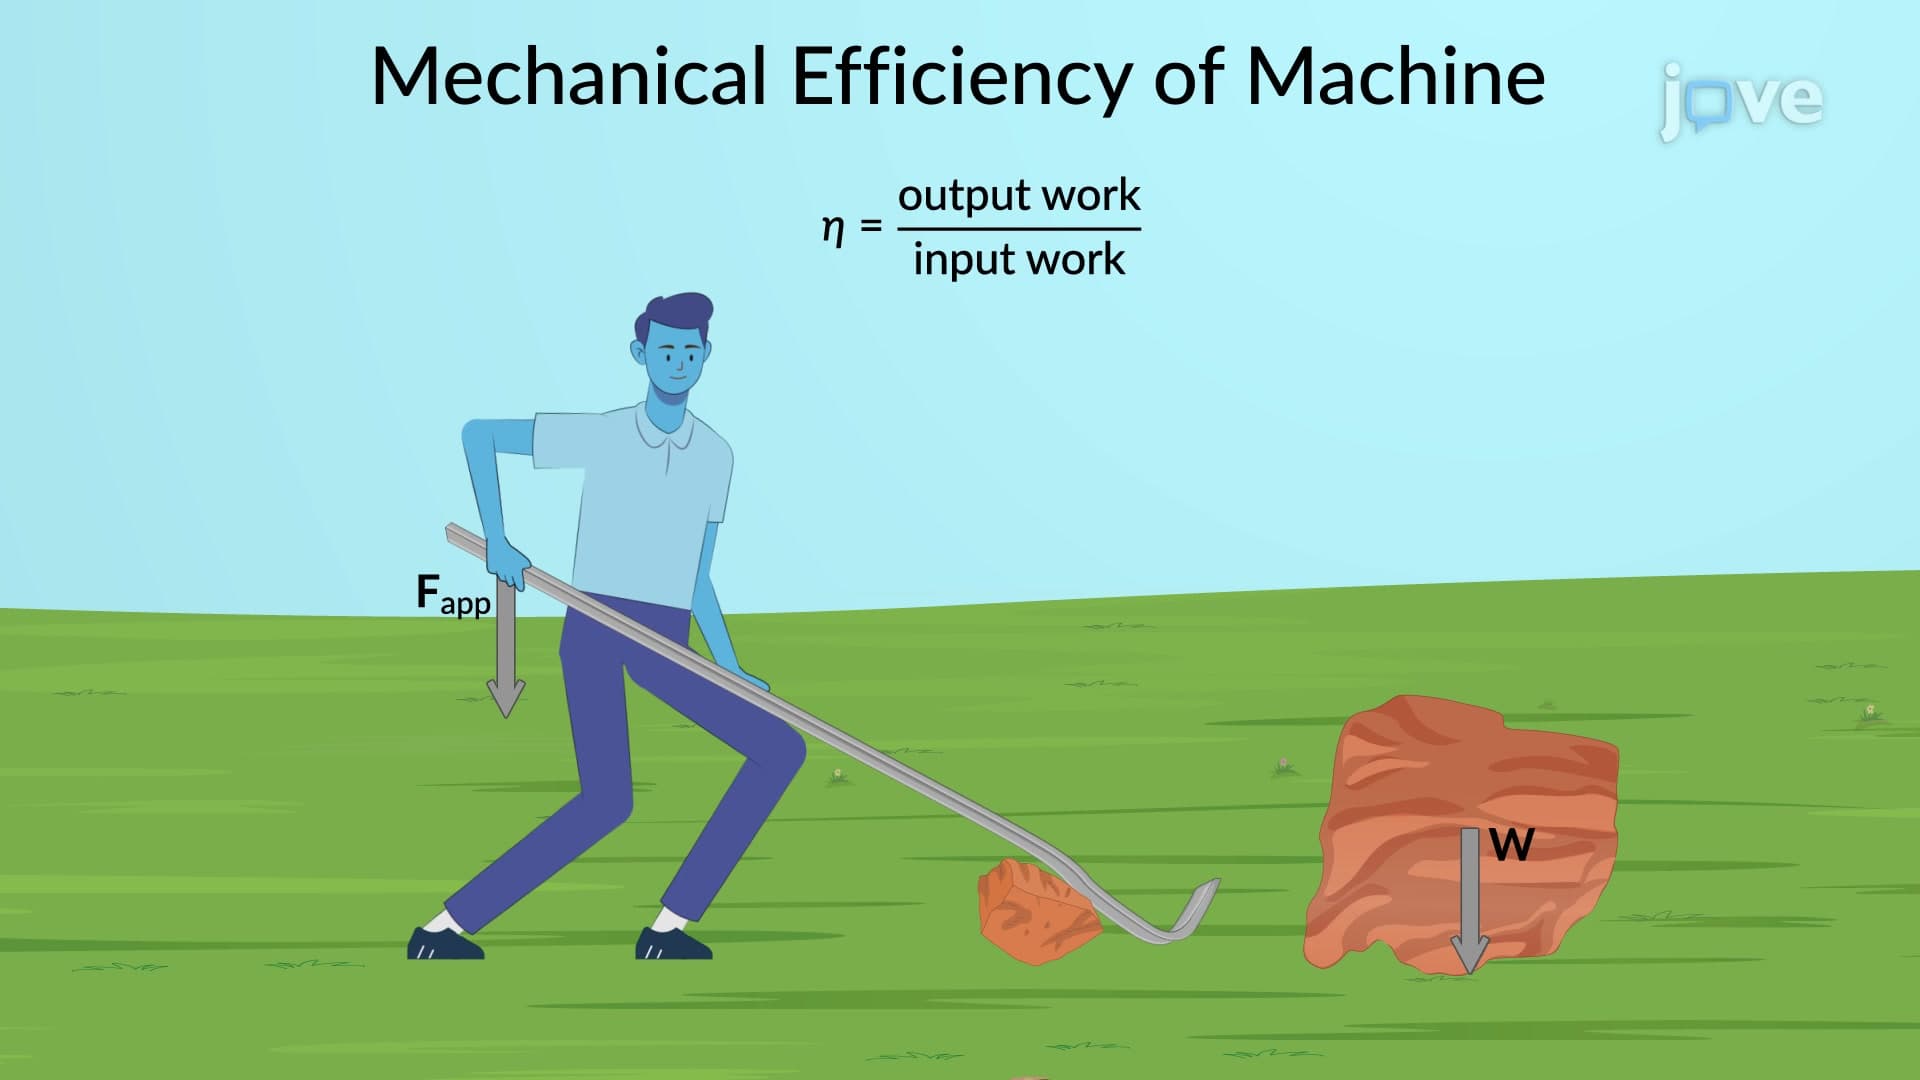
Mechanical Efficiency of Real Machines
However, in reality, no machine can be truly ideal, and all of them experience some...
 01:16
Equation of Motion: General Plane motion - Problem Solving
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...
 01:24
Wind Turbine Machine Models
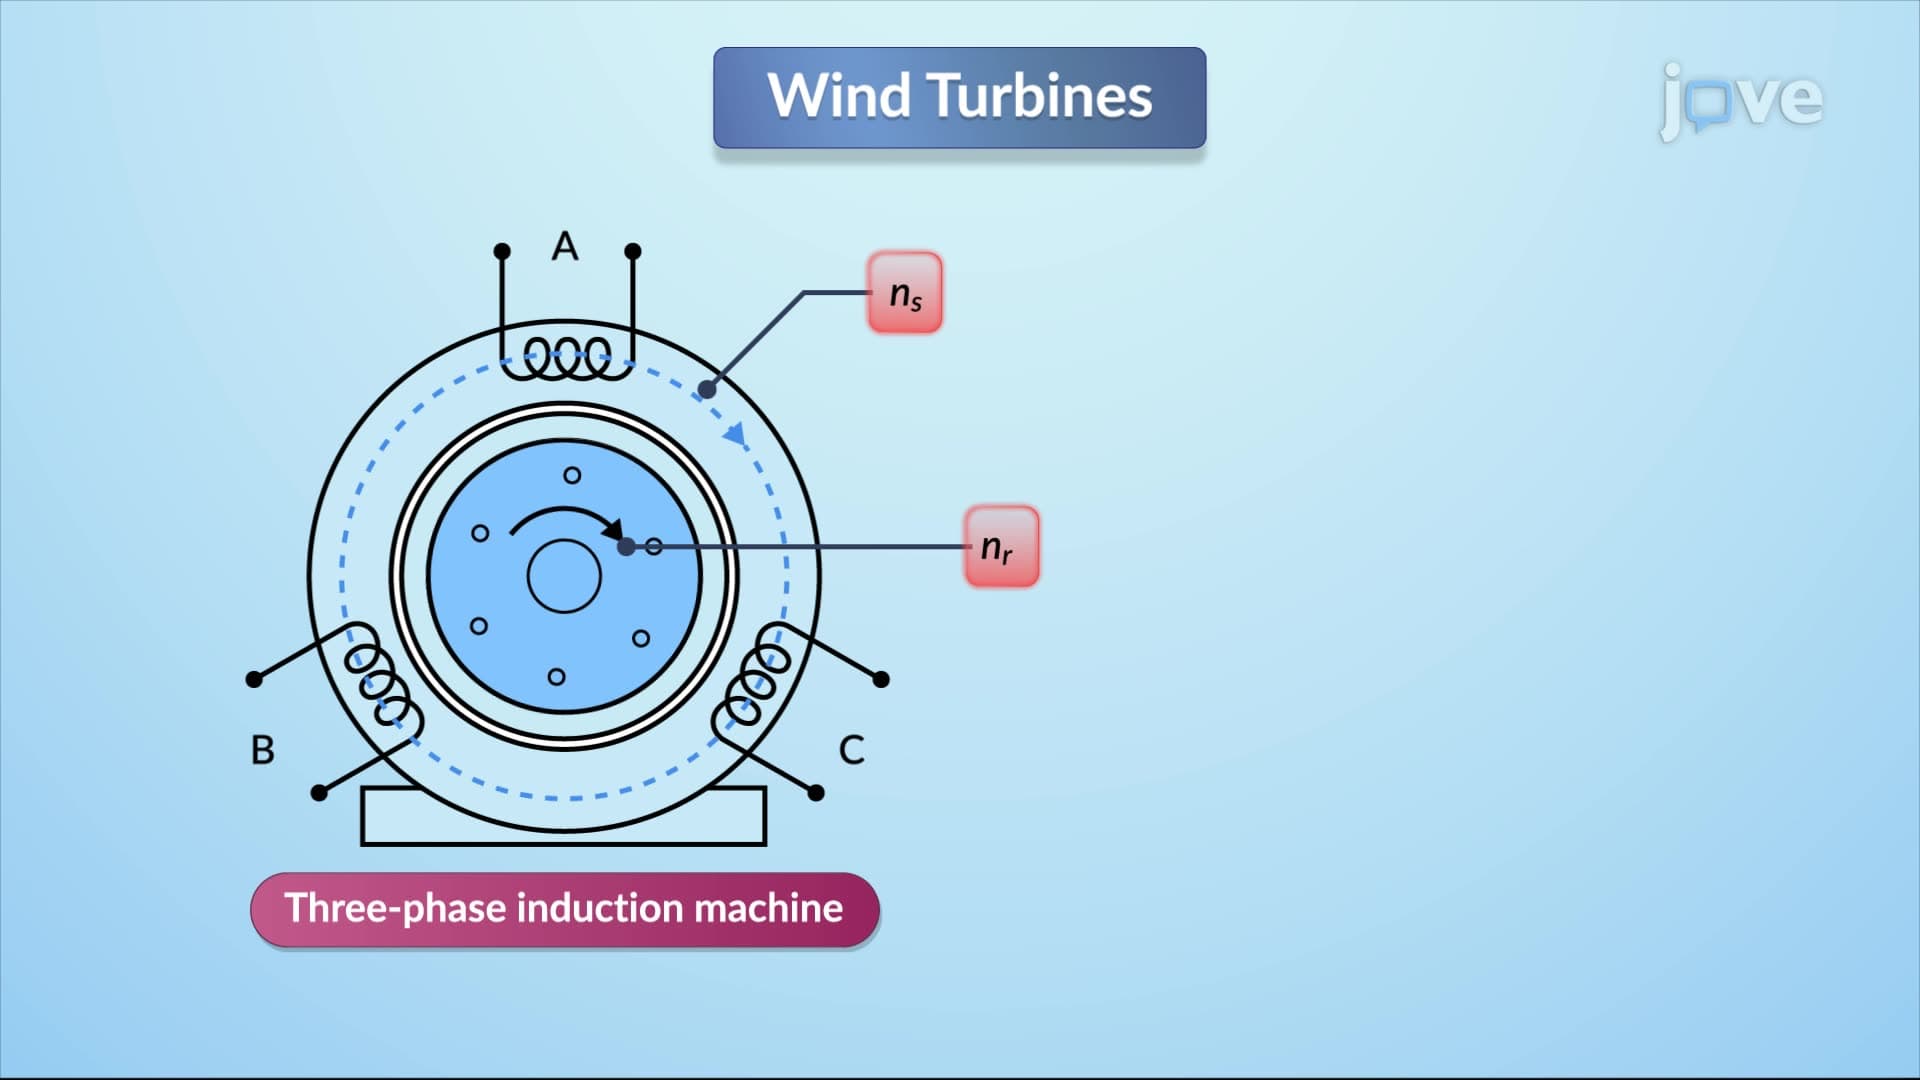
Induction machines interact through the rotating magnetic field generated by the stator and the rotor. The key parameter is slip, which is the difference between synchronous speed and rotor speed relative to synchronous speed. Slip is...