Related Experiment Video
Updated: Aug 6, 2026
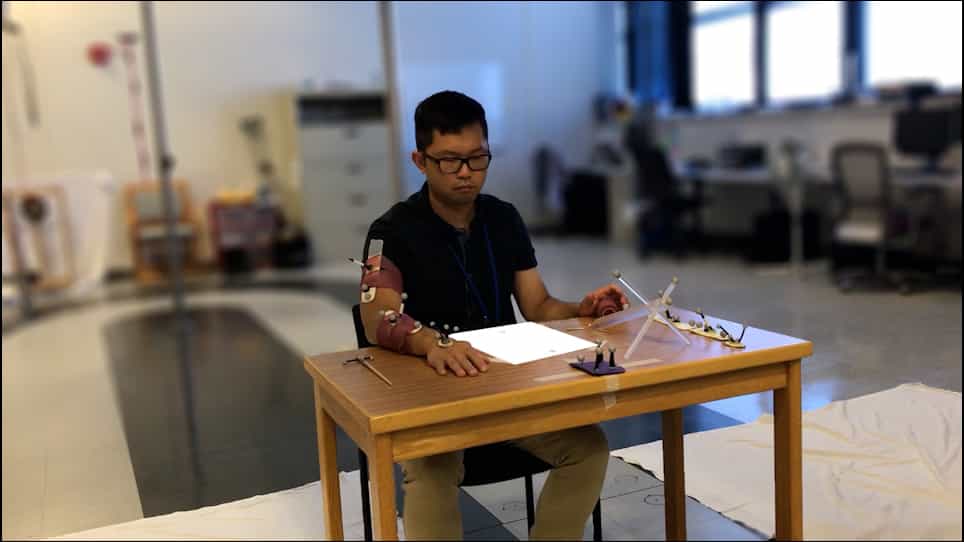

The Impact of Motor Task Conditions on Goal-Directed Arm Reaching Kinematics and Trunk Compensation in Chronic Stroke Survivors
Published on: May 2, 2021
Invariant properties of upper limb movement trajectory control
Shriniwas Patwardhan1, Jonathon Schofield2, Wilsaan M Joiner3
1Department of Bioengineering, George Mason University, Fairfax, VA 22030, United States of America.

Abstract:
Objective.Human movements often follow smooth trajectories predicted by the minimum-jerk trajectory (MJT) model, suggesting that the motor system optimizes motion smoothness during planning. While MJT-like behavior has been extensively studied in reaching movements, it remains unclear whether these trajectory properties are preserved across different control modalities, visual feedback conditions, and limb status.Approach.We examined the effects of control modality (reaching versus muscle-based control), visual feedback (present versus absent), and limb status (intact limb versus limb difference) on movement trajectory generation. Thirteen participants, including three individuals with upper-limb difference, performed virtual cursor movements to varying target distances. Peak velocity, movement time, position error, and adherence to MJT-like trajectory structure were analyzed.Main results.Across all experimental conditions, movements exhibited bell-shaped velocity profiles and amplitude-dependent scaling of peak velocity and movement time. These features persisted in the absence of visual feedback and in participants with limb difference. Position error increased when visual feedback was removed, but the overall smoothness and structure of the trajectories remained consistent with MJT predictions.Significance.These findings suggest that MJT-like movement structure is robust across variations in control modality, visual feedback availability, and limb status. The results support the idea that smooth movement planning reflects a generalized property of motor control and provide insight for the development of biologically inspired assistive and human-machine interface systems.
Related Concept Videos
 01:26
Orthogonal Trajectories
 01:30
Vector Functions and Motion: Problem Solving
 01:10
Relative Motion Analysis - Acceleration
 01:15
Bones of the Upper Limb: Ulna
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...