Related Experiment Video
Updated: Aug 6, 2026
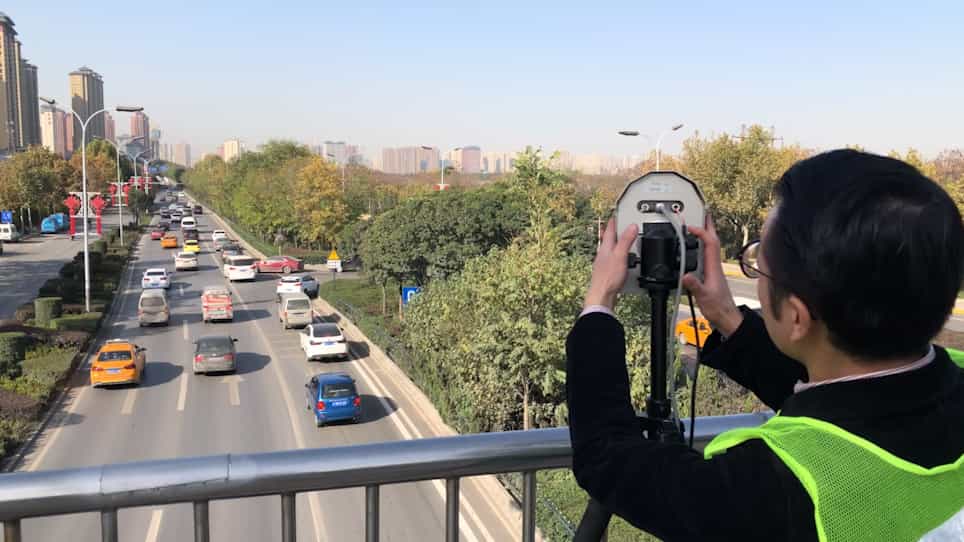

Evaluation of an Exclusive Spur Dike U-Turn Design with Radar-Collected Data and Simulation
Published on: February 1, 2020
Dynamic driving risk quantification and Informer-based prediction for heavy vehicles during right turns at
Wenping Li1,2,3, Bo Xu1,2,3, Baikun Zhu1,2,3
1Jiangsu Key Laboratory of Urban ITS, Southeast University, Nanjing, China.

Objective:
The right-turn risk of heavy vehicles at urban intersections has become a significant challenge for urban traffic safety management. However, most existing studies focus on static risk factors, lacking dynamic risk quantification and prediction for heavy vehicles in high-risk right-turn scenarios. This study aims to propose a dynamic risk quantification method and introduce an advanced deep learning model to predict driving risk effectively.
Methods:
An entropy weighting method based on sliding time windows was proposed to dynamically quantify the right-turn driving risk of heavy vehicles at intersections. An Informer model was introduced to predict driving risk, and observation, interval, and prediction time windows were defined to generate model inputs and outputs. To validate the model performance, the Long Short-Term Memory (LSTM), Convolutional Neural Network-Bidirectional Attention-LSTM (CNN-Bi-Attention-LSTM), and Transformer were employed for comparison.
Results:
The results showed that under a 1 s interval time window, the Informer model performed best with a 10 s observation window and a 5 s prediction window. It achieved a prediction precision of 82.69% and an inference time of only 0.014 ms per sample. Compared with other models, the Informer model significantly improved the accuracy and efficiency of long-term risk prediction.
Conclusions:
This study provides an effective method for driving risk prediction for heavy vehicles at urban road intersections, addressing the limitations of traditional static risk analysis and providing technical support for active safety management.

Related Concept Videos
 01:17
Rolling Resistance: Problem Solving
 01:30
Vector Functions and Motion: Problem Solving
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:29
Real-World Applications of Space Curves
 01:17
Friction: Problem Solving
Initially, a visual representation of the...
 01:29
Sight Distance in a Vertical Curve