An Ultra-Compact ARCL-Based MEMS Radar Filter for Mobile Robotic Platforms
Related Experiment Video
Updated: Aug 5, 2026
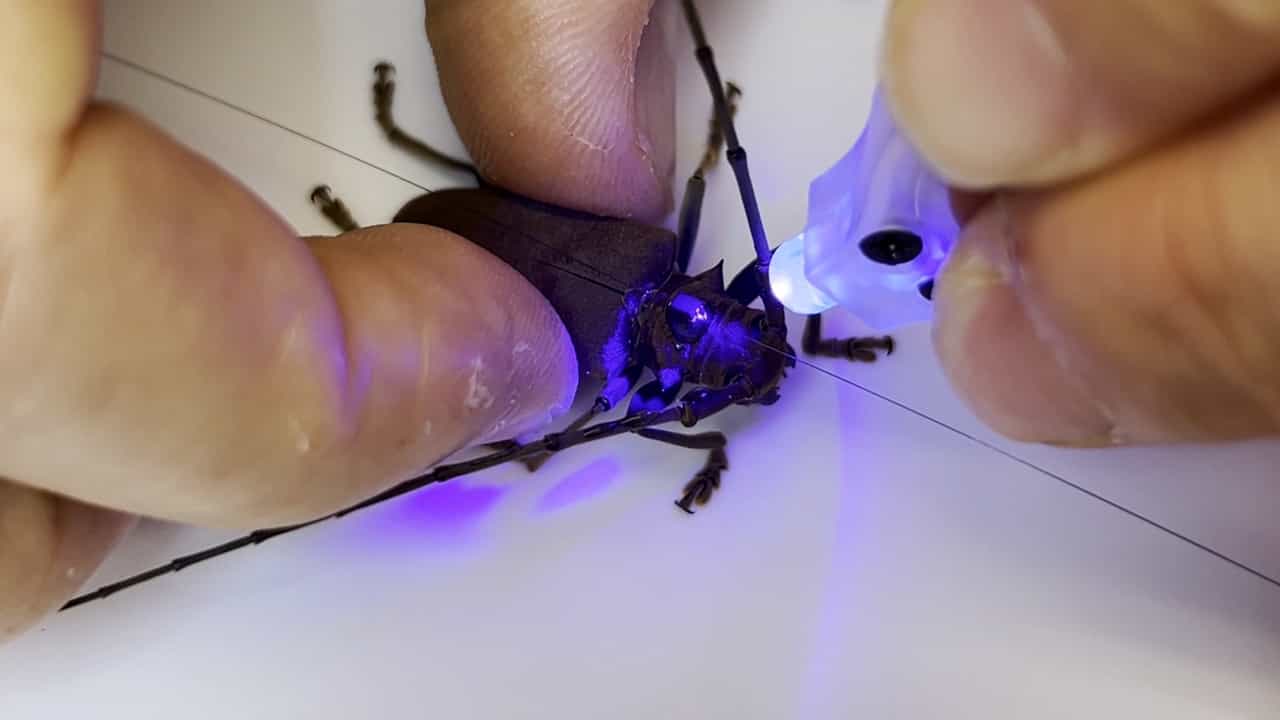
Harmonic Radar Tags for Insect Tracking: Lightweight, Low-cost, and Accessible
Published on: May 13, 2025
Yan Ding1,2, Ruiqi Zhang1, Xing Fan1,2
1School of Information and Control Engineering, University of Emergency Management, Langfang 101601, China.

Abstract:
To address the stringent requirements for miniaturization and high reliability in the perception systems of mobile robotic platforms, this article presents an ultra-compact bandpass filter based on air core recta-coax lines using micro-electro-mechanical systems technology. The proposed filter features an air-filled cavity structure with internal coupled lines and a fully enclosed metal shield, which effectively minimizes dielectric and radiation losses while achieving a highly compact footprint. This compactness is particularly critical for robotic radar front-ends, where limited payload capacity demands high integration density. By leveraging classical filter synthesis theory, the design achieves a high-order response within a minimized volume. Furthermore, the inherent high-Q characteristic of the air cavity significantly improves out-of-band rejection, thereby effectively suppressing interference in complex electromagnetic environments and enhancing the signal-to-noise ratio for robotic detection. A prototype operating at 75 GHz was fabricated and measured. The experimental results demonstrate a low insertion loss of 1.5 dB and a compact size of 0.875 mm3, showing reasonable agreement with simulations. The proposed design offers a promising solution for next-generation, high-performance sensing units in autonomous robotics.