Related Experiment Video
Updated: Aug 5, 2026


Trajectory Data Analyses for Pedestrian Space-time Activity Study
Published on: February 25, 2013
IPLG: Intent-Propagated Lane Graph for Multimodal Trajectory Prediction at Urban Intersections
Yibo Xu1, Yajie Zou1, Yichuan Peng1
1Key Laboratory of Road and Traffic Engineering of Ministry of Education, Tongji University, Shanghai 201804, China.

Abstract:
Vehicle trajectory prediction at urban intersections is challenging due to strong maneuver ambiguity, dense agent interactions, and complex lane branching structures. Existing methods frequently suffer from mode collapse or fail to provide sufficient coverage across all competing exit branches, limiting their reliability in safety-critical scenarios. This paper proposes IPLG, an Intent-Propagated Lane Graph framework for multimodal vehicle trajectory prediction at UAV-observed urban intersections. The proposed framework addresses two core challenges: the semantic ambiguity of lane nodes at divergence points under competing agent intentions, and the tendency of standard decoders to generate trajectories that deviate from valid lane regions. To this end, IPLG introduces a closed-loop interaction module that propagates agent intent cues into the lane graph and along its topology, a topology-aware diversified goal selection strategy that suppresses goal clustering across competing exit branches, and a residual decoder that enforces local lane consistency at each prediction step. Experiments on the XJROAD dataset show that IPLG achieves consistent performance across multiple evaluation metrics, with noticeable improvements in Miss Rate and Off-road Rate. Additional validation on the public nuPlan dataset demonstrates that the proposed model can generate plausible trajectories across different intersection geometries, further supporting its generalizability across diverse road structures and driving scenarios.
Related Concept Videos
 01:26
Orthogonal Trajectories
 01:07
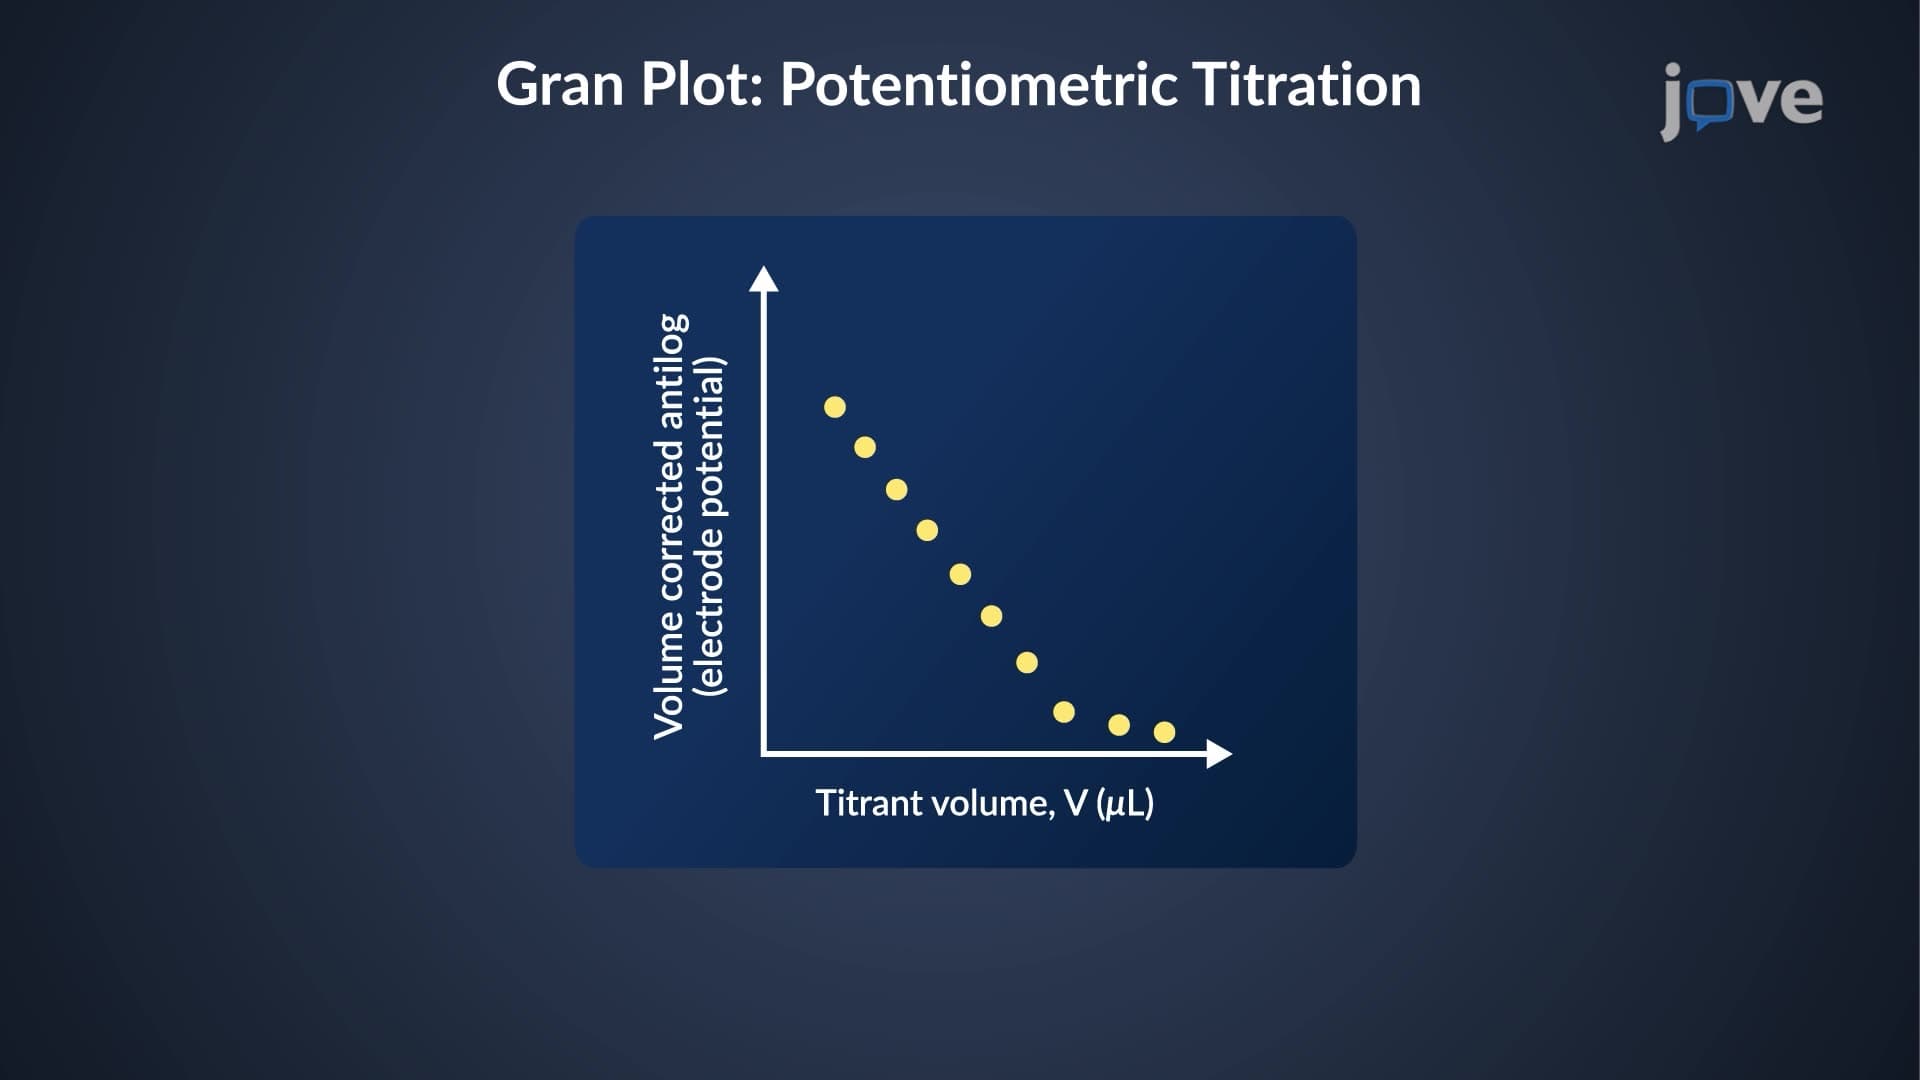
End Point Prediction: Gran Plot
For potentiometric titration, the Gran plot is created by plotting the...
 01:17
Design Example: Alignment of a Road Line Using GIS
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:34
Velocity and Position by Graphical Method
 01:27
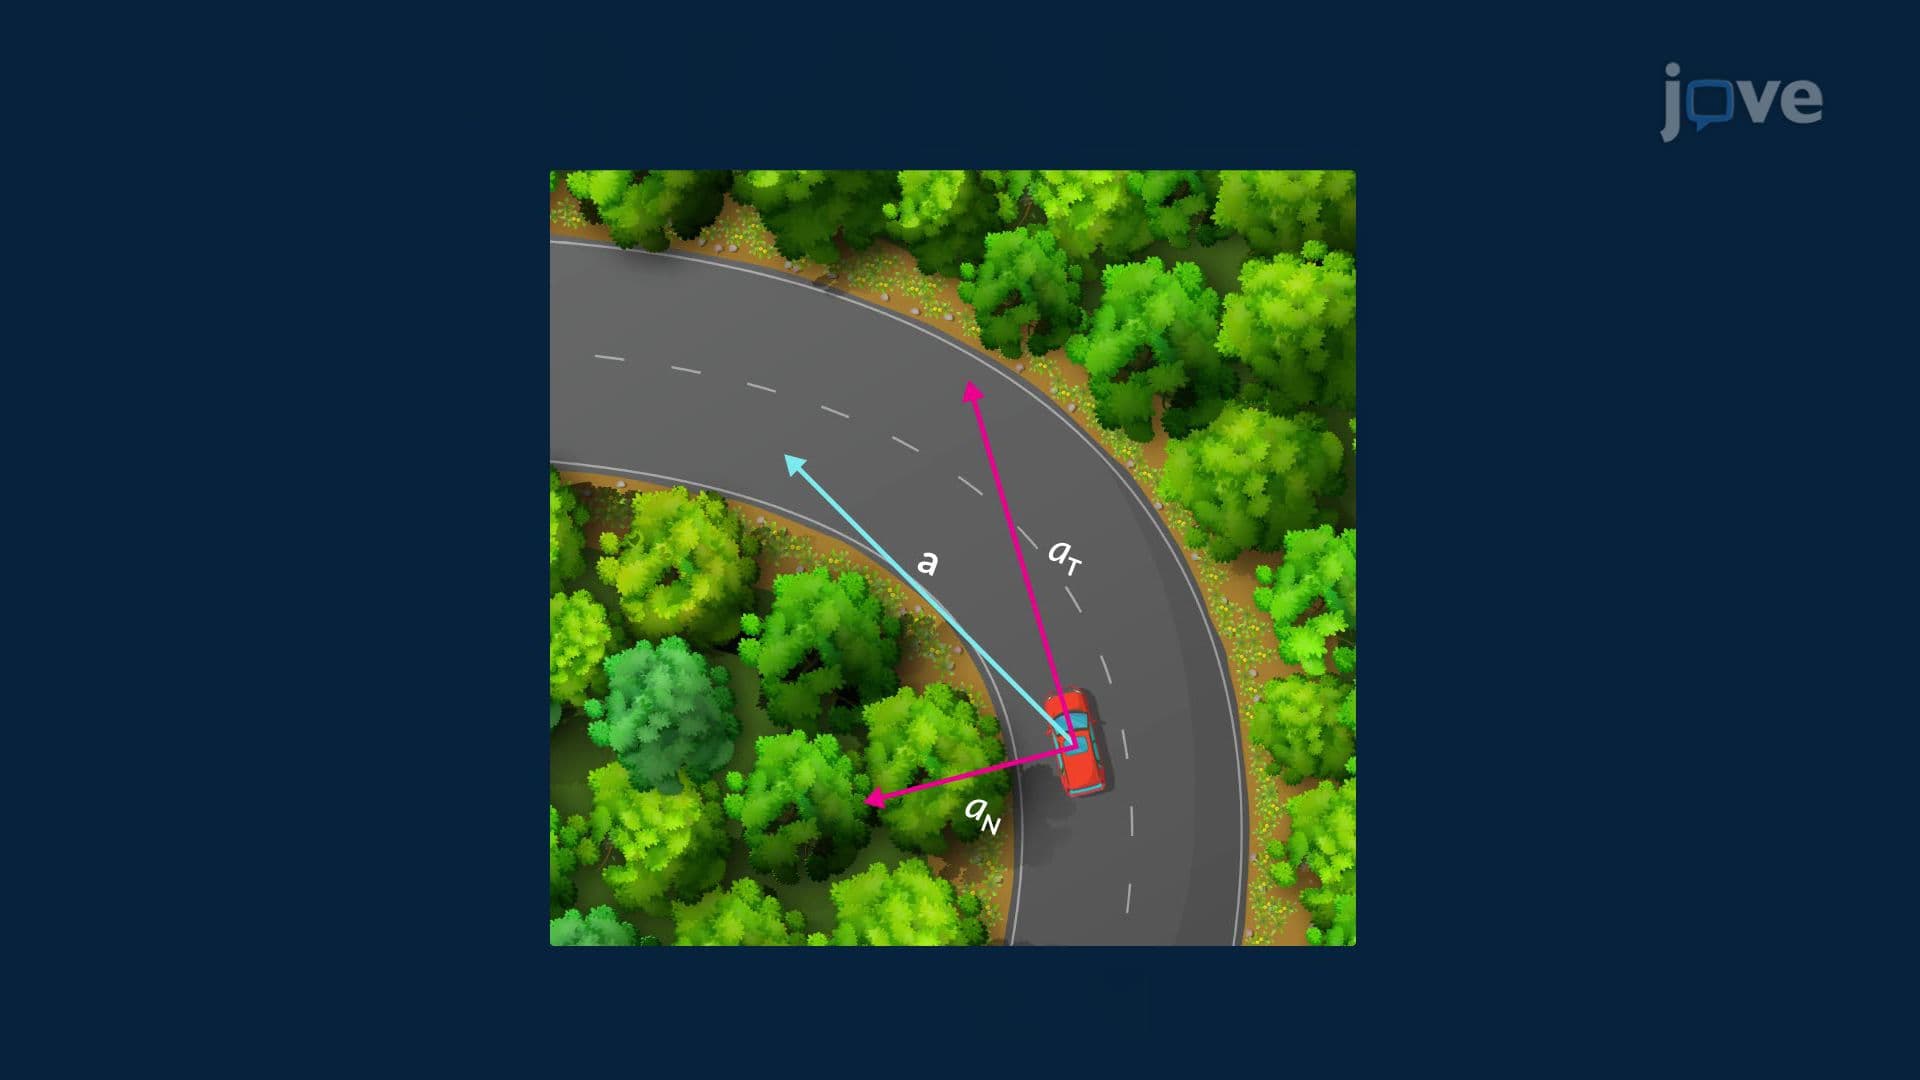
Tangential and Normal Components of Acceleration