Related Experiment Video
Updated: Aug 5, 2026


Rod-based Fabrication of Customizable Soft Robotic Pneumatic Gripper Devices for Delicate Tissue Manipulation
Published on: August 2, 2016
Fin-Ray soft gripper for object manipulation with multi-robot systems
Santiago Velasquez1, Alejandro Toro-Ossaba1, Daniel Sanin-Villa2
1Artificial Intelligence and Robotics Research Group (IAR), Universidad EIA, Envigado, 055428, Colombia.

Abstract:
Soft robotic grippers are attractive for cooperative object transport in multi-robot systems because they tolerate positioning errors and reduce the risk of damage to fragile items. However, many Fin-Ray effect grippers lack integrated force feedback, require empirical tuning of geometry, and are not documented as open hardware, which limits their adoption in research and teaching platforms. This work presents the design, fabrication, instrumentation, and validation of an open-source Fin-Ray soft gripper tailored for caging-based manipulation with mobile robots. The gripper combines 3D-printed TPU fingers optimized via finite element analysis, a thin-film piezo-resistive force sensor, and an STM32-based proportional controller that regulates gripping force in real time. The complete hardware stack, including mechanical models, firmware, and a Python graphical interface for monitoring and control, is released as open design files. The sensor was characterized in the range from approximately 0.1 N to 5 N. A third-order polynomial calibration yields an average accuracy of 70.8 % over this interval, with reduced accuracy at very low forces, and an average coefficient of variation of 1.10 %, which indicates highly repeatable measurements. Static closed-loop tests against a rigid object show convergence to a 0.981 N force setpoint with small steady-state error. Dynamic interaction tests confirm that the controller compensates for external perturbations by adjusting the gripper aperture. Energy measurements reveal an average current consumption near 250 mA during regulation, with peaks around 1 A when rejecting disturbances. These results indicate that the proposed gripper is suitable as a low-cost, reproducible end-effector for cooperative manipulation experiments in multi-robot systems.


Related Concept Videos
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:30
Three-Dimensional Force System
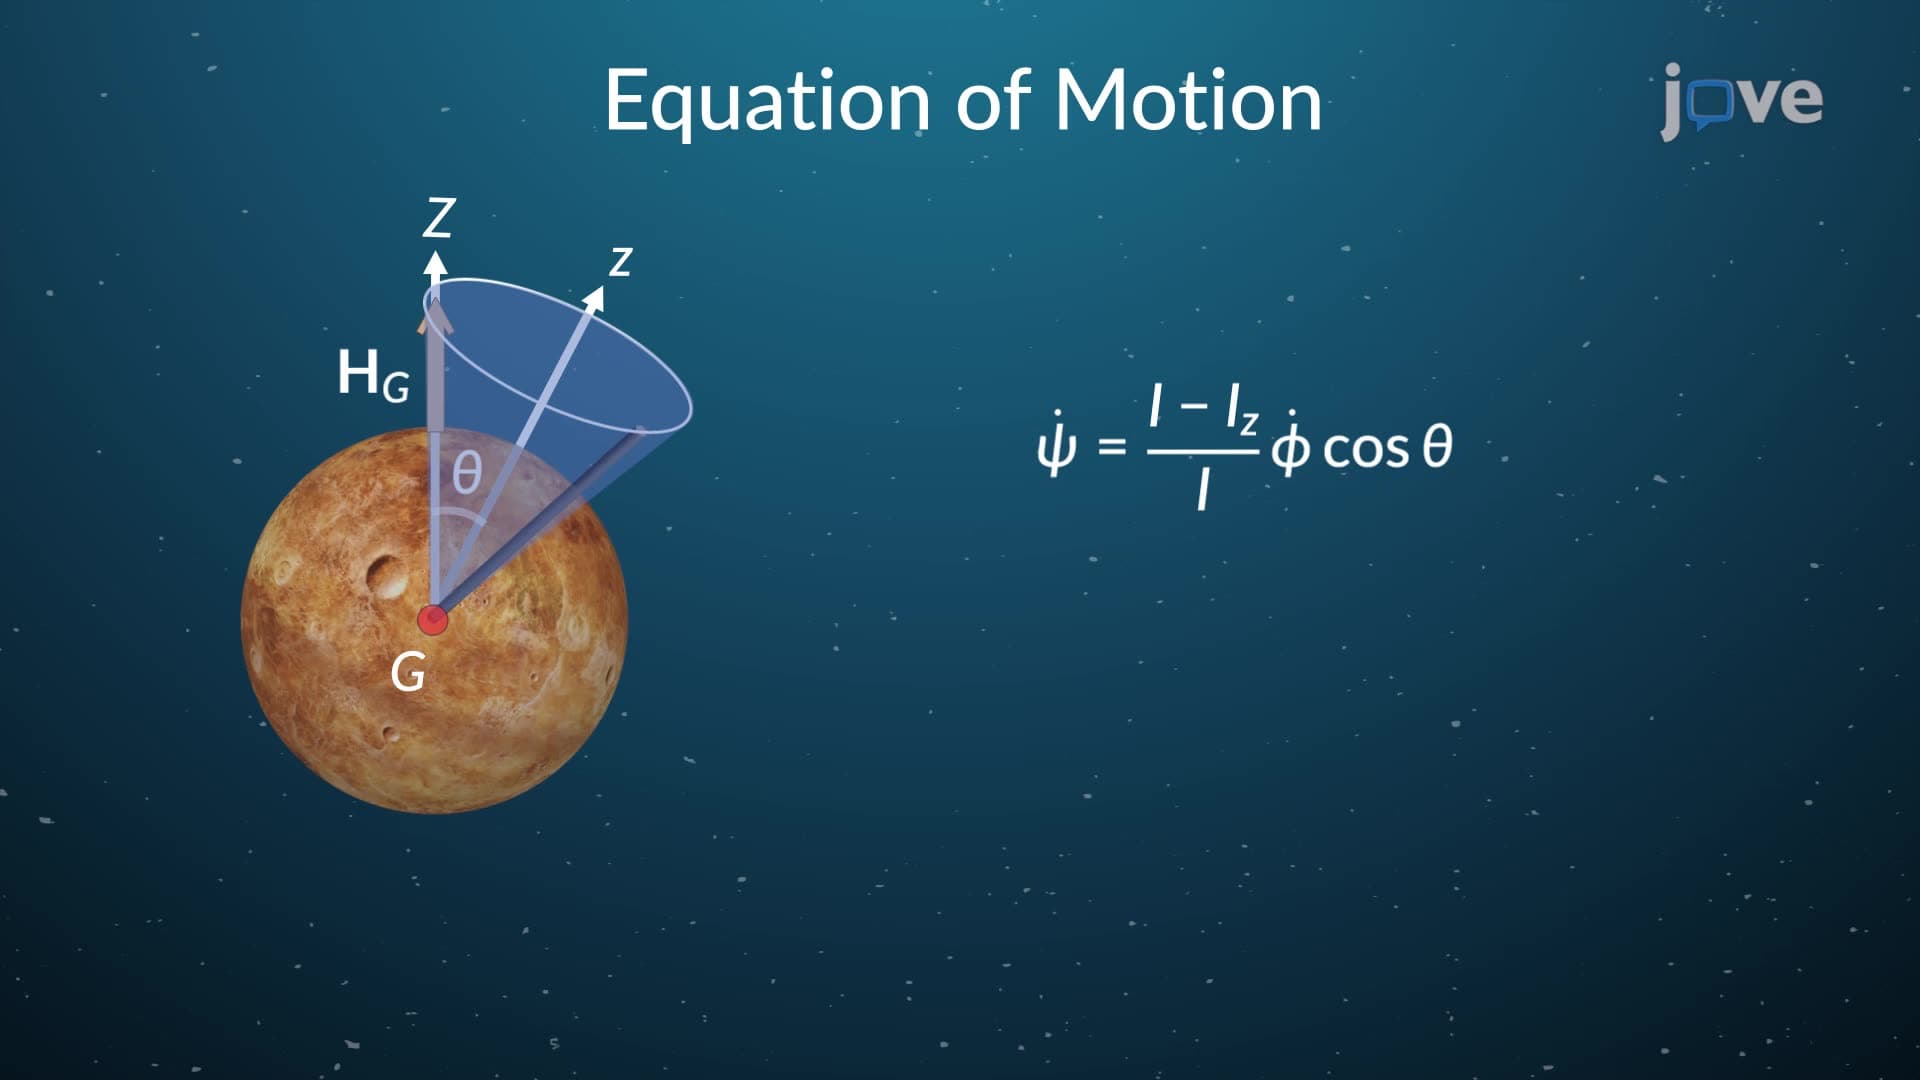 01:15
Torque Free Motion
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...