Related Experiment Videos
Model-Free Adaptive Formation-Containment Control for UAV-UGV Systems Under Fading Channels

Abstract:
This article proposes a model-free adaptive formation-containment control scheme for unmanned aerial vehicle (UAV)-unmanned ground vehicle (UGV) systems consisting of multiple leader UAVs and follower UGVs under fading channels. First, the nonlinear dynamics of the UAVs and UGVs are transformed into linearized data models. Then, the finite-time prescribed performance technique is introduced for the leader UAVs and follower UGVs, and a compensation-based model-free adaptive control (MFAC) algorithm is developed to mitigate the adverse effects of fading channels. Theoretical analysis shows that the leader tracking error and the follower compensated error satisfy the prescribed performance constraints and enter the corresponding terminal prescribed performance regions within the predefined finite times. Finally, simulation results are provided to verify the effectiveness of the proposed scheme.
Related Concept Videos
 01:18
Uniform Depth Channel Flow: Problem Solving
 01:27
Uniform Depth Channel Flow
 01:24
Rapidly Varying Flow
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be calculated...
 01:14
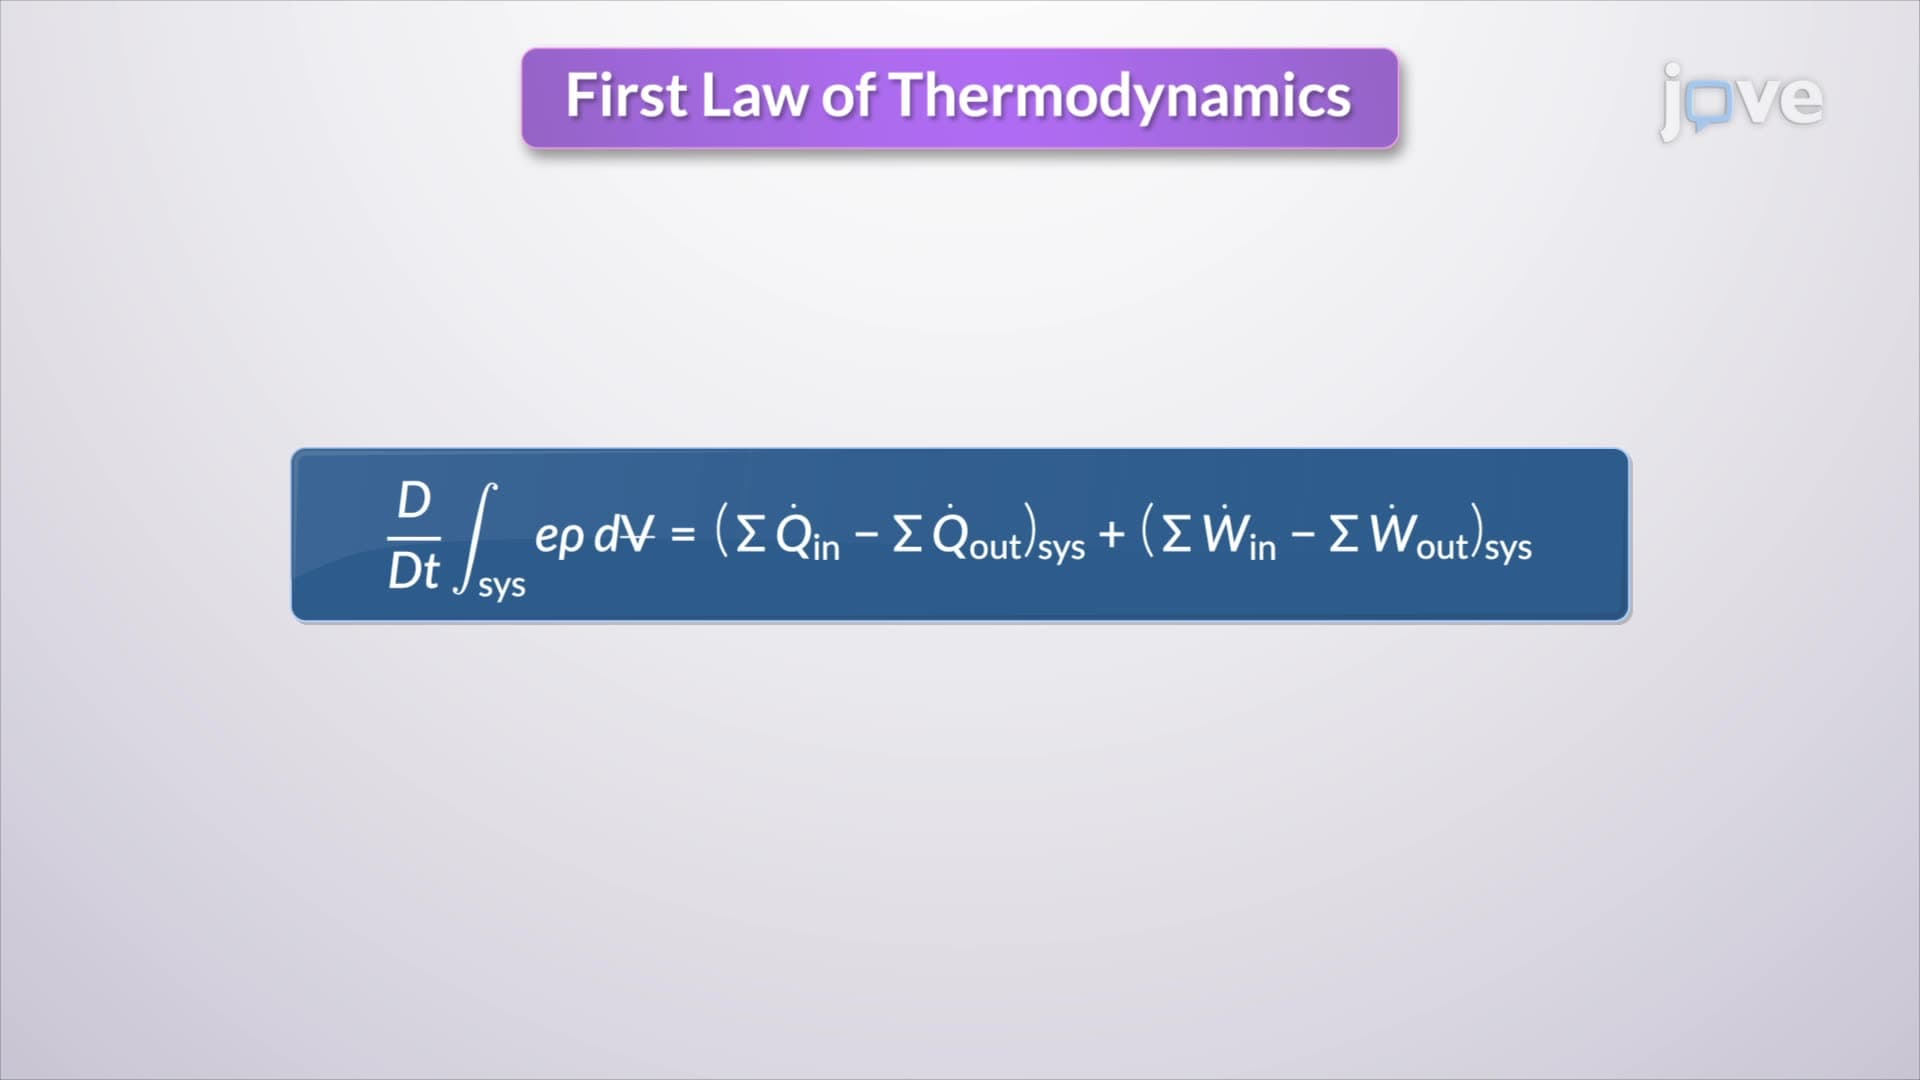
Conservation of Energy in Control Volume
For steady flow systems, the time derivative of the stored energy becomes zero since there is no energy accumulation within the control volume. This simplifies the energy equation to:
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...