Related Experiment Video
Updated: Aug 5, 2026
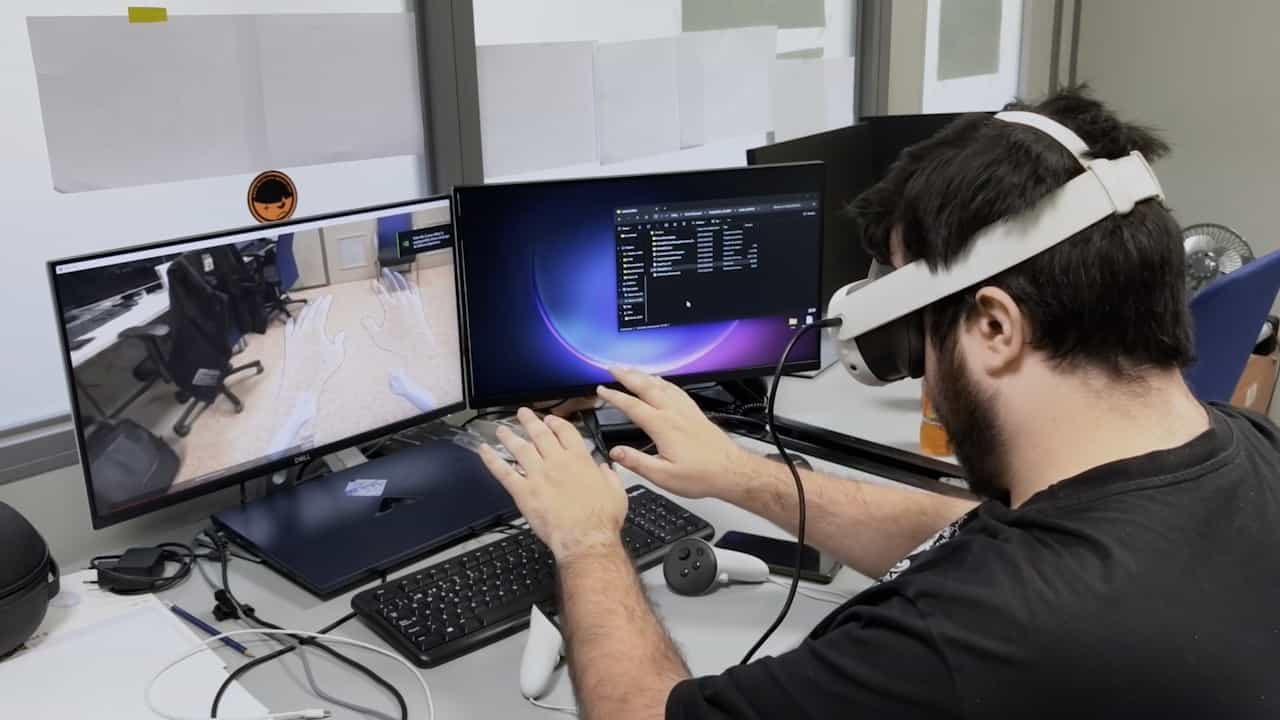

Photorealistic Learned Landscapes for Augmented Reality
Published on: June 27, 2025
Geometry-Semantics Co-Regularization for Gaussian Splatting in Indoor Reconstruction

Abstract:
Recent advances in 3D Gaussian Splatting (3DGS) have significantly advanced indoor scene reconstruction, a key capability for AR/VR, robotics, and autonomous systems. However, existing methods that rely on 2D monocular priors often produce artifacts such as holes and unnatural protrusions due to insufficient or weak constraints. To address this limitation, we propose a geometry-semantics co-regularization framework that jointly optimizes geometry and semantics within 3DGS. On the geometric side, we introduce a multi-level geometric optimization strategy with two key contributions. First, inspired by neural implicit surface representations, we design a dual implicit architecture that integrates Implicit Moving Least Squares (IMLS) and Signed Distance Functions (SDFs). This structure enables mutual reinforcement between the two representations via local geometric approximation and global normal constraints, improving fine-grained surface modeling. Second, we develop a view-dependent normal consistency constraint that combines 2D observations with SDF gradients to refine surface accuracy. On the semantic side, we develop a multi-view semantic consistency supervision to regularize the semantic distributions of Gaussian primitives, ensuring cross-view consistency for Gaussians corresponding to the same semantic category or instance. Extensive experiments on the Replica and MuSHRoom datasets demonstrate that our approach achieves state-of-the-art geometric reconstruction quality and rendering fidelity. Check out the project page https://sgo-gauss.github.io for the source code and more results.
Related Concept Videos
 01:20
Divergence Theorem in 3D Space
 01:11
Residuals and Least-Squares Property
If the observed data point lies above the line, the residual is positive, and the line underestimates the actual data value for y. If the observed data point lies below the line, the residual is negative, and the line overestimates the actual data value for y.
The process of fitting the best-fit...
 01:28
Cylinders in Three-Dimensional Space
 01:26
Gauss's Law: Spherical Symmetry
 01:24
Area Computation by the Alternative Coordinate Method
 01:27
Cross Product and Its Geometry