Related Experiment Video
Updated: Aug 5, 2026


Bioinspired Soft Robot with Incorporated Microelectrodes
Published on: February 28, 2020
Electro-Ribbon Actuator-Driven, Responsive Skating Robot Inspired by Water Striders
Jianhao Liu1, Yangyang Zhao1, Heng Fu1
1School of Mechanical Science and Engineering, Huazhong University of Science and Technology, Wuhan, P. R. China.

Abstract:
The biomimetic water strider robot is inspired by the biological water strider and is expected to be applied in fields such as environmental monitoring and reconnaissance. However, currently biomimetic water strider robots are mainly dominated by water pressure. This often leads to severe surface interference, high power consumption, and delayed response. Here, we introduce a lightweight (1.37 g) water surface skating biomimetic water strider robot driven by an electro-ribbon actuator, which uses surface tension as the dominant force. This robot eliminates the need for a transmission system and achieves direct leg drive, minimizing energy loss and additional mass. Compared with other robots of the same type, this robot exhibits excellent performance, including fast response (millisecond level), minimal disturbance to the water surface (the pitch and swing angles are both below 0.2°), and lower cost of transportation (1.17 J kg-1m-1). We further evaluated the motion stability of the robot. This work provides a foundation for the research of surface tension dominated biomimetic water strider robots and expands the application range of electro-ribbon actuators.

Related Concept Videos
 01:26
Kinetic Friction
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
 01:18
Design Example: Designing Water Slide
Bernoulli's principle determines the water's velocity along the slide.
 01:05
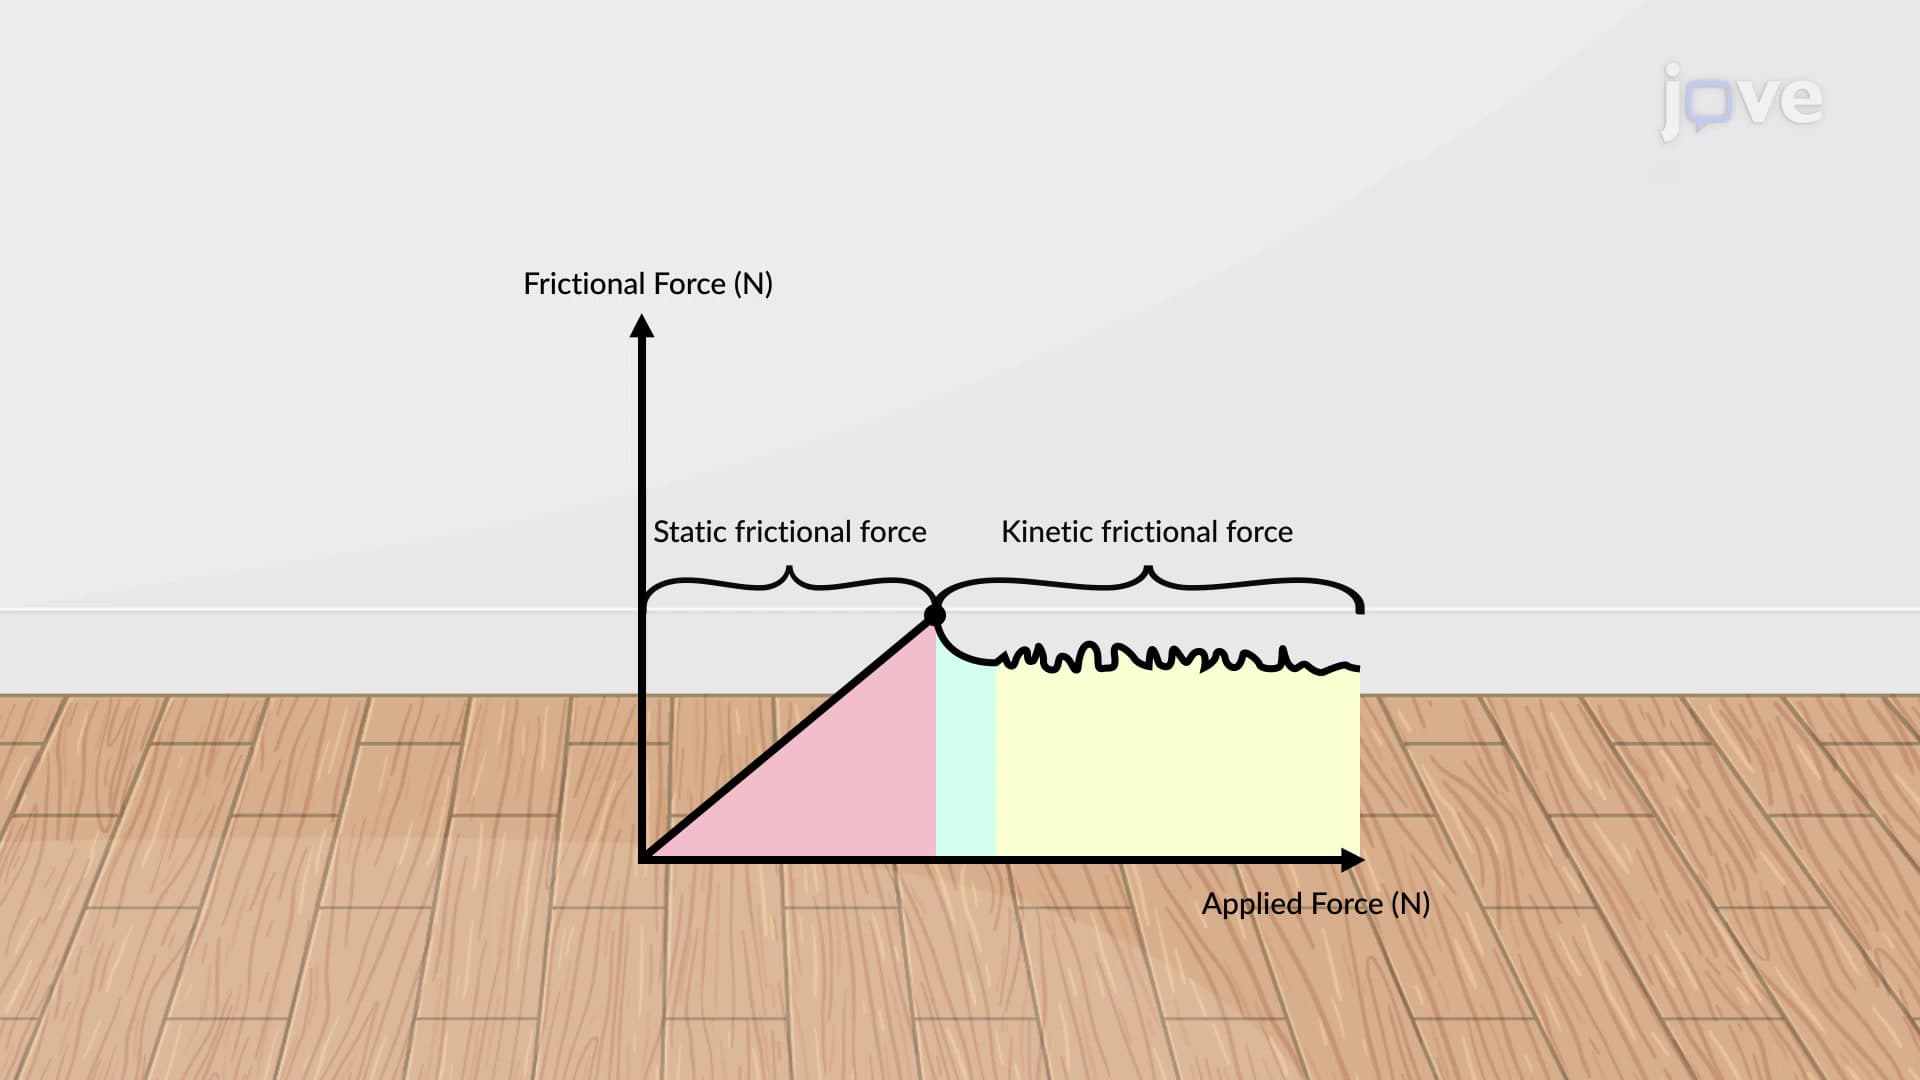
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:17
Rolling Resistance: Problem Solving