Related Experiment Video
Updated: Aug 5, 2026


Design and Fabrication of an Elastomeric Unit for Soft Modular Robots in Minimally Invasive Surgery
Published on: November 14, 2015
A magneto-elastic model for soft magnetic concentric tube robots
Peter Lloyd1, Joshua Davy1, Yael L May1
1Storm Lab, School of Electronic and Electrical Engineering, University of Leeds, Leeds, UK.

Abstract:
This paper presents a numerical solution to a reduced-order analytical energy formulation of a soft, magnetically actuated concentric tube continuum robot. Unlike conventional concentric tube robots, which rely on pre-curved elastic energy storage and suffer from material stiffness constraints and snap through instability, our design uses softly magnetic rings adhered to braided sleeves to generate deformation directly from a strong, stationary background field. While high-field MRI systems provide a convenient actuation environment, the proposed design principle is broadly applicable to any application featuring a sufficiently strong background magnetic field (B 1T). We derive a complete magneto-elastic formulation that couples easy-plane magnetic torque with sleeve curvature to determine stable catheter configurations. The model captures mechanical hysteresis, bistability, and the nonlinear relationship between base rotation and tip pose. Experimental validation in the background field of a 7T pre-clinical MRI scanner demonstrates strong agreement with simulated deformation, with an overall RMS error of . This framework provides a foundation for closed-loop control, systematic design optimization, and self-sensing capabilities in magnetically actuated soft continuum robots, enabling new classes of highly compliant robotic systems for constrained and sensitive environments.
Supplementary Information:
The online version contains supplementary material available at 10.1007/s11071-026-12856-3.

Related Concept Videos
 01:13
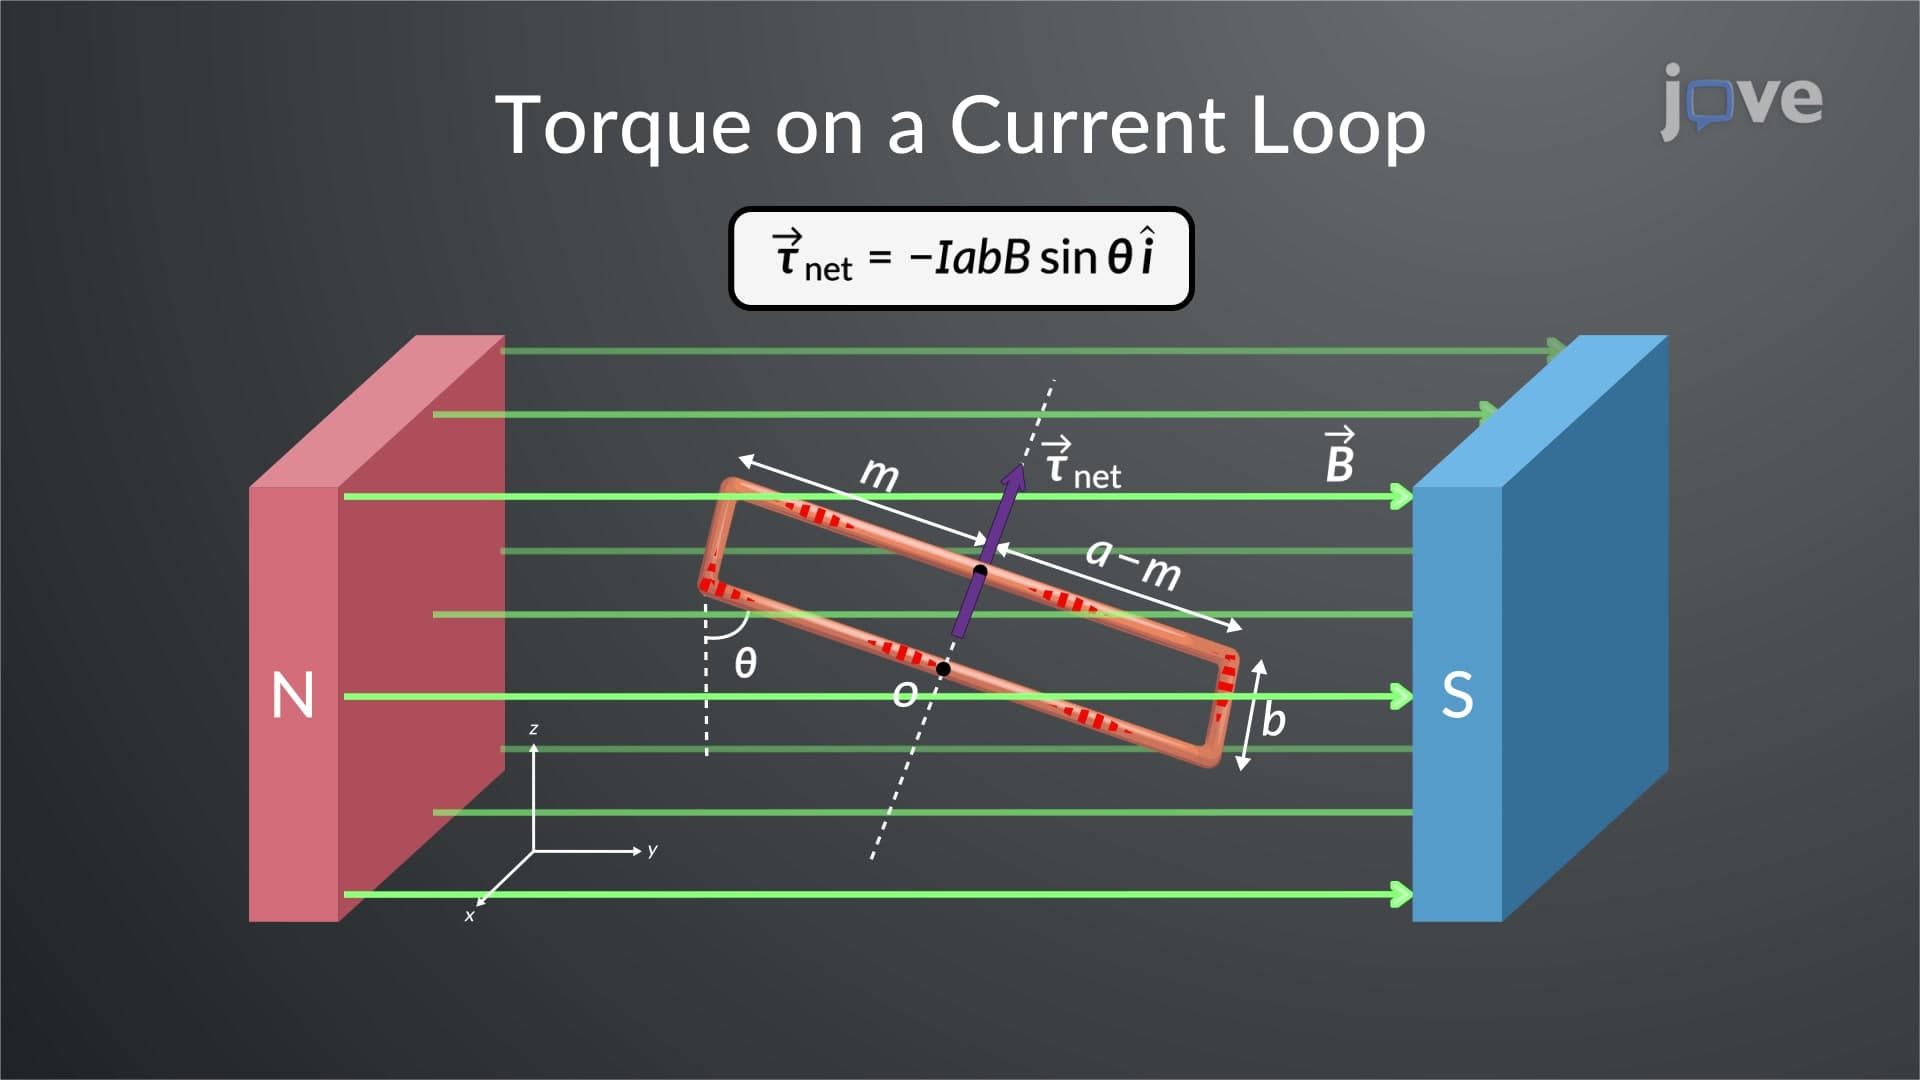
Torque On A Current Loop In A Magnetic Field
Consider a rectangular current-carrying loop containing N turns of wire, placed in a uniform magnetic field. The net force on a current-carrying loop...
 01:24
Potential Due to a Magnetized Object
The vector...
 01:24
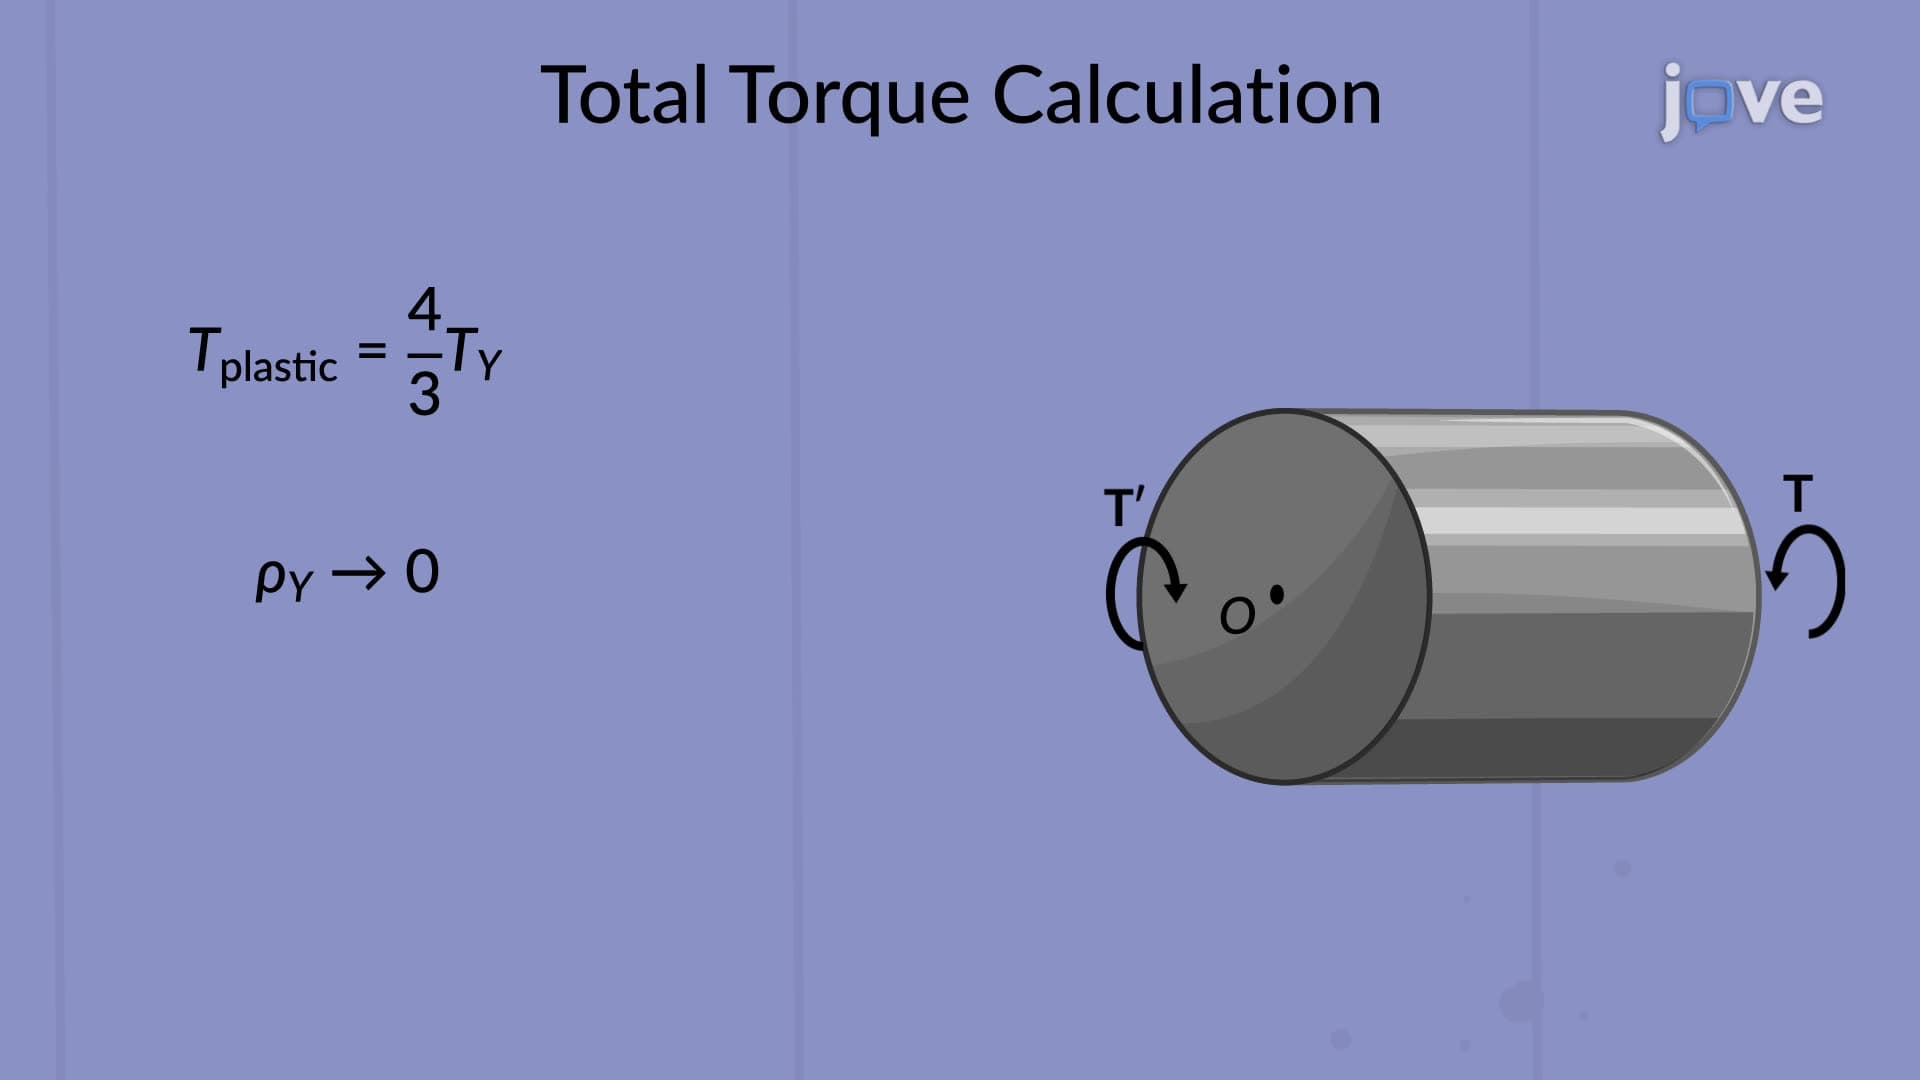
Circular Shafts - Elastoplastic Materials
As torque on the...
 01:18
Magnetic Force
The magnetic force acting on a moving charge...
 01:28
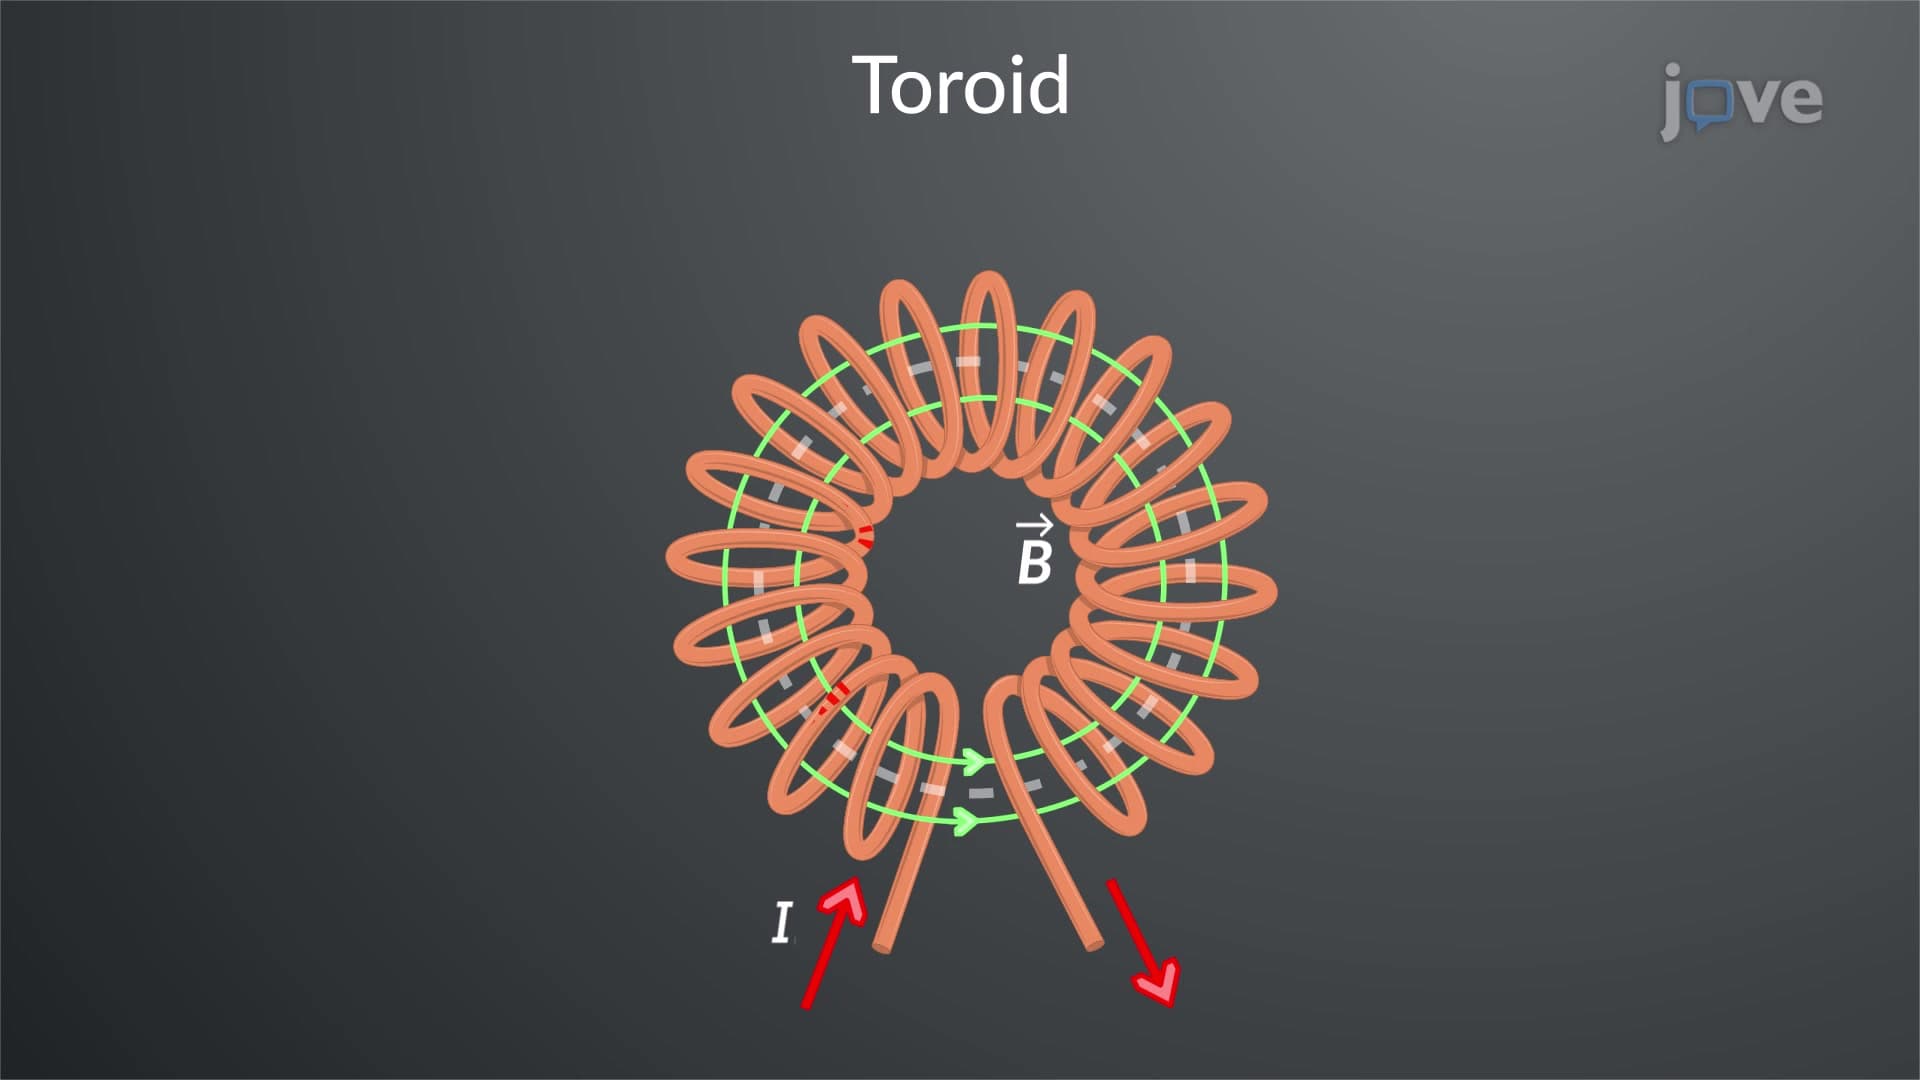
Toroids
When connected to a supply, the magnetic field generated in the toroid has field lines circular and concentric to its axis. Conventionally, the direction of this magnetic field is expressed using the right-hand rule. If the fingers of the right hand curl in the current direction, the thumb points in the...
 01:28
Magnetostatic Boundary Conditions