Related Experiment Video
Updated: Aug 11, 2026


An Inertial Measurement Unit Based Method to Estimate Hip and Knee Joint Kinematics in Team Sport Athletes on the Field
Published on: May 26, 2020
Error distribution and post hoc disturbance features in IMU-based hip joint angle estimation during complex movements
Jinan Dong1, Ziming Chen1, Dejin Yang2
1School of Mechanical Engineering, Yanshan University, Qinhuangdao, Hebei 066004, People's Republic of China.

Abstract:
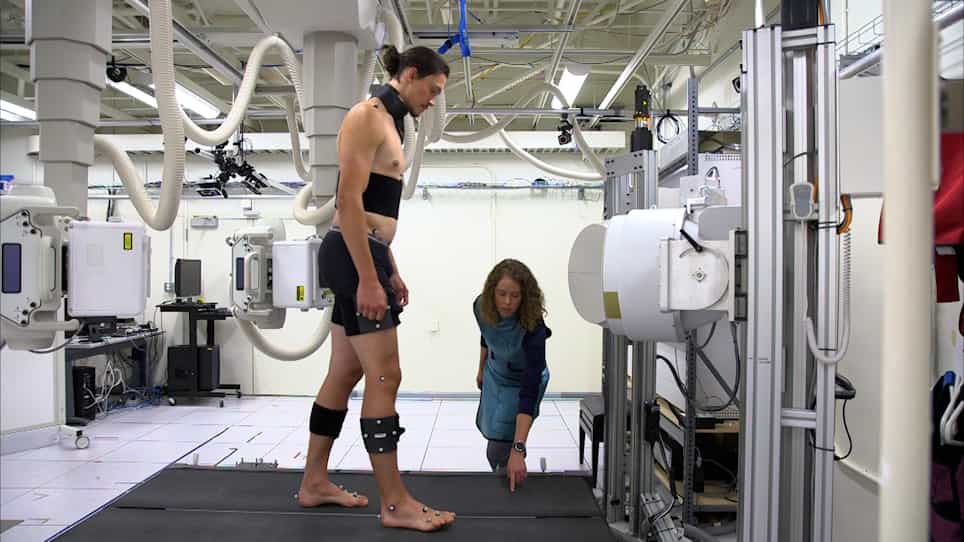
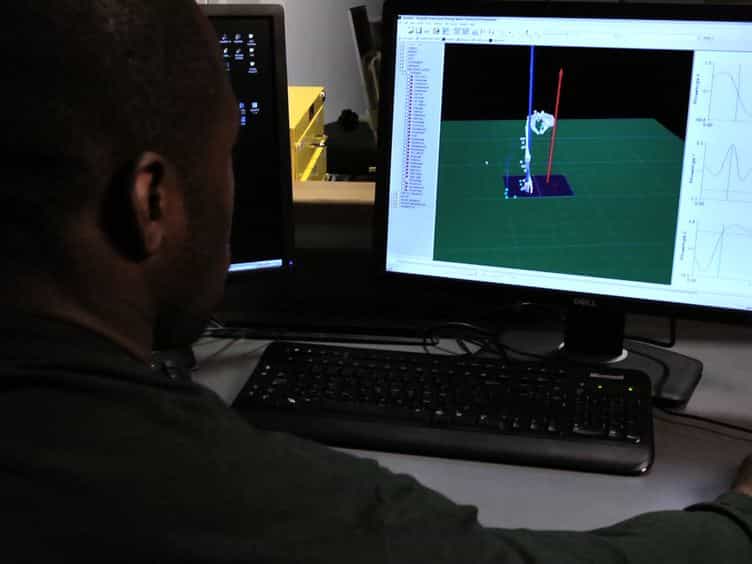
Existing evaluations of IMU-based joint angle estimation mainly rely on global accuracy metrics, which may obscure local error exposure during complex functional movements. This study analyzed data from 16 healthy male participants in the Hip-ROM-Y dataset. Using leave-one-subject-out outputs from a unified left hip joint predictor, we characterized left hip angle estimation errors by movement category, normalized movement phase, and high-error segment. The relationship between error distribution and post hoc disturbance features was further examined. The results showed that, under the current model and data conditions, complex movements (CMs) generally produced higher errors than basic movements. However, the increase in error was not uniformly distributed, but was mainly concentrated in local mid-phase periods of several CMs and was accompanied by greater deviations in the relative relationship between the pelvis and thigh segment. These findings suggest that evaluations of hip angle estimation under similar wearable configurations should pay attention to local error distributions during CMs and to the stability of the pelvis-thigh segment relationship.
Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...