Related Experiment Video
Updated: Aug 6, 2026
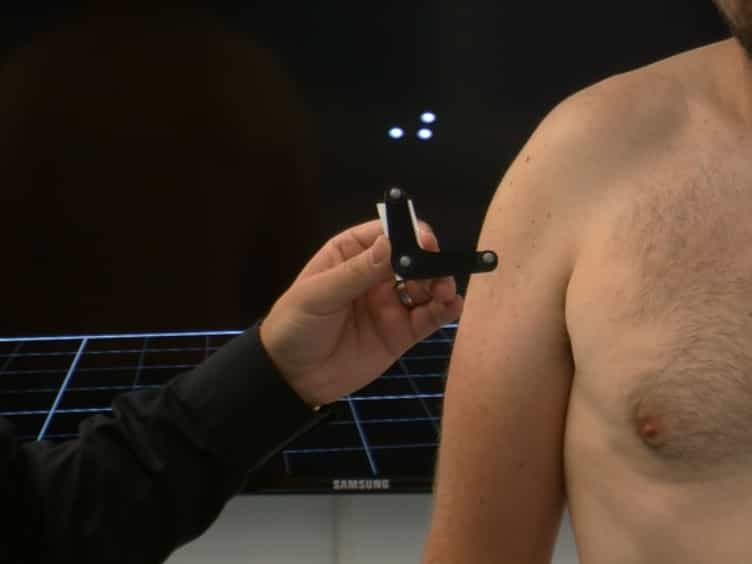

Measurement of Dynamic Scapular Kinematics Using an Acromion Marker Cluster to Minimize Skin Movement Artifact
Published on: February 10, 2015
Inter-system differences in modelling approaches for shoulder joint kinematics between markerless and marker-based
Tomoya Uchida1, Tomoyuki Matsuo2, Takuya Nakamura2,3
1Toyota Athlete Support Centre, Toyota Memorial Hospital, Toyota, Japan.

Abstract:
Comparative data on markerless motion capture systems for upper-extremity kinematics during high-speed movements remain limited. We aimed to examine inter-system modelling differences in shoulder joint kinematics between a markerless motion capture system (Theia3D) and a marker-based system during baseball pitching, focusing on a wide range of shoulder joint motion throughout baseball pitching. Six collegiate pitchers completed 117 trials recorded simultaneously by both systems. Shoulder joint angles and joint centre positions were compared using nested Bland-Altman analysis, intraclass correlation coefficients (ICC (3,1)), and statistical parametric mapping (SPM). At maximum external rotation (MER), inter-system differences were small for external rotation (bias: -0.3°; ICC = 0.77), whereas the horizontal angle demonstrated a pronounced fixed bias (bias: -19.1°). At ball release (BR), inter-system differences increased across all joint angles, with the largest discrepancy for external rotation (bias: -8.5°; ICC = 0.33). Proportional bias was evident for most variables at BR. Between-participant variance exceeded within-participant variance at MER, indicating that participant-specific offsets were primary contributors to the limits of agreement. SPM identified significant inter-system differences during the acceleration phase. These findings highlight the importance of understanding the characteristics of each modelling approach for appropriate interpretation and application of markerless motion capture in overhead athletes.
Related Concept Videos
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
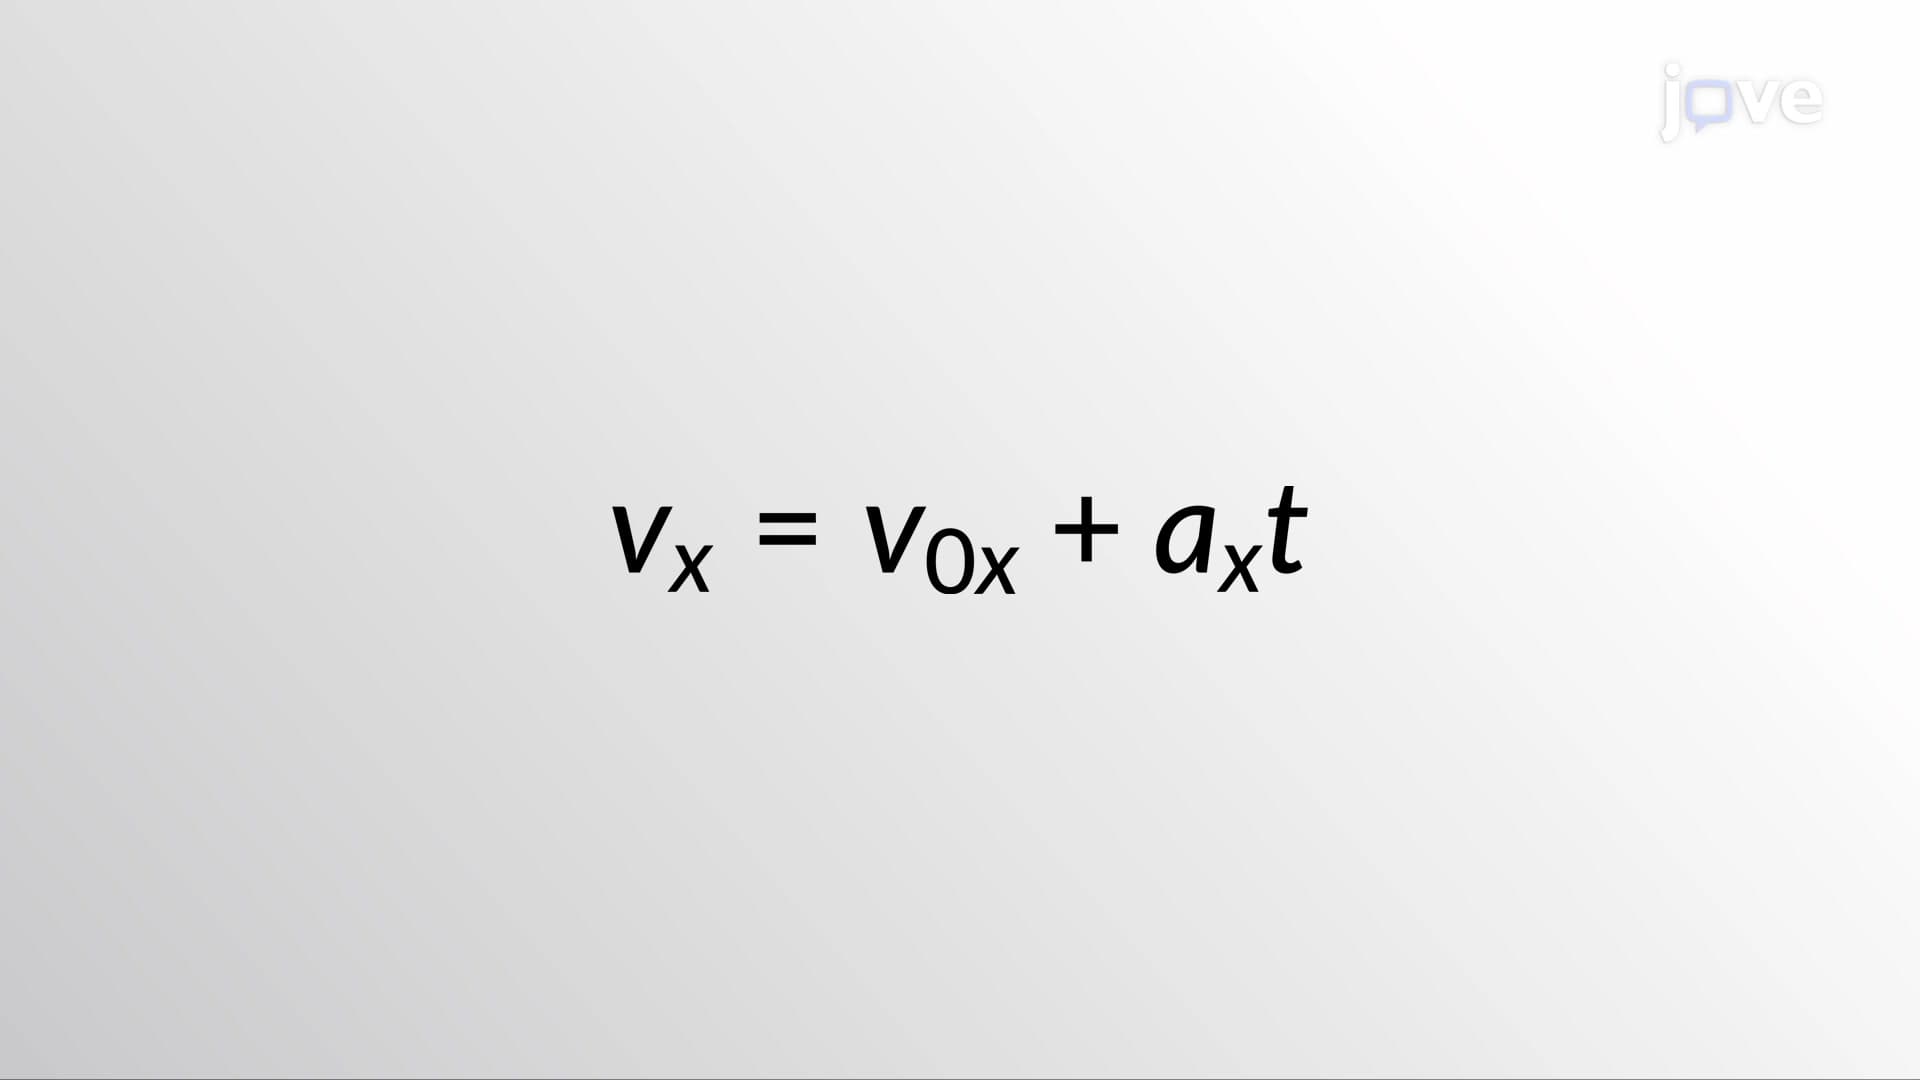 01:26
Kinematic Equations - I
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...