Related Experiment Video
Updated: Aug 7, 2026

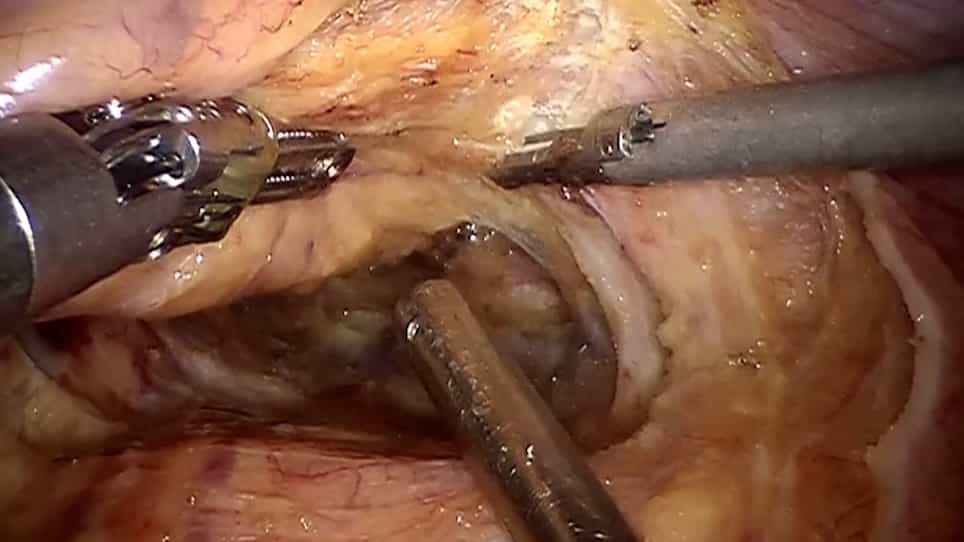
Robotic Enucleation of an Intra-Pancreatic Insulinoma in the Pancreatic Head
Published on: January 3, 2020
Surgeon-authorized natural-language and instrument-tracking shared control for robotic laparoscope holding: the
Li Qiu1,2, Zhikang Ma1,2, Yongshuai Hao1,2
1Institute of Medical Robotics and Intelligent Systems, Tianjin University, Tianjin, 300350, China.

Abstract:
Stable laparoscopic vision requires a camera that remains steady during fine manipulation yet can be repositioned promptly as the operative target changes. Manual holding can introduce tremor, communication delay and physical interference, whereas keyword spotting (KWS) confines the surgeon to predefined words and repeated low-level commands. We developed EndoVISTA, a surgeon-authorized shared-control framework that combines natural-language commands with instrument-guided coarse camera repositioning on a remote-centre-of-motion laparoscope holder. Chinese expressions are grounded to bounded motion primitives, with speech retaining priority for fine adjustment, stop and override. In noise-controlled trials with ten Chinese-speaking participants, EndoVISTA achieved an 88.0% command-execution success rate at 85 A-weighted decibels (dBA), compared with 76.0% for participant-specific KWS (mean paired difference, 12.0% points; 95% confidence interval [CI], 4.0 to 20.0), supporting robustness under the tested acoustic conditions. In a matched ring-transfer task, shared control shortened completion time by a mean of 40.0 s (95% CI, 25.7 to 54.3), reduced repeated or corrective commands by 17.6 (95% CI, 13.8 to 21.4), and lowered Raw National Aeronautics and Space Administration Task Load Index scores by 13.0 points relative to KWS (95% CI, 7.4 to 18.6). In a single porcine workflow observation, 15 repeated or corrective commands were recorded with EndoVISTA and 32 with KWS. Because the systems were used on different anatomical sides in one animal, this observation supports real-workflow feasibility rather than comparative efficacy. Together, the results indicate that task-dependent sharing of camera control can improve interaction efficiency and has the potential to reduce surgeon camera-control burden, warranting validation in larger clinical studies.