Related Experiment Video
Updated: Aug 8, 2026


Real-Time Proxy-Control of Re-Parameterized Peripheral Signals using a Close-Loop Interface
Published on: May 8, 2021
Temporal compensation physics-informed neural network modeling repetitive small-range rotation inverse dynamics
Fangyu Li1, Man Li1, Honggui Han1
1School of Information Science and Technology, Beijing University of Technology, Beijing, 100124, China; Engineering Research Center of Digital Community Ministry of Education, Beijing University of Technology, Beijing, 100124, China.

Abstract:
High-fidelity motion mapping is fundamental for high-precision robotic operations. However, existing models exhibit dynamic hysteresis effects during repetitive small-range rotations, resulting in diminished modeling accuracy. Therefore, we propose a temporal compensation physics-informed neural network (TC-PINN) to mitigate the dynamic hysteresis effects. First, we construct a rotational state trajectory encoded with cumulative joint rotation features to explicitly characterize the temporal phase deviations of motion hysteresis. Second, we design a Linformer-based nonlinear error fitting structure to compensate for unstructured dynamic errors caused by dynamic hysteresis effects. Finally, we establish TC-PINN deployed for end-to-end inference, which is optimized through a staged training strategy to mitigate mapping misalignment. Experimental results on a seven degrees of freedom robotic arm show that TC-PINN improves hysteresis-aware torque mapping accuracy under repetitive small-range rotations, reducing the total mean absolute error to 9.65×10⁻⁴ Nm.
Related Concept Videos
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:37
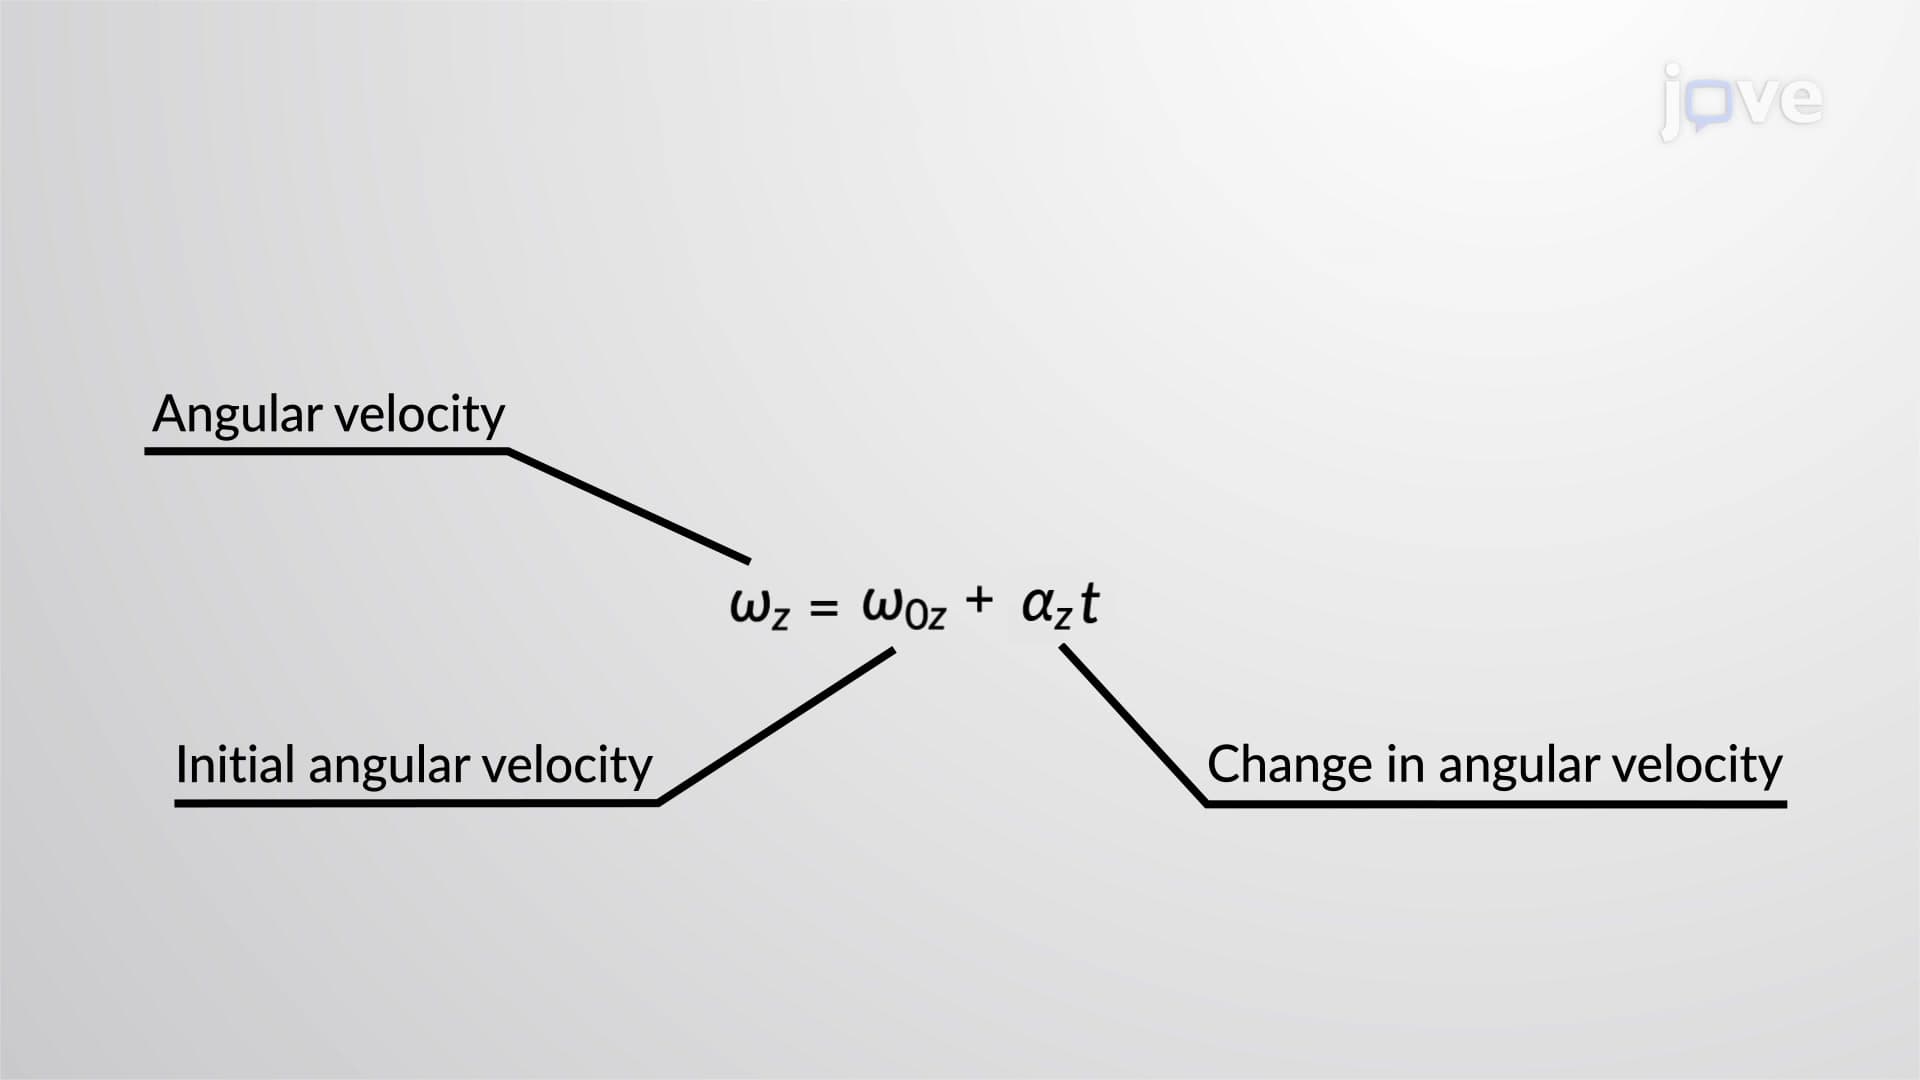
Rotation with Constant Angular Acceleration - I
Using our intuition, we can begin to see how rotational quantities such as angular displacement, angular velocity, angular acceleration, and time are related to one another. For example, if a flywheel...
 01:16
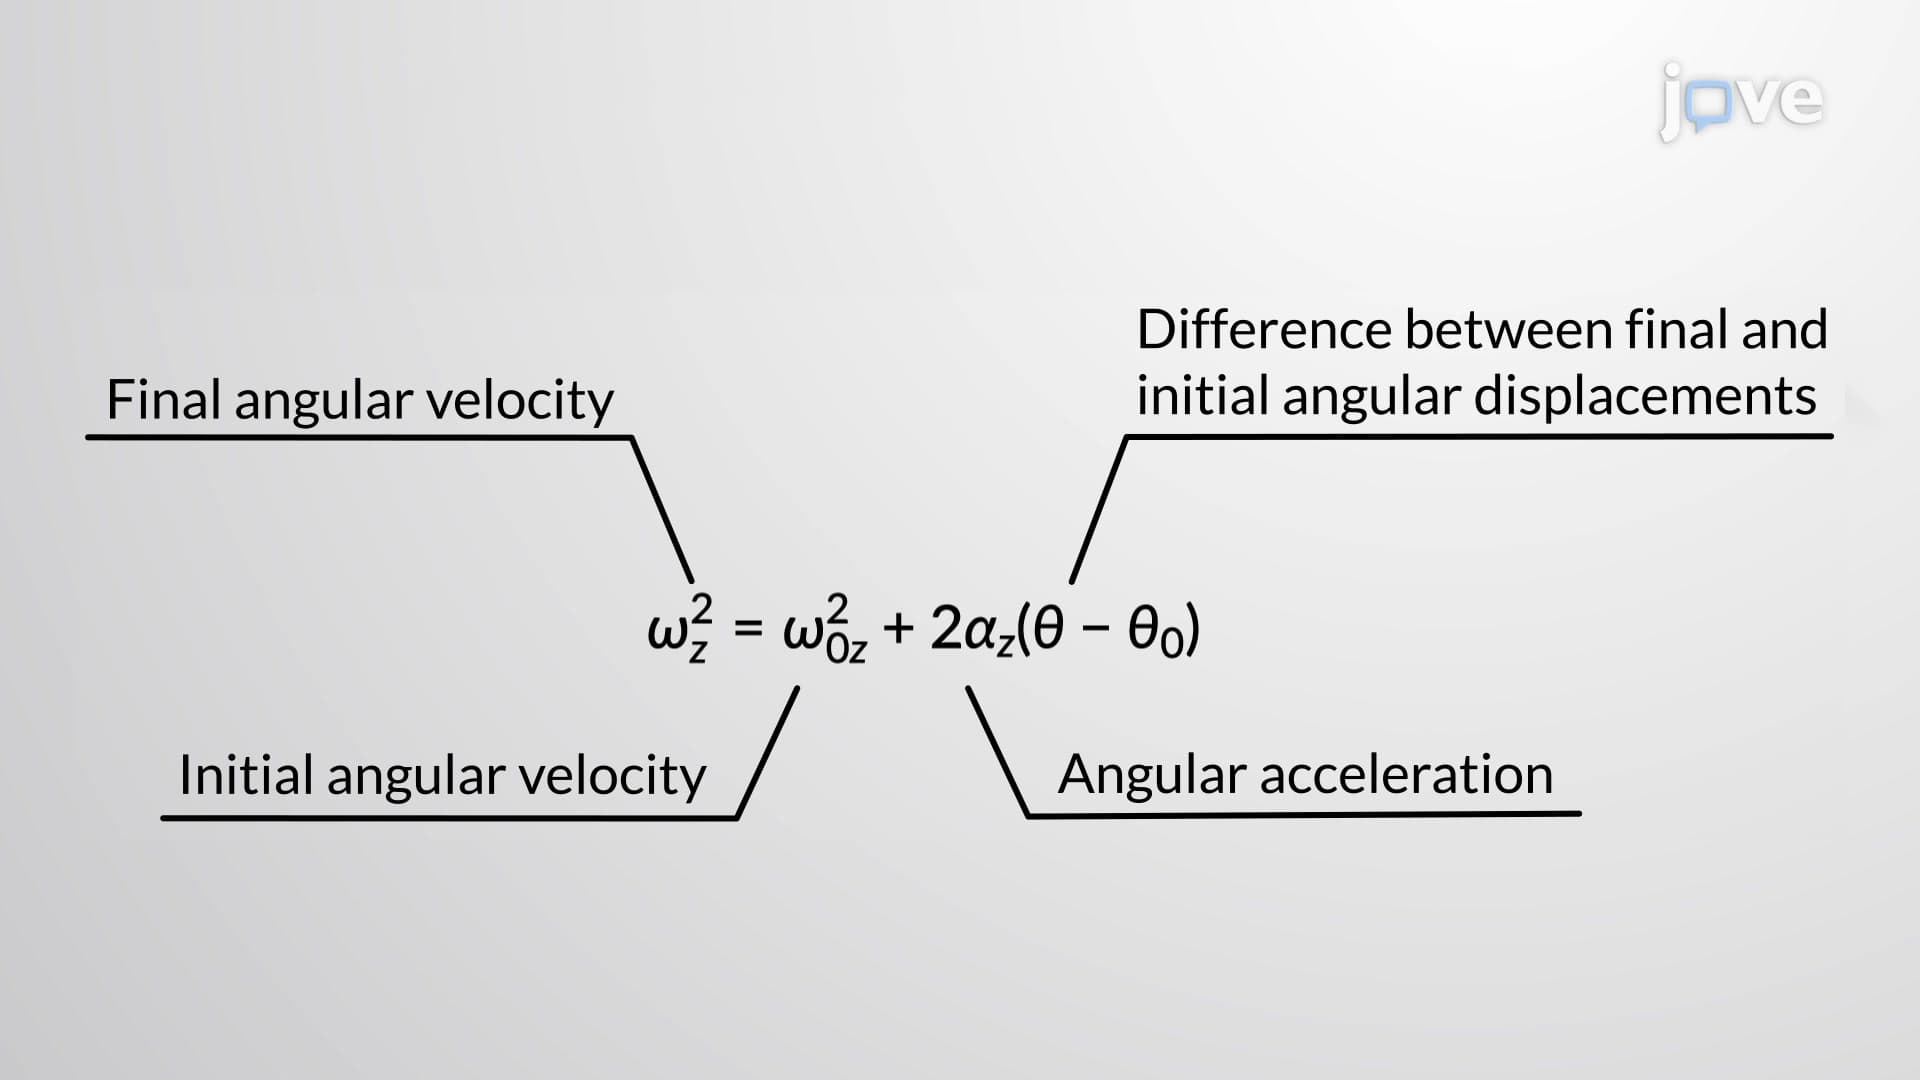
Rotation with Constant Angular Acceleration - II
The first...