Related Experiment Video
Updated: Aug 12, 2026

Method to Measure Tone of Axial and Proximal Muscle
Published on: December 14, 2011
Rapid Control Prototyping Simulation of Particle Swarm Optimization-Tuned Backstepping Tracking Control for A Rotary
Guanghui Chang1, Haomiao Yang2, Jiasen Lin2
1College of Power Engineering, Naval University of Engineering; 0908041020@nue.edu.cn.

Abstract:
The primary objective of this protocol is to provide a reproducible fixed-step simulation framework for evaluating Particle Swarm Optimization (PSO)-based gain tuning in nonlinear control systems. The implementation begins with the formulation of a Furuta-type pendulum model, followed by the integration of a backstepping controller within a 2 ms fixed-step execution environment. The methodology involves a systematic four-stage process: characterizing non-ideal implementation constraints, defining a multi-objective Particle Swarm Optimization search space, executing automated offline tuning, and evaluating the resulting parameters through a standardized suite of trajectory-tracking and disturbance-rejection scenarios. This setup, utilizing high-performance industrial workstations and standardized signal interfaces, supports consistent repeated-trial comparisons within the same control architecture. The design compares a baseline manually tuned backstepping controller with a PSO-optimized variant that shares the exact same control structure, thereby isolating the impact of gain selection. Controller performance is assessed across three distinct operational scenarios: step-trajectory following, mixed-frequency sinusoidal tracking, and disturbance rejection. Statistical analysis of 10 repeated trials showed that PSO-based optimization reduced the step-tracking RMSE from 0.065 to 0.050 rad and attenuated peak pendulum excursions by 33.1%. These improvements were achieved alongside a 22.1% reduction in RMS control effort, indicating that the optimized parameters facilitated more efficient energy distribution within the Lyapunov-based framework. Ultimately, this methodology provides a structured simulation framework to evaluate nonlinear control strategies before any subsequent physical hardware implementation.

Related Concept Videos
 01:21
Simple Harmonic Motion
 01:42
Simple Harmonic Motion and Uniform Circular Motion
There is an easy way to produce simple harmonic motion by using uniform circular motion. For instance, consider a ball attached to a uniformly rotating...
 01:10
Simple Pendulum
The period of a simple pendulum depends on two factors: its length and the acceleration due to gravity. The period is completely independent of any other factors, such as mass or maximum displacement. For small displacements, a pendulum is...
 01:09
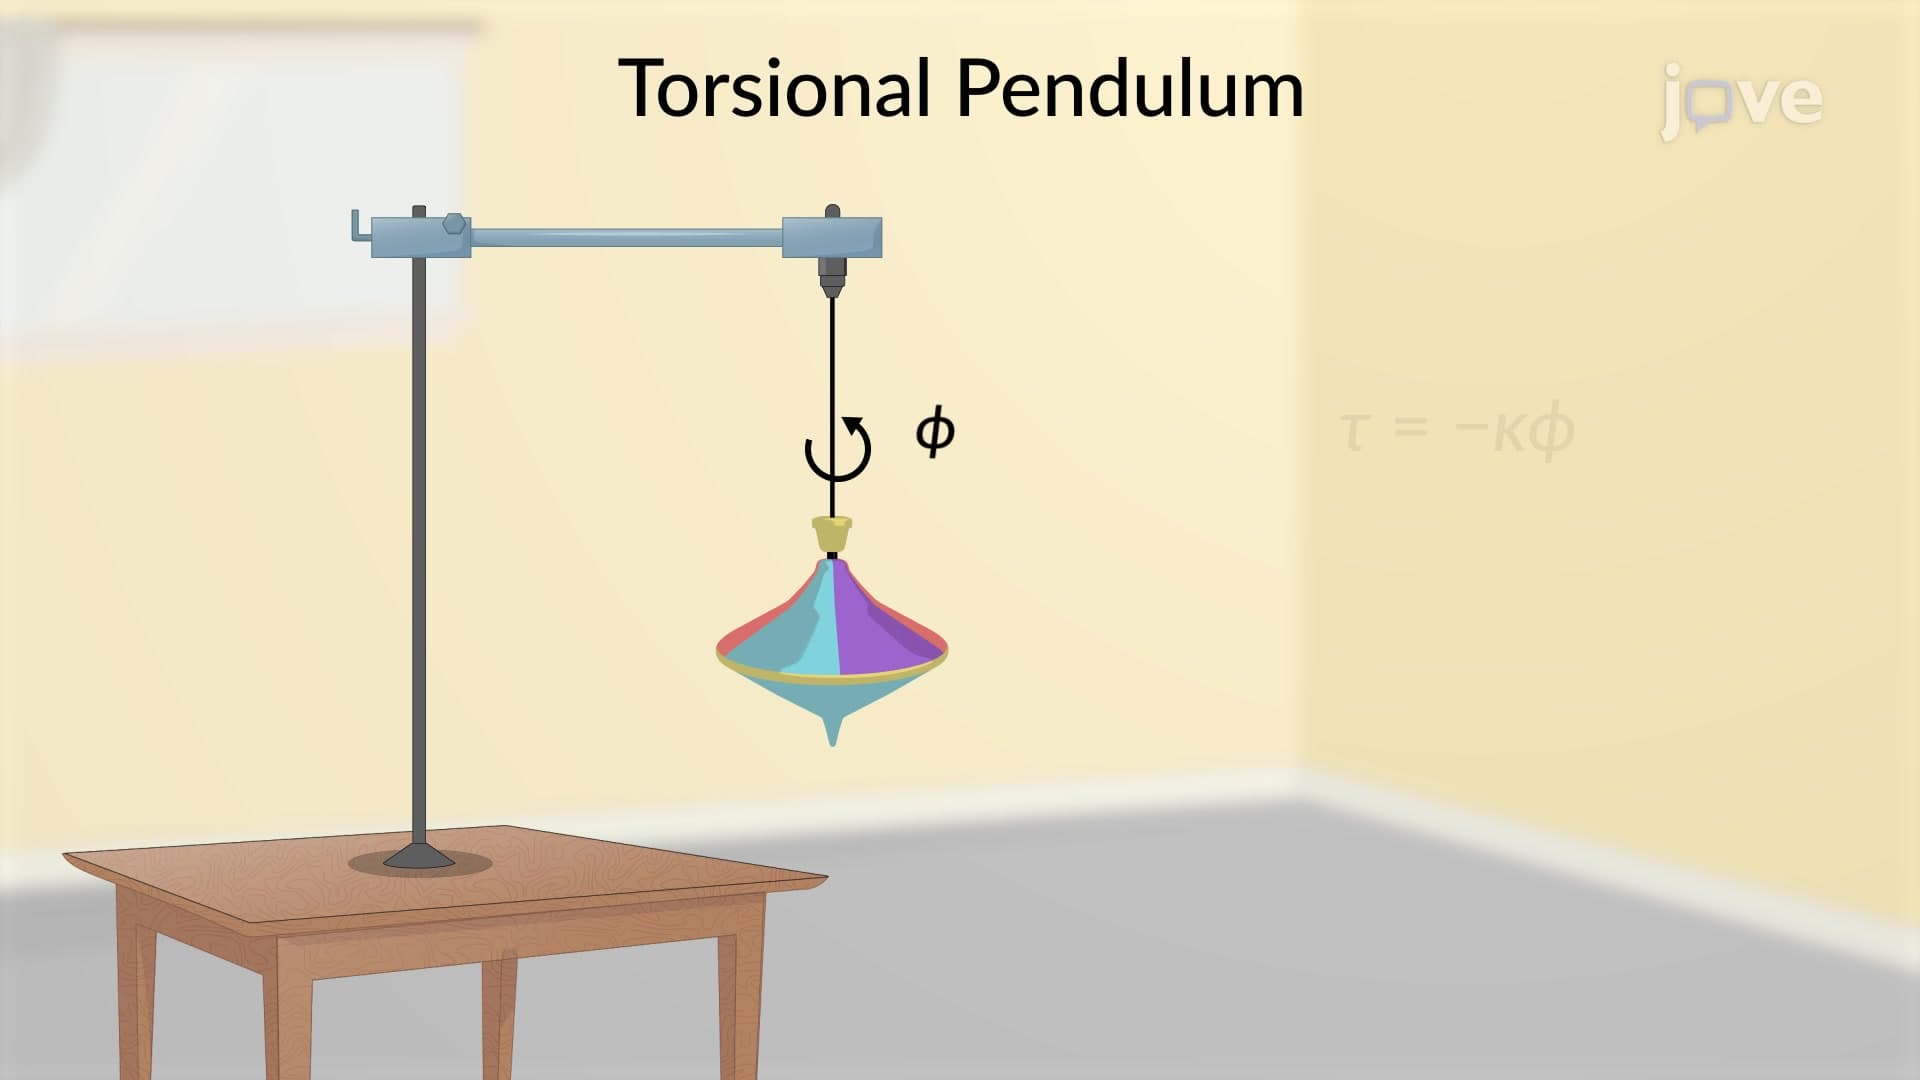
Torsional Pendulum
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played by the...
 01:06
Physical Pendulum
When dealing with complicated systems, the mass moment of inertia is an important parameter, as it describes the mass...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...