Related Experiment Video
Updated: Aug 14, 2026
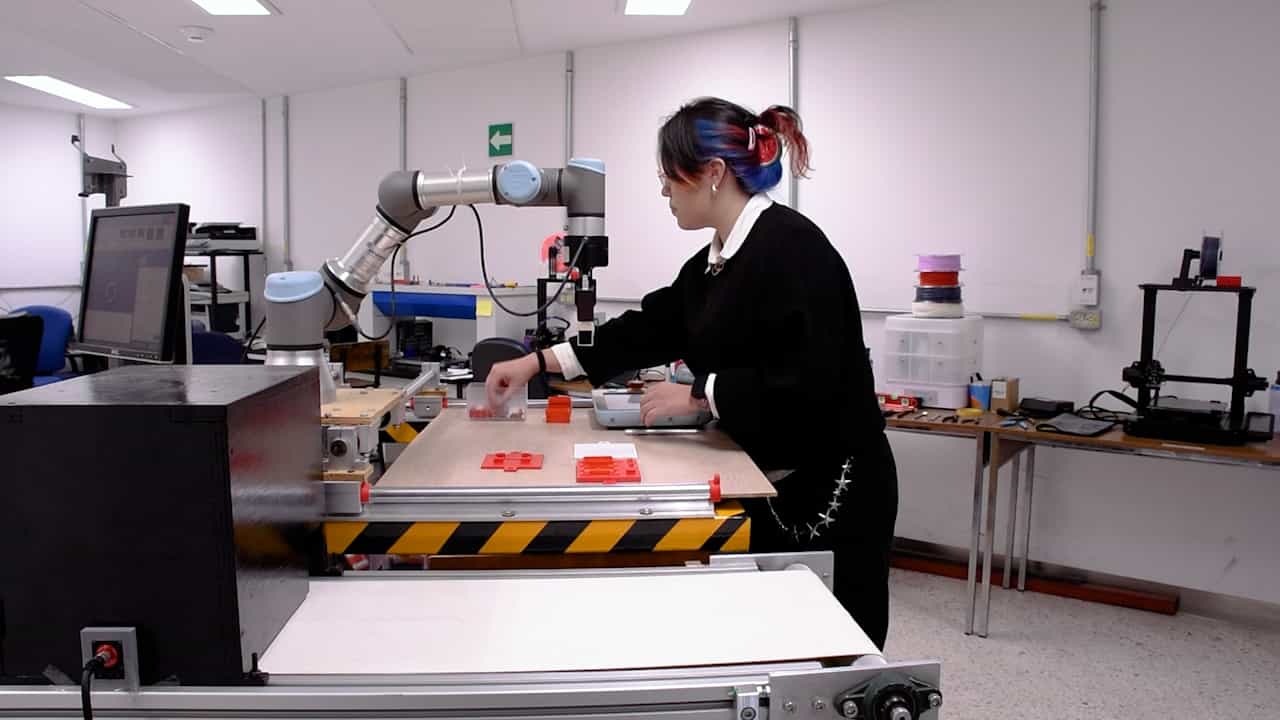
Simulation of a Scaled Assembly Process with Collaboration of a Robotic Arm and Monitoring through a Vision System for Quality Control
Published on: August 29, 2025
Practical Integration of Open-Source Control Architectures on Custom Quadruped Robots: Simulation Validation and
Vishnudev Kurumbaparambil1, Subashkumar Rajanayagam1, Stefan Twieg1
1Department of Electrical, Mechanical and Industrial Engineering, Hochschule Anhalt, Bernburger Str. 55, 06366 Köthen, Germany.

Abstract:
Custom-built quadrupedal platforms offer an accessible path for robotics research, yet researchers frequently encounter a "framework gap" when porting complex open-source control software to custom hardware. This paper documents the integration and validation process of Scotty, a custom quadrupedal robot, evaluating two distinct open-source control frameworks: the torque-based MIT Mini Cheetah and the position-based CHAMP architectures. Due to minimal documentation, hardware-dependent complexities, and a tightly coupled architecture, it was difficult to achieve a satisfactory result using the MIT framework within our system's scope. Conversely, CHAMP's structured integration documentation enabled the deployment of a locomotion pipeline validated in Gazebo simulation alongside a functional hardware interface middle layer. To overcome CHAMP's lack of native operational state management, we developed a custom state-based controller with a web-based GUI that safely orchestrates transitions across Idle, Ready, Down, Stand, and Walk configurations. While walking was successfully validated in the simulation environment to verify the control software pipeline, physical hardware evaluation was restricted to individual joint control, localized leg movements, and GUI-based parameter tuning. Full closed-loop hardware locomotion was not achieved, as the extensive tuning of gait parameters and controller gains under full system weight was bounded by project constraints. The integration logs, practical hurdles, and architectural lessons documented in this work are shared openly to provide a clear, transferable roadmap for future developers of robotic systems.

Related Concept Videos
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...