Related Experiment Video
Updated: Aug 14, 2026


Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
Sensorless Payload Estimation in an Industrial Robot Using Internal Motor-Current Signals
Adam Bátrla1, Ojan Majidzadeh Gorjani1, Radek Byrtus1
1Department of Cybernetics and Biomedical Engineering, Faculty of Electrical Engineering and Computer Science, VSB-Technical University of Ostrava, 708 00 Ostrava, Czech Republic.

Abstract:
This article presents a sensorless method for cycle-level payload mass estimation in industrial robots using internal motor-current signals only. The approach is based on automated KUKA Trace acquisition of six-axis current traces from a KUKA KR3 controller, followed by statistical feature extraction and regression using a multilayer perceptron (MLP). Experiments were conducted on two nominally identical KUKA KR3 R540 manipulators under a repeatable handling motion with payloads ranging from approximately 0.4 kg to 2.6 kg, enabling the systematic engineering validation of controller-based current acquisition, feature-based payload regression, and cross-robot validation. This study investigated whether motor-current signals could serve as a reliable virtual sensing source without external force or weight sensors. Under repeated operating conditions, the most accurate MLP configuration achieved a testing mean absolute error (MAE) of 6.75 g and a mean squared error (MSE) of 68.28 g2. With mixed-source training, using data from both robots, the testing MAE decreased to 5.37 g, and the accuracy within a ±15 g tolerance reached 96.88%. In contrast, direct transfer to another nominally identical robot increased the MAE to 80.54 g, revealing a clear cross-robot generalization gap. Overall, this study demonstrates the feasibility of motor-current-based payload verification during repeated single-axis motion under controlled conditions and indicates its potential for gripping validation and missing-part detection in industrial handling applications.

Related Concept Videos
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
 01:13
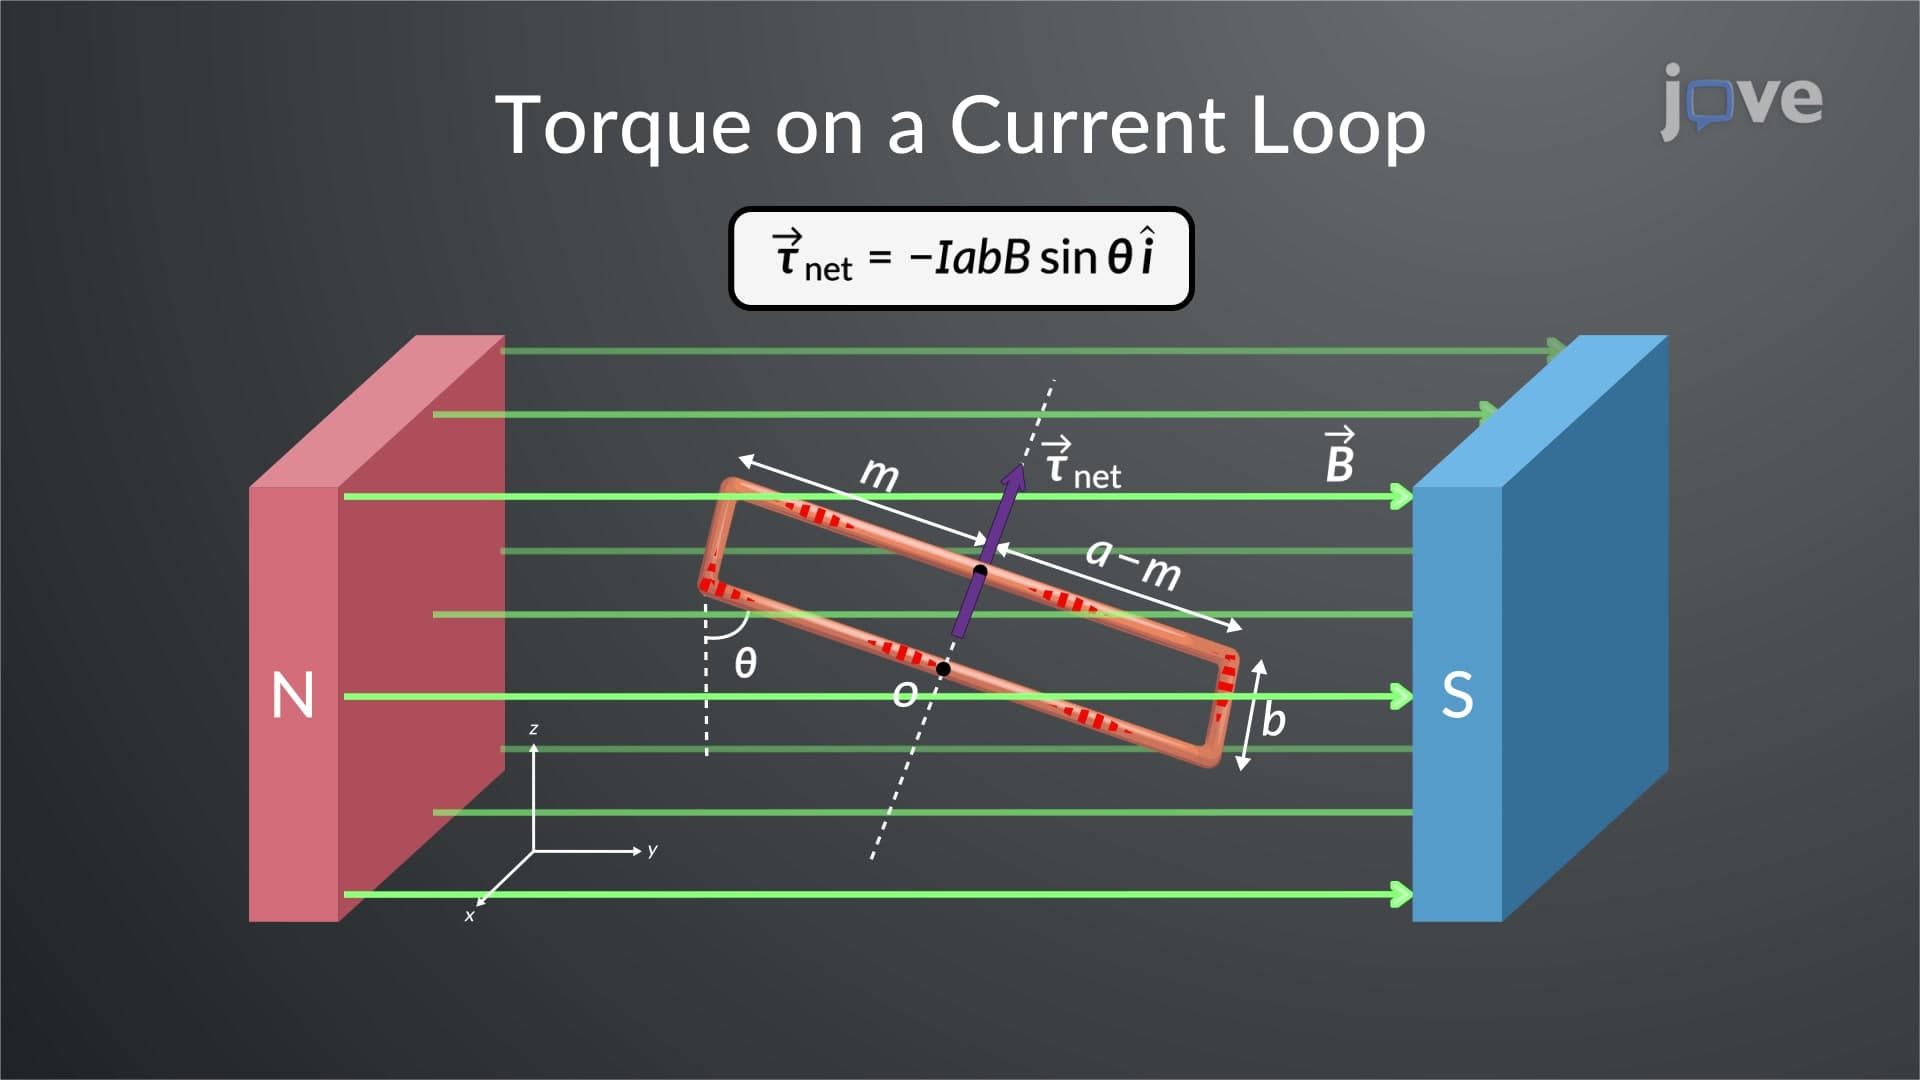
Torque On A Current Loop In A Magnetic Field
Consider a rectangular current-carrying loop containing N turns of wire, placed in a uniform magnetic field. The net force on a current-carrying loop...
 01:19
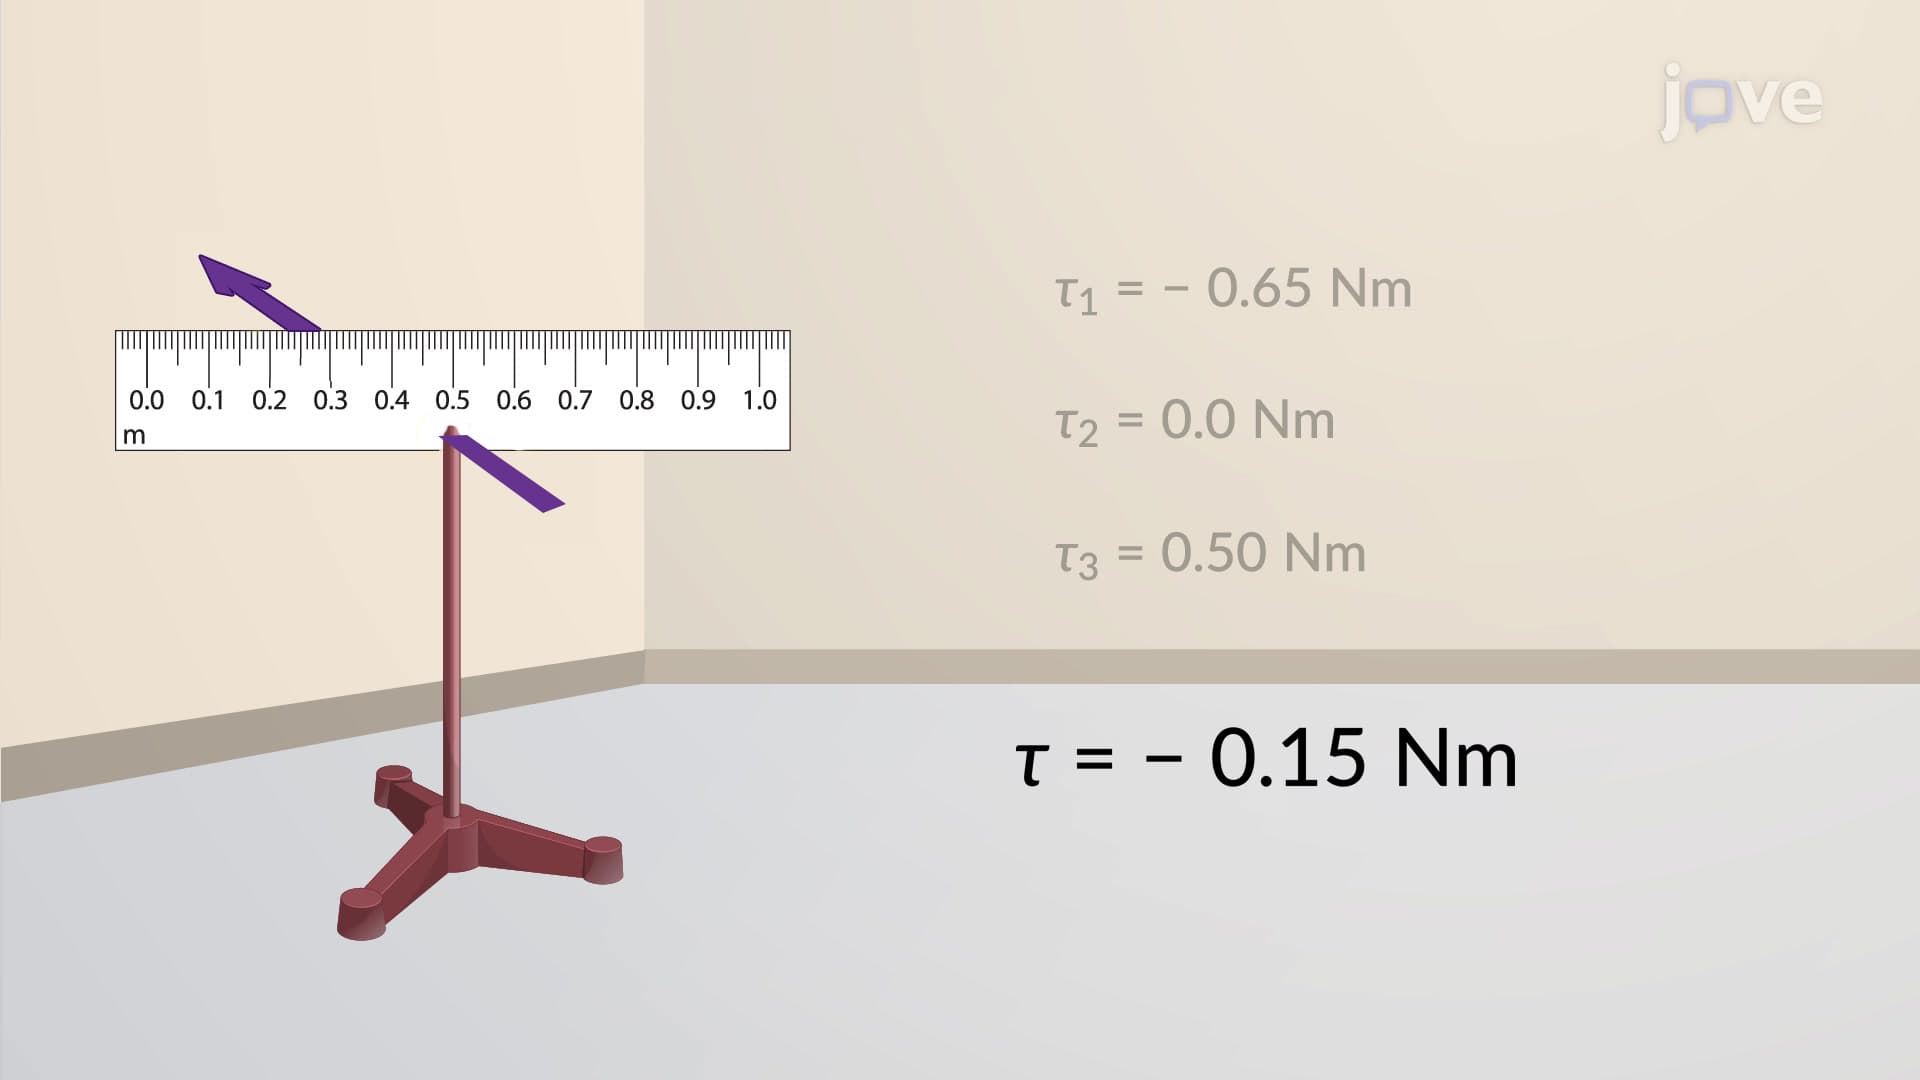
Net Torque Calculations
 01:22
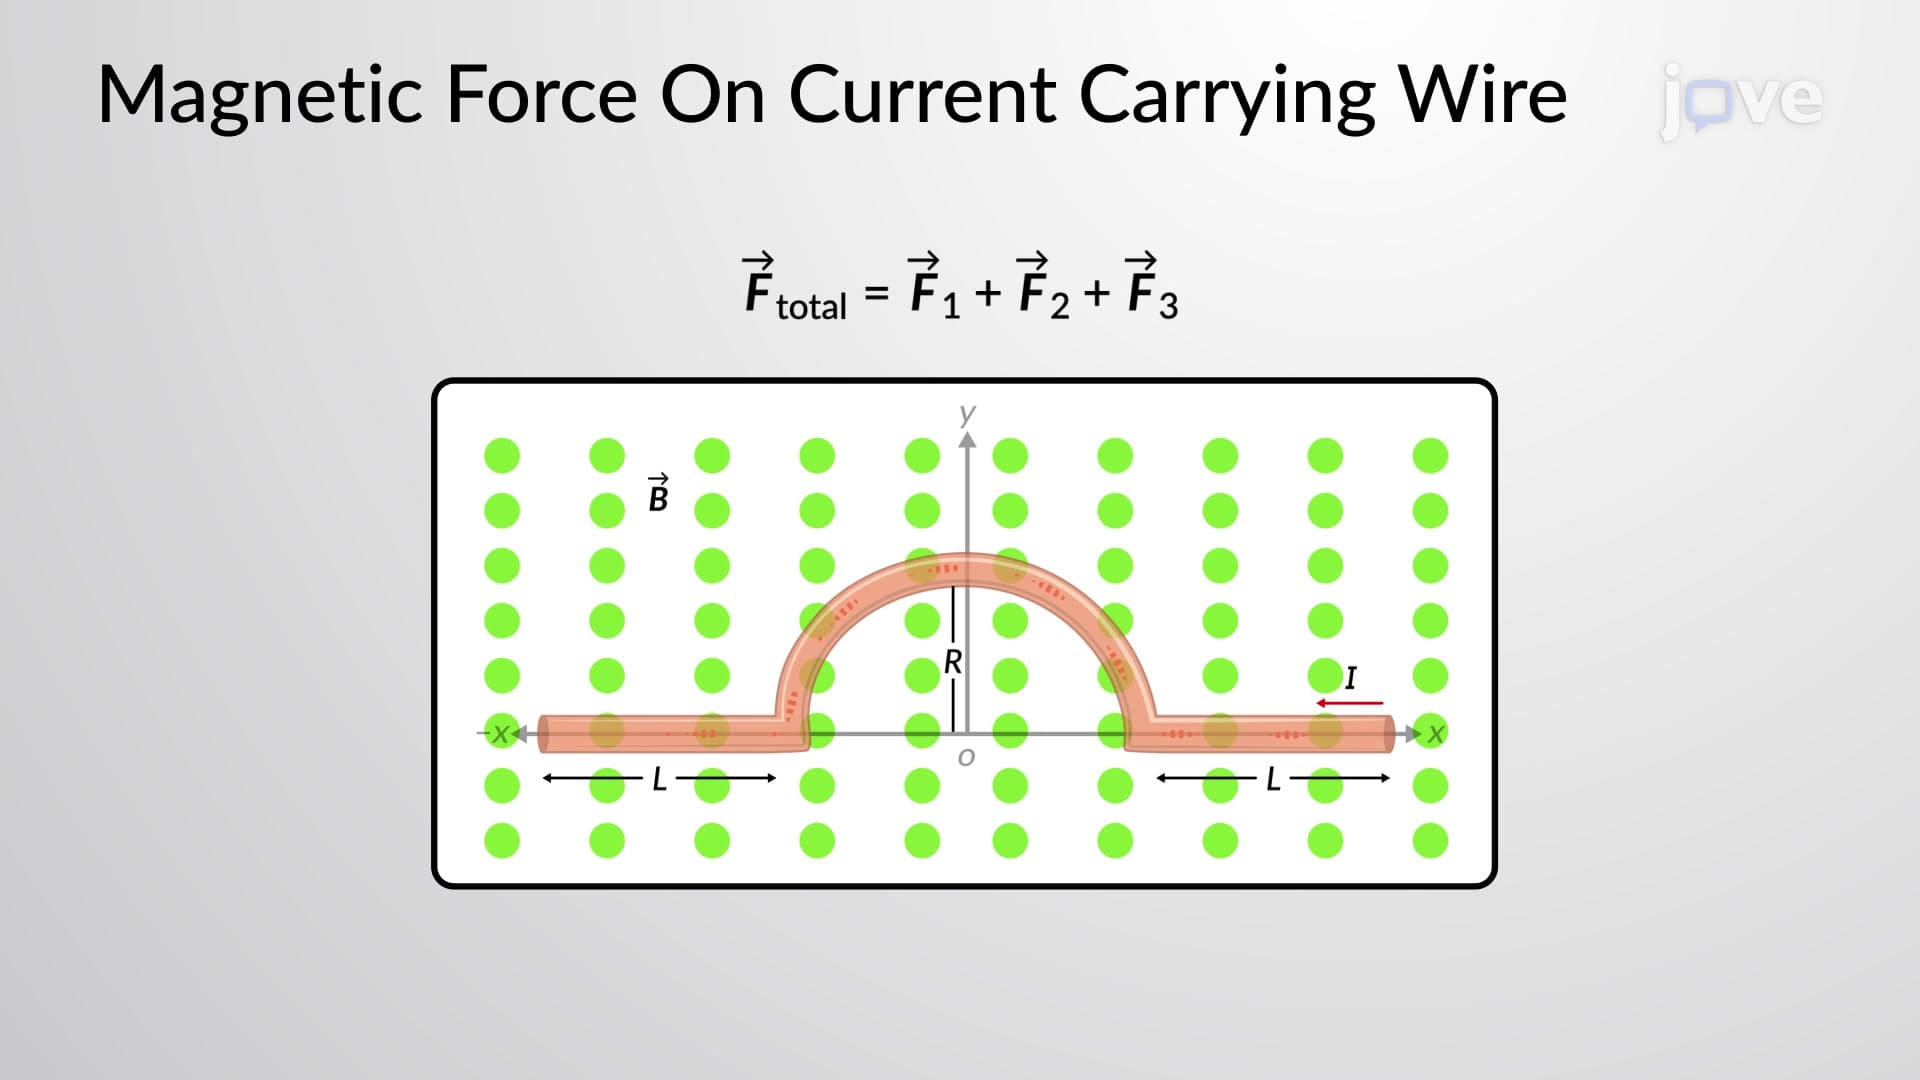
Magnetic Force On Current-Carrying Wires: Example
 01:30
Vector Functions and Motion: Problem Solving
 01:17
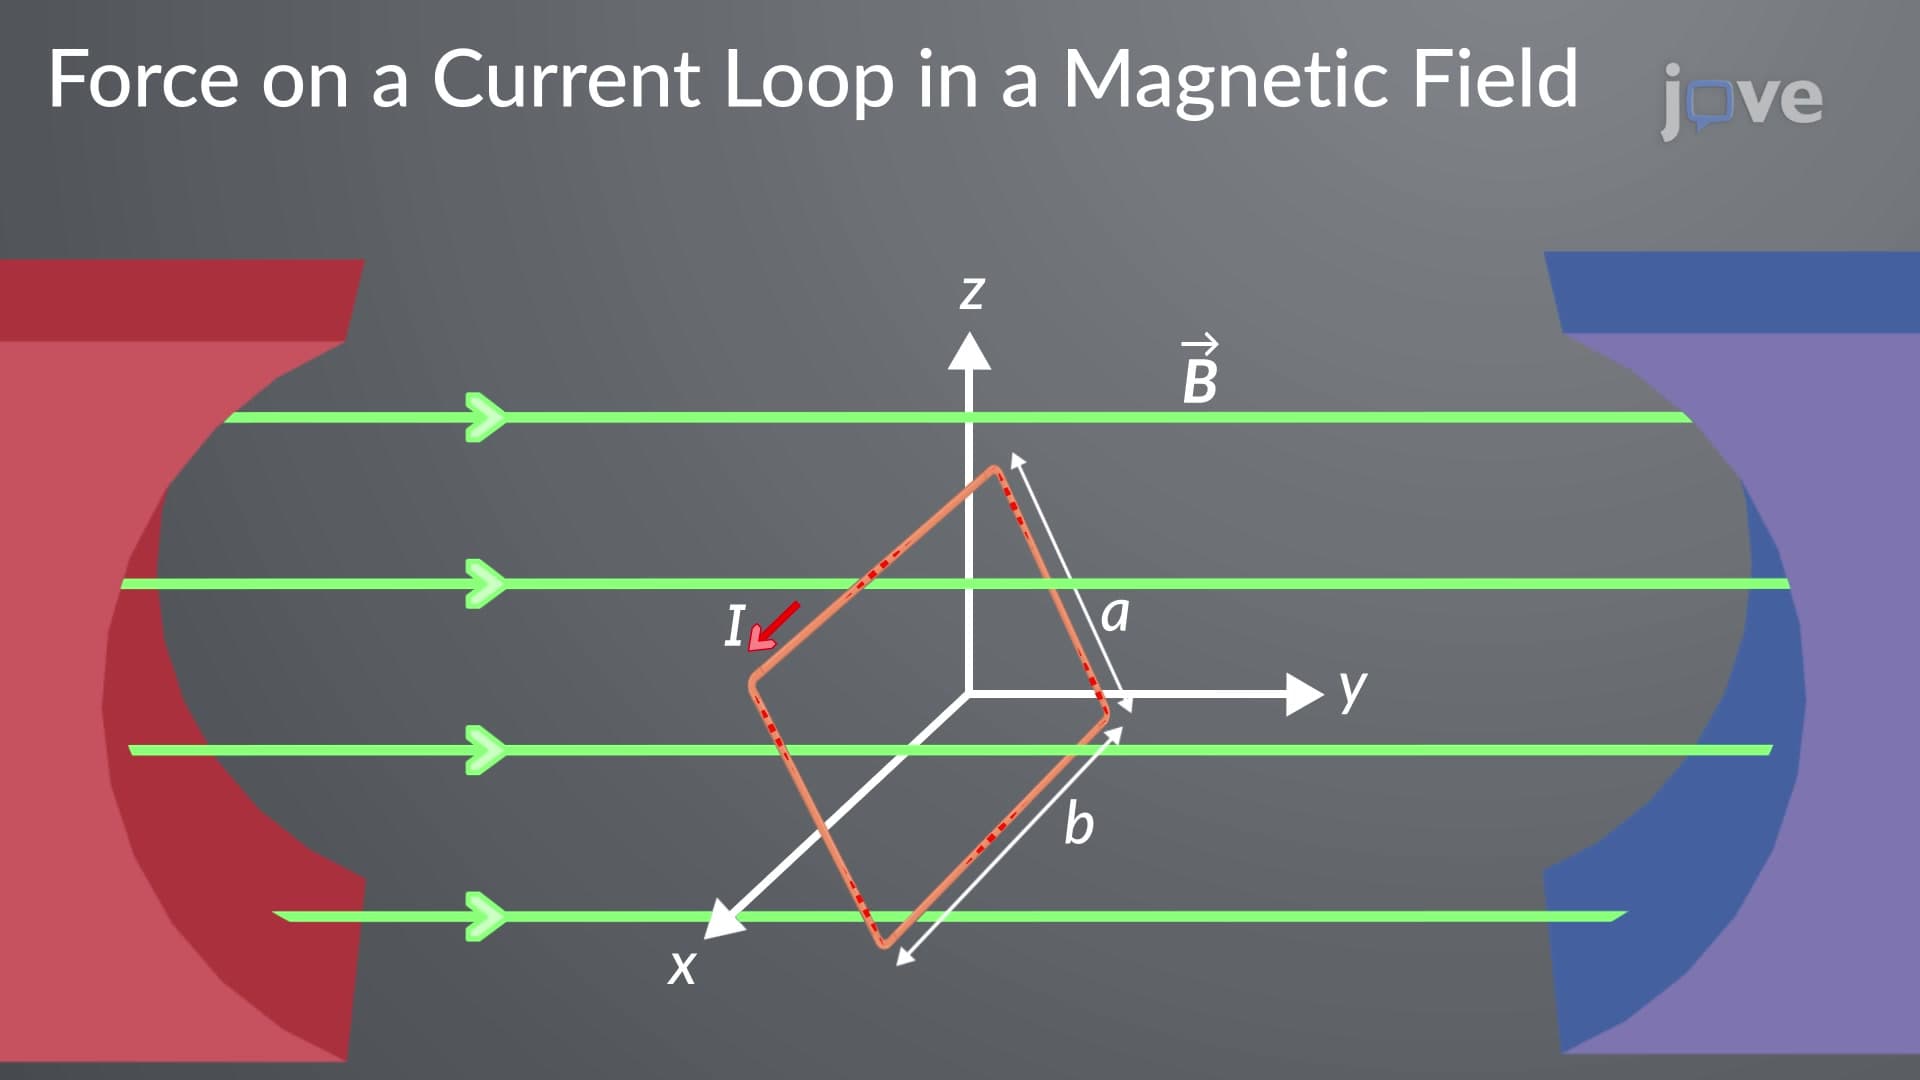
Force On A Current Loop In A Magnetic Field