Related Experiment Video
Updated: Aug 14, 2026


Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
Learning faults in time: sequential behavioural modelling for complex fault detection in multi-robot systems
Faisal Firas Mazloum1,2, David Portugal2, Micael S Couceiro1,2
1Ingeniarius, Lda., Porto, Portugal.

Abstract:
Reliable fault detection in multi-robot systems requires models capable of capturing complex, time-dependent fault signatures that manifest over extended temporal horizons rather than instantaneous observations alone. Existing data-driven approaches operate reactively on behavioural snapshots, failing to capture fault modes whose discriminative signature depends on temporally ordered precursors. This work formalises a theoretical impossibility result demonstrating that memoryless classifiers are provably insufficient, and presents a Long Short Term Memory (LSTM) model operating on generic, primitive behavioural features to learn these latent temporal dependencies without domain-specific priors. Two complex fault types are evaluated: progressive actuator degradation and intermittent actuator dropout, each paired with a distinct swarm movement pattern representing varying levels of temporal complexity. Experimental results demonstrate that sequential models are essential when the fault signature is defined by ordered precursors, while memoryless models partially suffice for simpler temporal structures. Compute benchmarks confirm real-time feasibility for distributed onboard deployment.

Related Concept Videos
 01:12
Types of Errors: Detection and Minimization
Absolute error in a measurement is the numerical difference from the true or central value. Relative error is the ratio between absolute error and the true or central value, expressed as a percentage.
Errors can be classified by source, magnitude, and sign. There are three types of errors: systematic, random, and gross.
Systematic or...
 02:16
Stereotype Content Model
 01:18
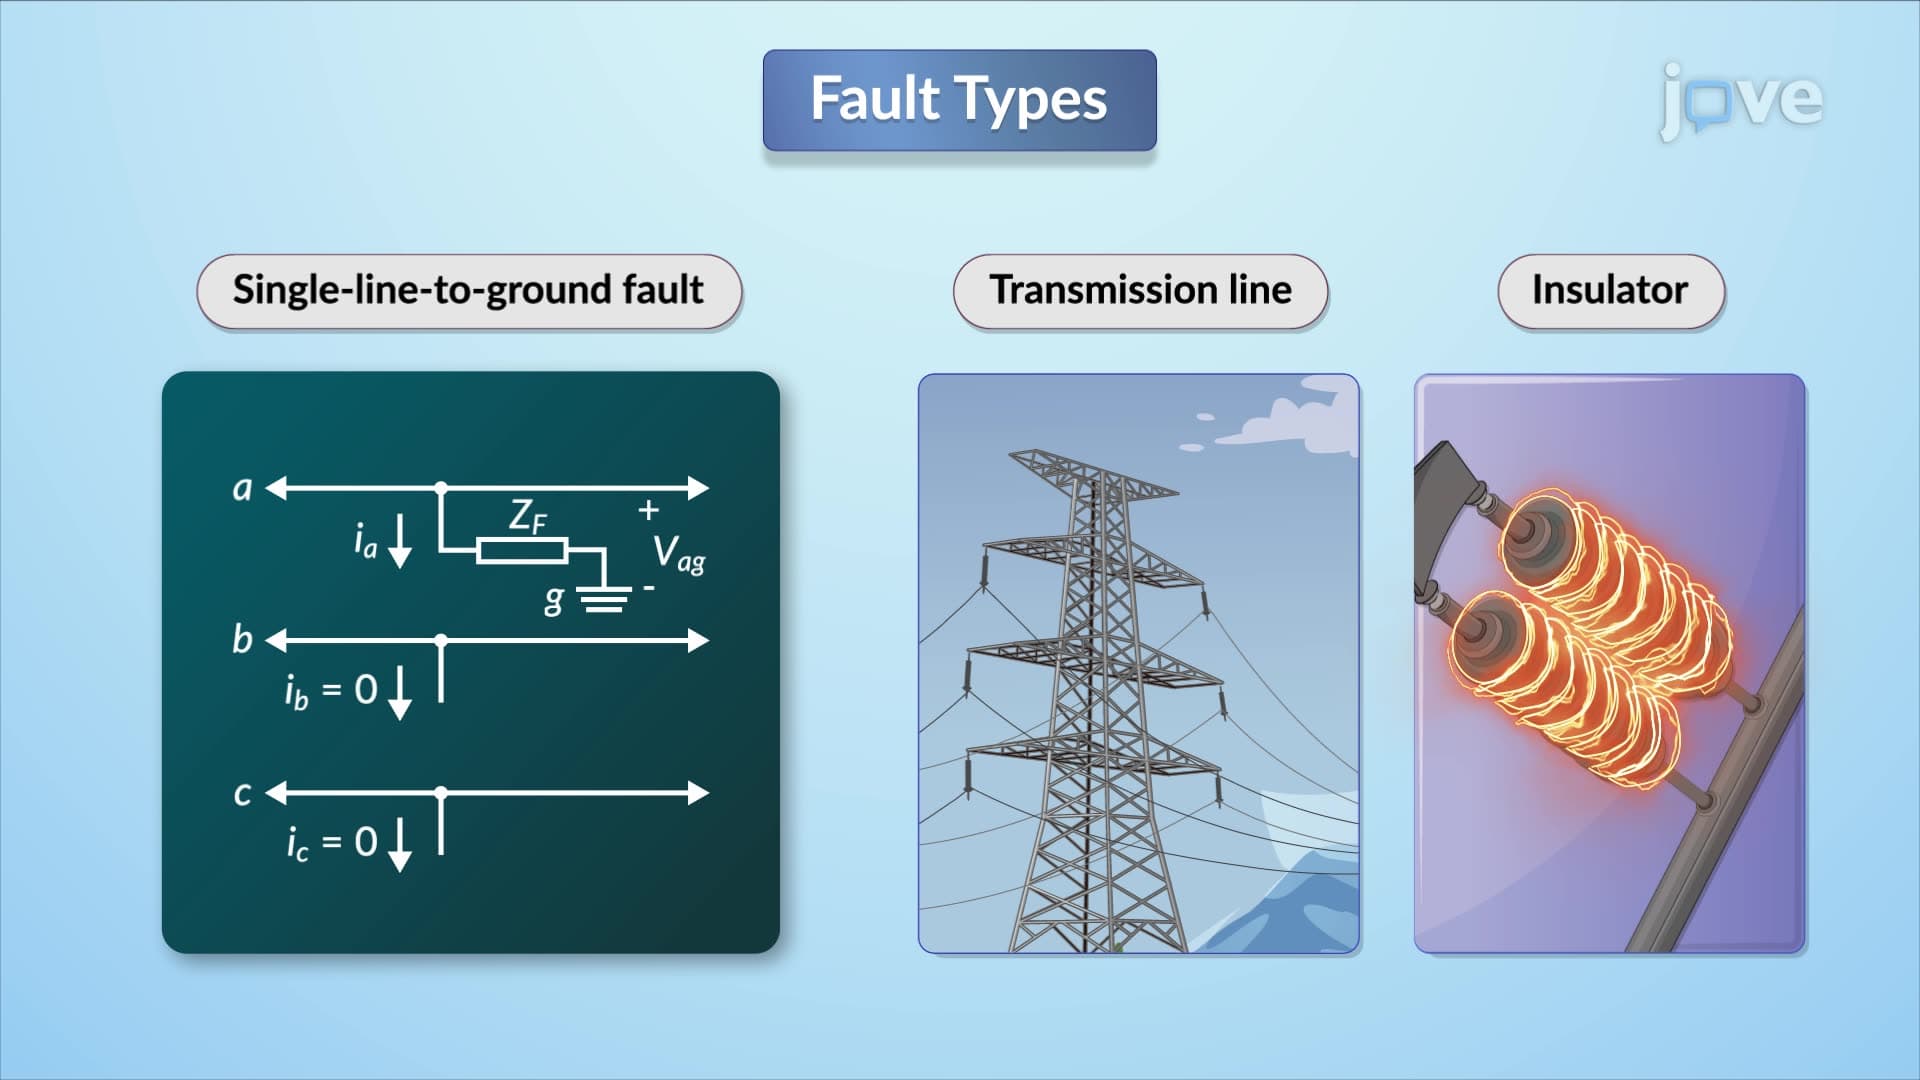
Fault Types
For line-to-line faults occurring between phases B and C, the...
 01:25
Multimachine Stability
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
 01:21
Distributed Loads: Problem Solving