Related Experiment Video
Updated: Aug 15, 2026

Folding and Characterization of a Bio-responsive Robot from DNA Origami
Published on: December 3, 2015
Geometry-Encoded Actuation as a Structural Interaction Layer in Origami Robots
Jianshu Zhou1, Yitong Li1, Junda Huang2
1Department of Mechanical Engineering, National University of Singapore, Singapore.

Abstract:
Physical interaction in robotics predominantly relies on sensing, computation, and feedback control, resulting in increasing system complexity. Here, we introduce geometry-encoded actuation (GEA), a design framework that exploits multistable origami geometries as programmable physical interaction layers to mechanically encode environmental stimuli into autonomous structural responses. By integrating multistable origami with liquid crystal elastomer (LCE) actuators, GEA couples structural geometry, energy landscapes, and stimuli-responsive actuation to achieve programmable shape transformation without continuous sensing or complex control during the interaction process. A theoretical framework based on spherical geometry, energy analysis, and structural optimization is established to guide the design of bistable origami mechanisms. The proposed framework is validated through representative robotic systems, including a bistable origami gripper, an adaptive origami wheel, and autonomous locomotion and manipulation demonstrations, achieving up to 45% actuation strain, 106 programmable geometric transformation, 100% task success in 10 consecutive trials, and stable operation after 500 actuation cycles. By embedding interaction intelligence directly into structural geometry, GEA redistributes part of the interaction complexity from computation to morphology, providing a general framework for programmable physical intelligence and adaptive embodied robotic systems.
Related Concept Videos
 01:15
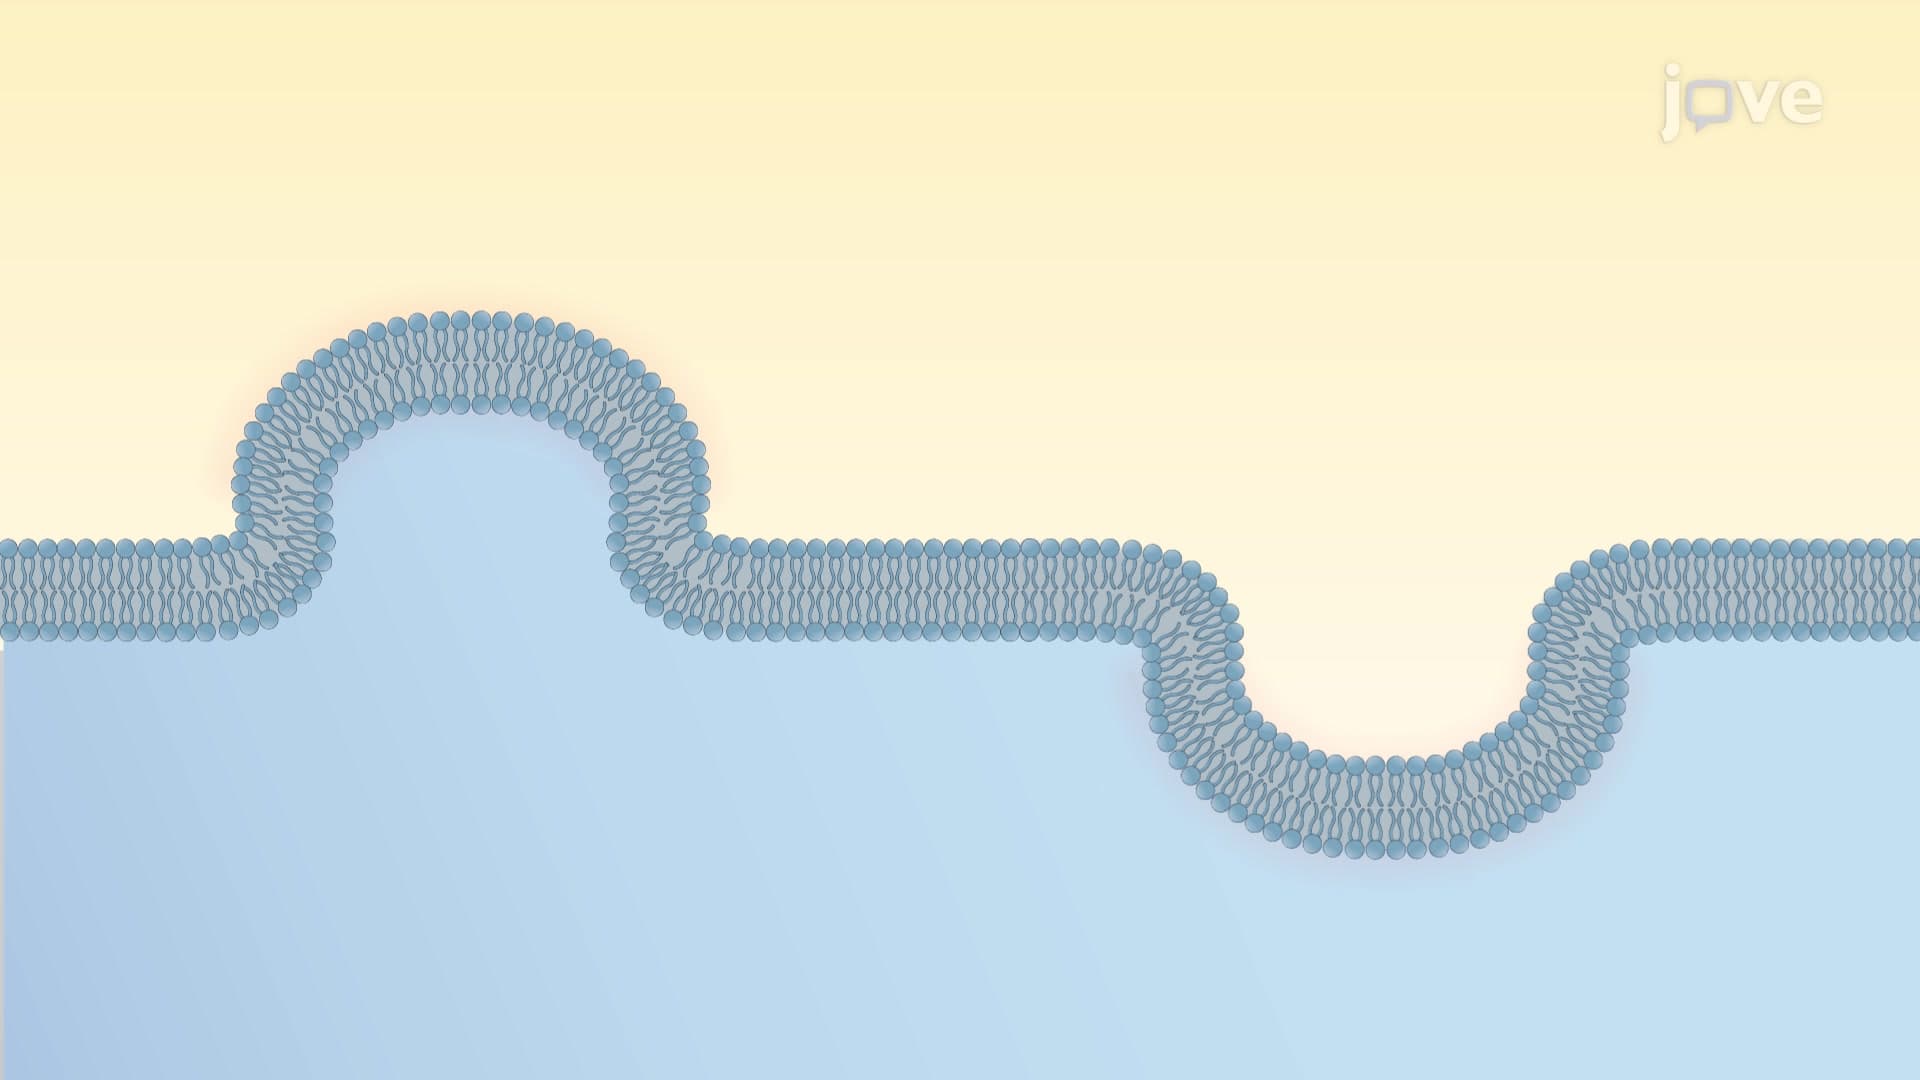
Mechanisms of Membrane-bending
Membrane bending can happen due to intrinsic changes in lipid composition or extrinsic association with different proteins. The proteins involved...
 01:39
Mechanism of Filopodia Formation
Their main function is to guide migrating cells during normal tissue morphogenesis or cancer metastasis by recognizing and making initial contacts with the extracellular matrix. However, they can also act as stationary cell anchors or help to establish communication...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:14
Generation of Straight or Branched Actin Filaments
Arp2/3 Complex
Arp2/3 complex is a seven-subunit complex consisting of two proteins similar to actin- Arp2 and Arp3, and five other subunits that help keep Arp2 and Arp3 inactive. When required, the complex is...
 01:30
Three-Dimensional Force System
 01:20
Plastic Deformation in Circular Shafts