Related Experiment Video
Updated: Aug 15, 2026
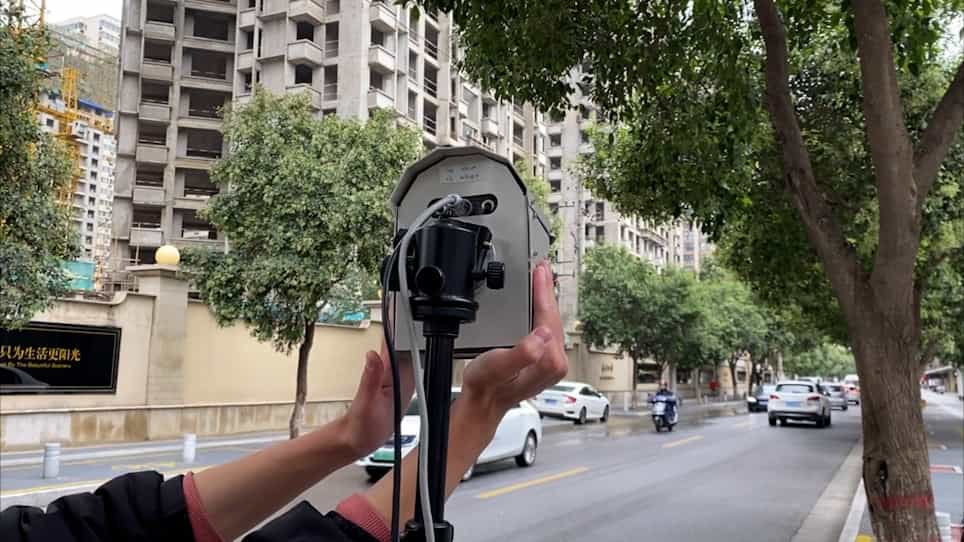

Evaluating the Effect of Roadside Parking on a Dual-Direction Urban Street
Published on: January 20, 2023
Geometric and operational determinants of motor vehicle-bicycle overtaking on Brazilian urban roads
Ellen Pinto1, Caio Torres1, Flávio Cunto1
1Department of Transportation Engineering, Federal University of Ceará, Fortaleza, Brazil.

Objective:
Overtaking maneuvers between motor vehicles and bicycles (OVB) represent a critical hazard for cyclists due to required lateral clearances and vehicle speeds. This study aims to evaluate the OVB process in urban environments, focusing on the main geometric and operational attributes that influence cyclists' objective road safety indicators.
Methods:
A quasi-naturalistic observational study was conducted on urban roads in Fortaleza, Brazil, using an instrumented bicycle. Data on vehicle speed, lateral passing distance, lane configuration, vehicle type, and the presence of adjacent traffic were collected across 1,075 overtaking maneuvers. Statistical analyses were performed to assess the impact of these attributes on safety indicators.
Results:
Analysis revealed that 76% of observed passing maneuvers violated the Brazilian national recommendation of maintaining a minimum lateral distance of 1.50 m. The presence of cycling infrastructure and the absence of traffic in adjacent lanes were significantly associated with greater passing distances. Furthermore, a behavioral compensatory threshold was identified at a 0.85-meter lateral distance: drivers modulated speed as a risk-mitigation mechanism only during critical clearances, whereas no speed adjustments were observed at the 1.50-meter legal threshold.
Conclusions:
A vast majority of drivers fail to comply with recommended passing distances, highlighting the need for targeted infrastructure and operational interventions. The existence of dedicated cycling facilities effectively improves lateral separation. Moreover, drivers adapt speed only under extreme proximity (under 0.85 m), demonstrating that legal limits alone do not induce safer driver behavior without structural or physical support.
Related Concept Videos
 01:18
Hierarchy of Motor Control
 01:17
Rolling Resistance: Problem Solving
 01:29
Sight Distance in a Vertical Curve
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
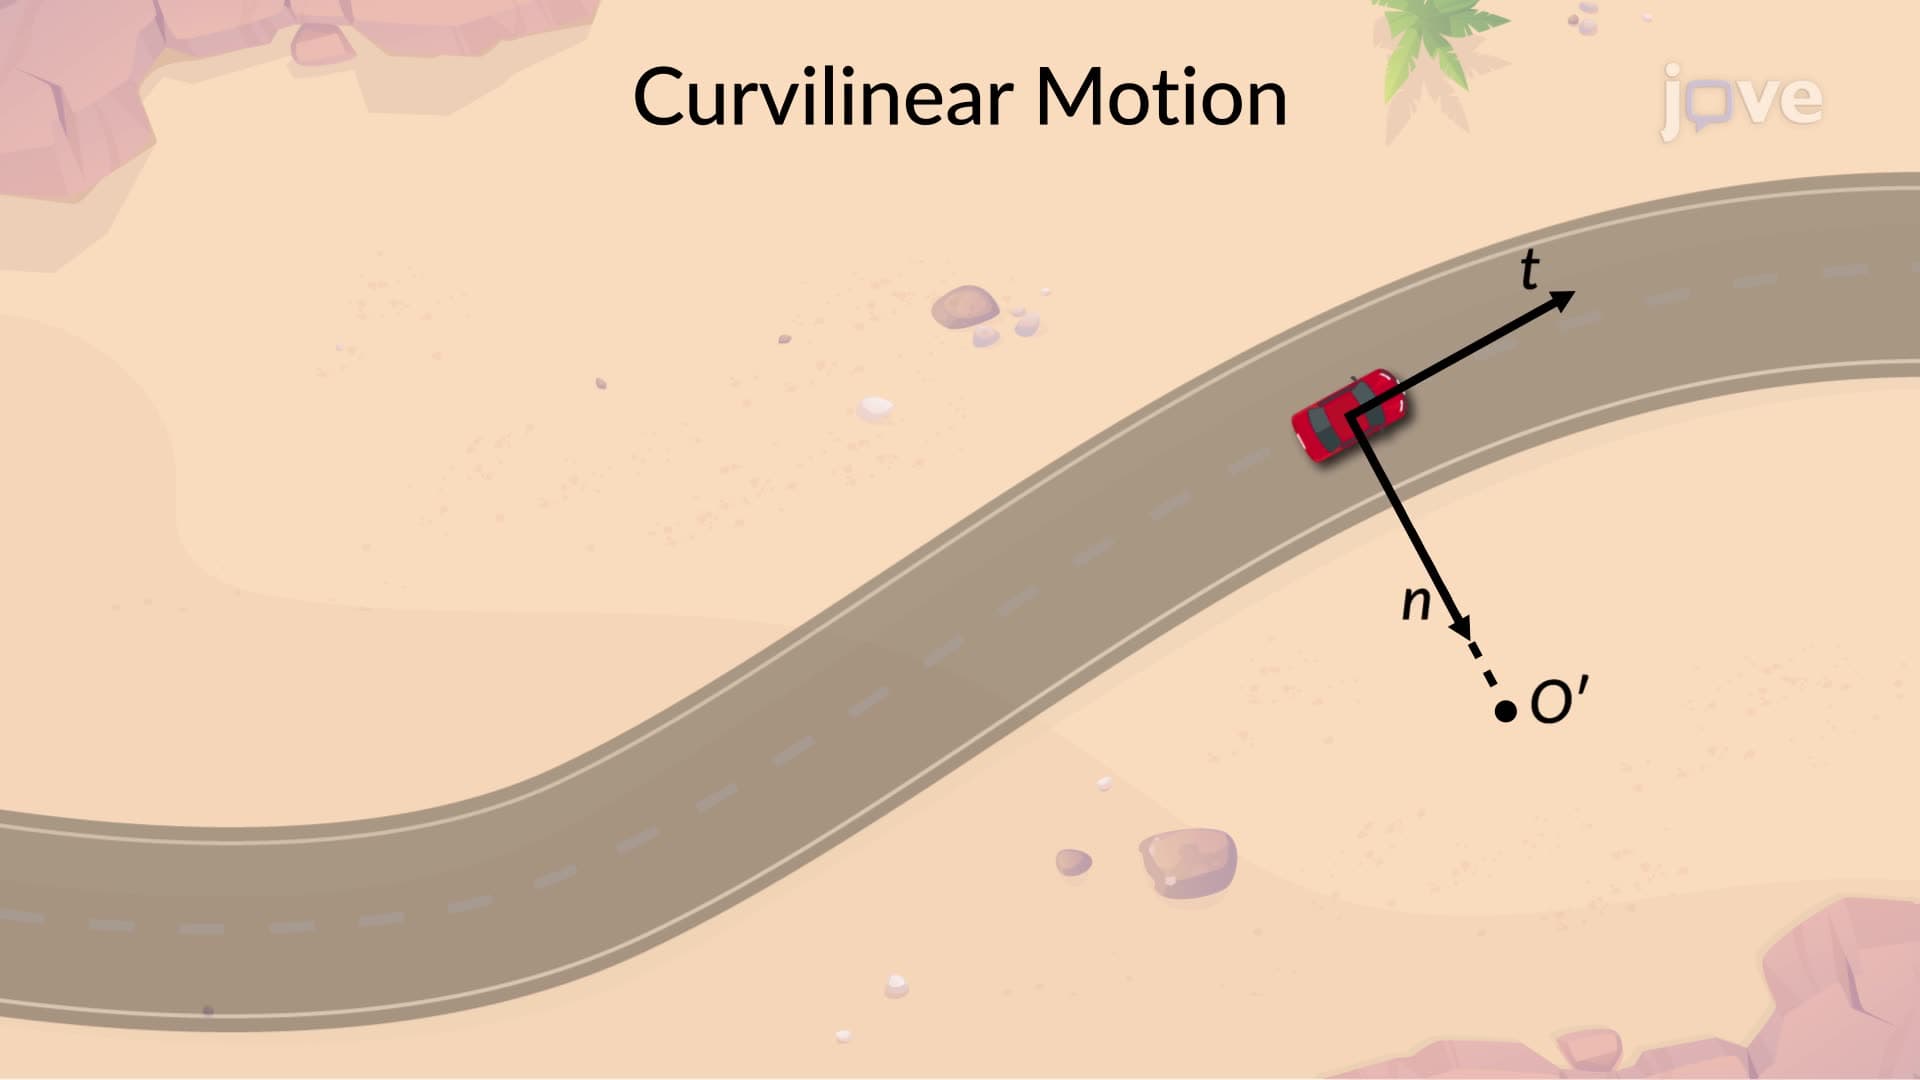 01:27
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...