Entry Point Localisation for Percutaneous Surgical Robots Based on Concentric Fiducial Patches and Robust Surface Fitting
Related Experiment Video
Updated: Sep 11, 2026
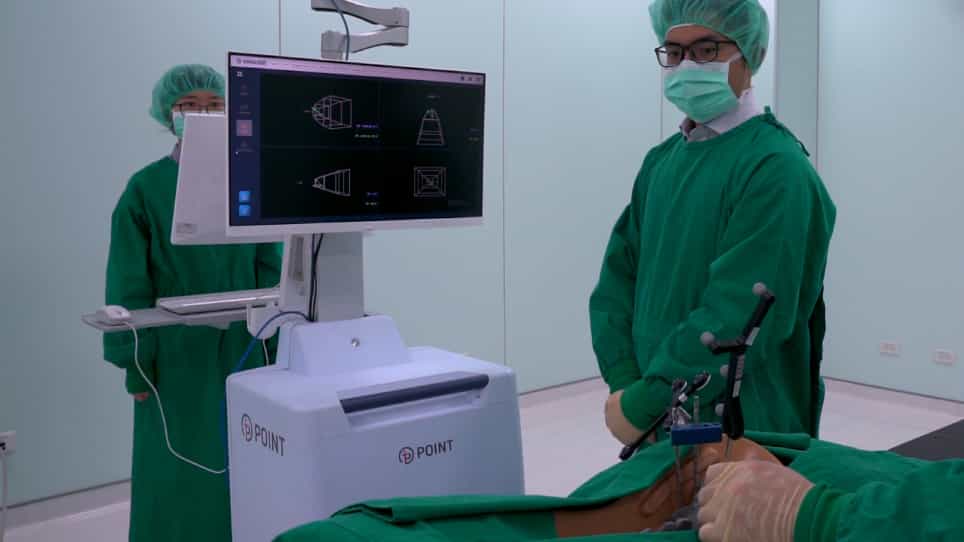
A Spine Robotic-Assisted Navigation System for Pedicle Screw Placement
Published on: May 11, 2020
Youming Deng1, Qi Jiang1,2, Jie Wang1
1School of Control Science and Engineering, Shandong University, Jinan, Shandong, China.

Background:
Accurate entry point localisation is critical for the safety of robot-assisted percutaneous interventions (RAPI). However, medical optical tracking systems for the traditional fiducial patch are cost-prohibitive. To address these challenges, this paper proposes a robust entry point and gesture localisation framework based on an inexpensive concentric fiducial patch and robust surface fitting.
Methods:
We introduce an anisotropic iteratively reweighted least squares (IRLS) algorithm integrated with a Tukey biweight M-estimator, employing a deterministic soft-weighting strategy to effectively suppress gross outliers and smooth out high-frequency sensor noise.
Results:
Experimental results demonstrate that the proposed method has high accuracy and robustness, achieving an MAE of 1.47 mm in dynamic respiratory tracking and maintains stable detection even under 60% occlusion and low-light conditions.
Conclusions:
The results suggest that this framework provides a reliable and low-cost solution for surgical navigation in unstructured clinical environments.