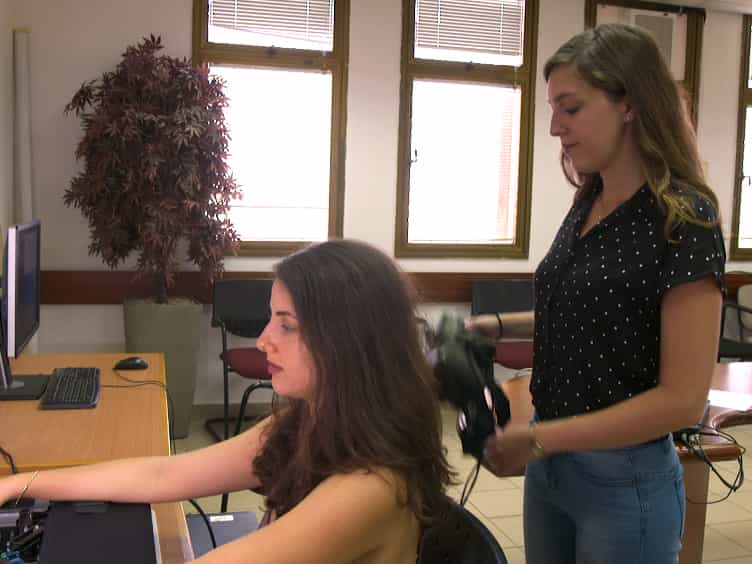
Related Experiment Video
Updated: Sep 12, 2026
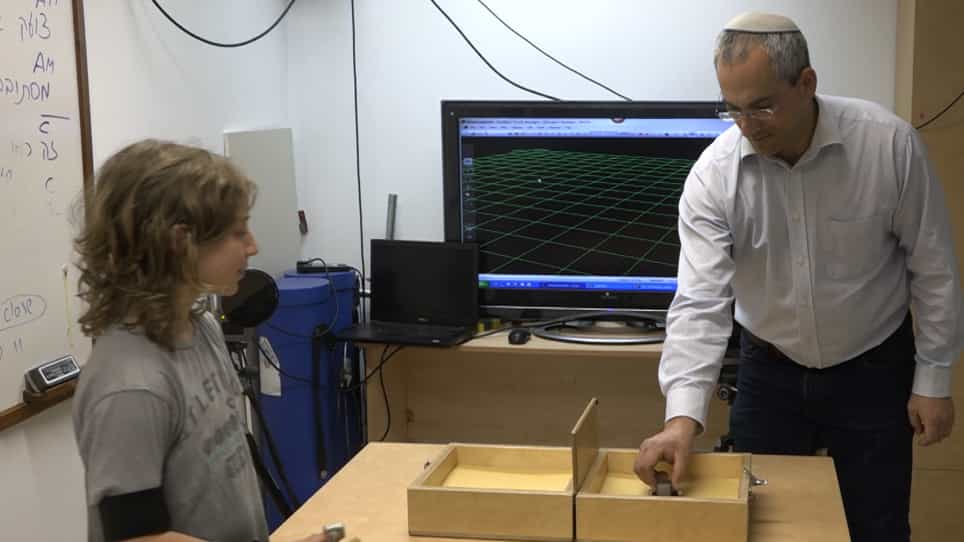

Applying Incongruent Visual-Tactile Stimuli during Object Transfer with Vibro-Tactile Feedback
Published on: May 23, 2019
Effects of selective sensory-feedback absence on reach-to-grasp kinematics in virtual reality
Muhammad Awais Hafeez1, Asim Ghaffar2, Tayyaba Roshni3
1Department of Mechanical, Mechatronics and Manufacturing Engineering, University of Engineering and Technology Lahore, Faisalabad campus, Pakistan.

Objectives:
We investigated spatiotemporal kinematics of reach-to-grasp movements in virtual environments (VEs) with different sensory feedback and compared them with natural prehension in a physical environment. Aim determined how combinations of haptic and visual feedback influence performance in VR.
Methods:
Participants performed reach-to-grasp tasks with objects of sizes placed at two distances under three conditions: physical environment with full sensory feedback, VE with haptic feedback but no hand vision, and VE with hand vision but no haptic feedback. Hand movements were tracked using HTC Vive and Leap Motion, with kinematic recording from Optotrak. Variables analyzed included peak reaching velocity, movement time, deceleration time, and grip aperture.
Results:
Movements in virtual environments showed lower and earlier peak velocities, longer movement and deceleration times, and larger grip apertures than the physical environment. VEs haptic feedback without vision produced wider grip apertures than vision without haptics. Despite these differences, coordination between reaching and grasping components remained consistent with natural prehension patterns.
Conclusions:
This study provides insights into the trade-offs between visual and haptic sensory feedback in VR-based prehension. It highlights the importance of sensory integration for effective reach-to-grasp performance and offers guidance for the design of virtual reality systems and experimental protocols investigating motor control.