Related Experiment Video
Updated: Sep 14, 2026


A Flexible Wearable Supernumerary Robotic Limb for Chronic Stroke Patients
Published on: October 27, 2023
PhysGuided-PPO: Physics-guided proximal policy optimization for energy-dissipative soft grasping
Siyun Yang1, You Zhong1, Yuehang Liu1
1School of Aeronautics and Astronautis, Sichuan University, Chengdu, 610065, China.

Abstract:
Dynamic soft grasping involves short-duration impacts, rapid energy transfer, and transient contact-pressure peaks that are difficult to regulate using simplified controllers or data-driven exploration alone. This paper proposes PhysGuided-PPO, a lightweight physics-guided extension of proximal policy optimization for energy-dissipative pneumatic soft grasping. An offline-trained one-step predictor estimates the immediate impact response of candidate valve commands and uses these predictions to bias the Bernoulli logit of the on-off valve and the Gaussian mean of the proportional valve during action sampling. Simulations over 0.18-0.50 m/s impacts show that PhysGuided-PPO increases energy dissipation from 91.2% and 93.4% to 96.8%, while reducing peak contact pressure from 2.46 and 2.32 N/cm2 to 2.17 N/cm2. These results indicate that short-horizon predictive guidance can improve impact-aware valve control while retaining the on-policy PPO training structure.

Related Concept Videos
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:10
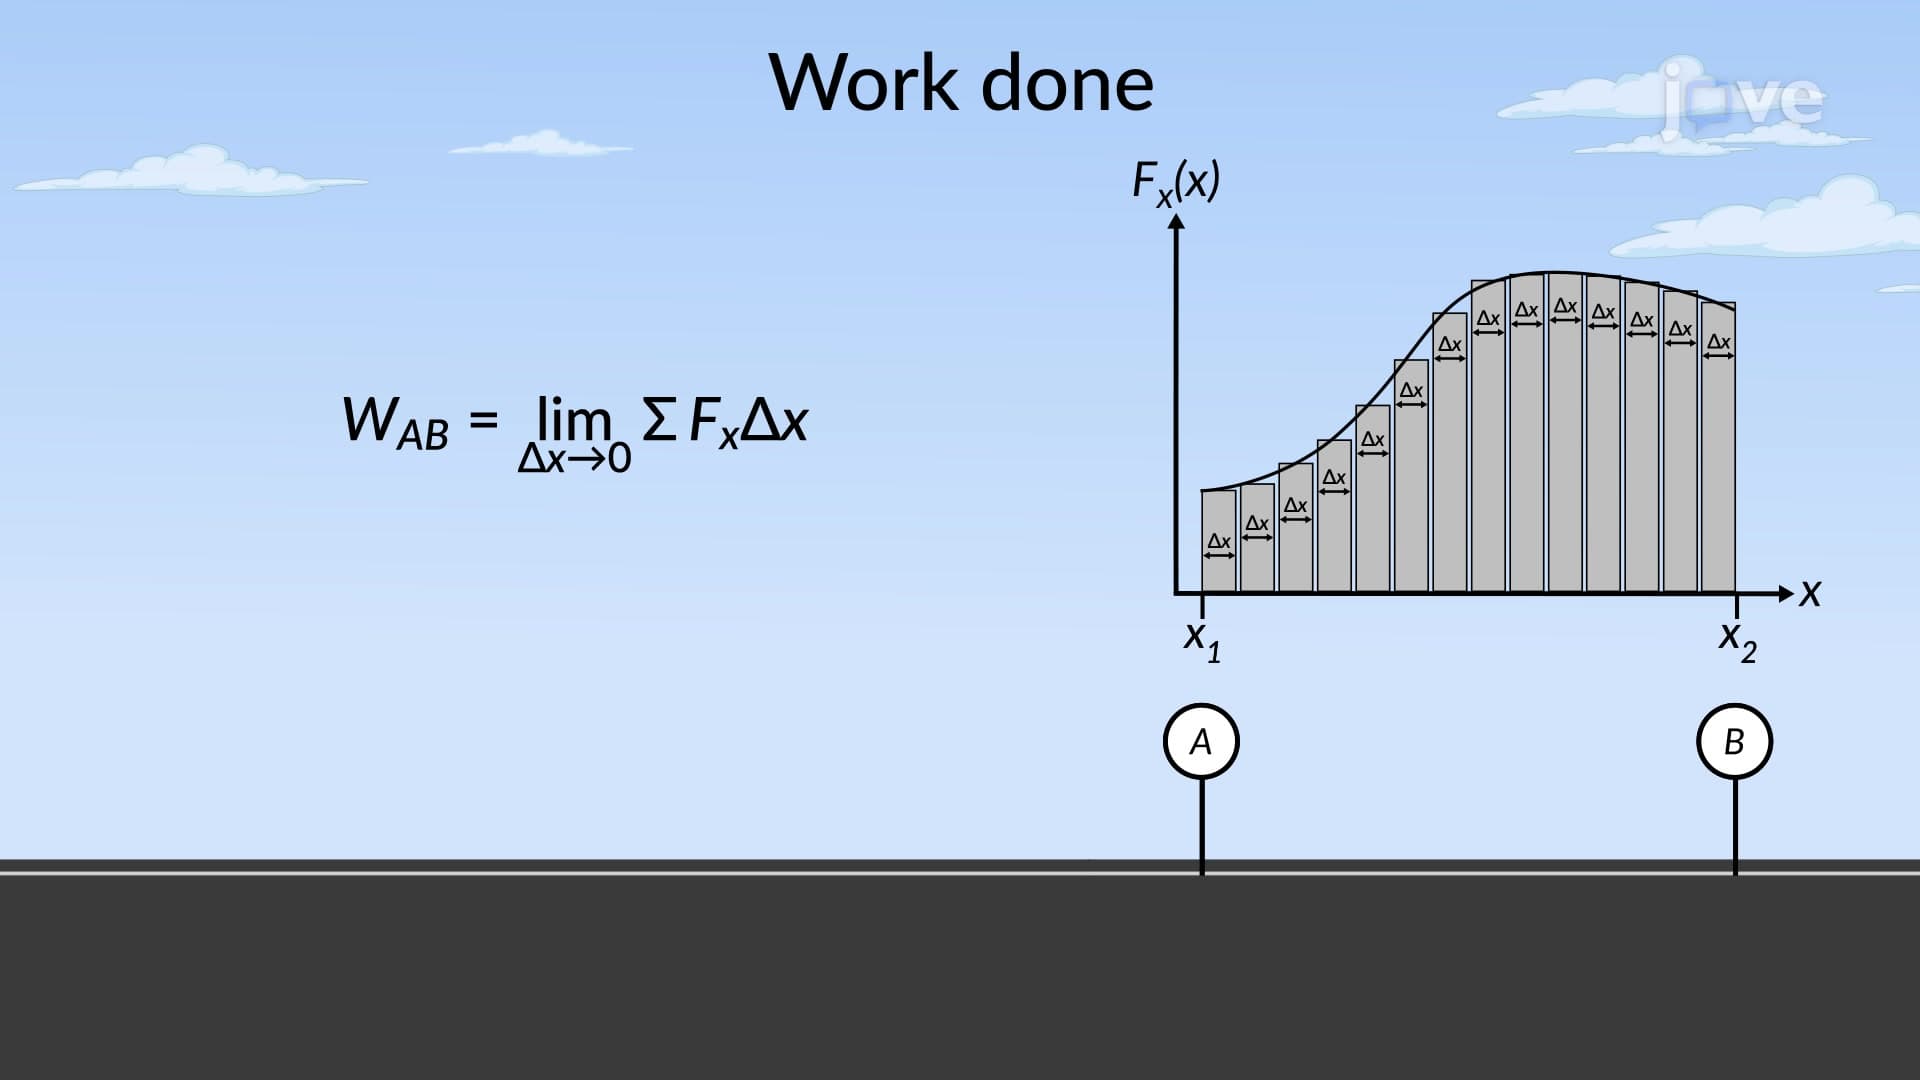
Work and Energy for Variable Forces