Related Experiment Videos
A computational framework for stability-constrained offline PI tuning of BLDC FOC systems using gray wolf
Rakhmat Agung Ramadhani1, Ika Noer Syamsiana1, Arwin Datumaya Wahyudi Sumari2
1Department of Electrical Engineering, State Polytechnic of Malang, Malang, East Java, 65141, Indonesia.

Abstract:
Proportional-Integral (PI) controllers are widely used in Field-Oriented Control (FOC) systems for Brushless DC (BLDC) motors because they are simple. However, their performance relies heavily on proper parameter tuning. Traditional methods like Ziegler-Nichols or trial-and-error can give unpredictable results when operating conditions or loads change. This study introduces a computer-based approach for stable offline PI tuning in BLDC FOC systems using the Gray Wolf Optimization (GWO) algorithm. • The proposed framework integrates mathematical modeling of the BLDC motor, stability rules, multi-objective evaluation, and automated optimization steps into a single software process. • The proposed framework also offers repeatable tuning steps, methods for setting initial parameters, progress tracking, and performance checks, making it easier to reuse in engineering projects. • The results show that this method significantly improves system response. With no load, speed overshoot dropped from about 20% (0.96 pu) in standard FOC to around 3% (0.82 pu) with FOC-GWO, and the initial torque surge decreased from 0.118 pu to 0.072 pu. When a load disturbance occurs, the FOC-GWO system has a smaller speed drop, recovers faster, and shows less fluctuation in speed and torque than the traditional method.
Related Concept Videos
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's response.
 01:19
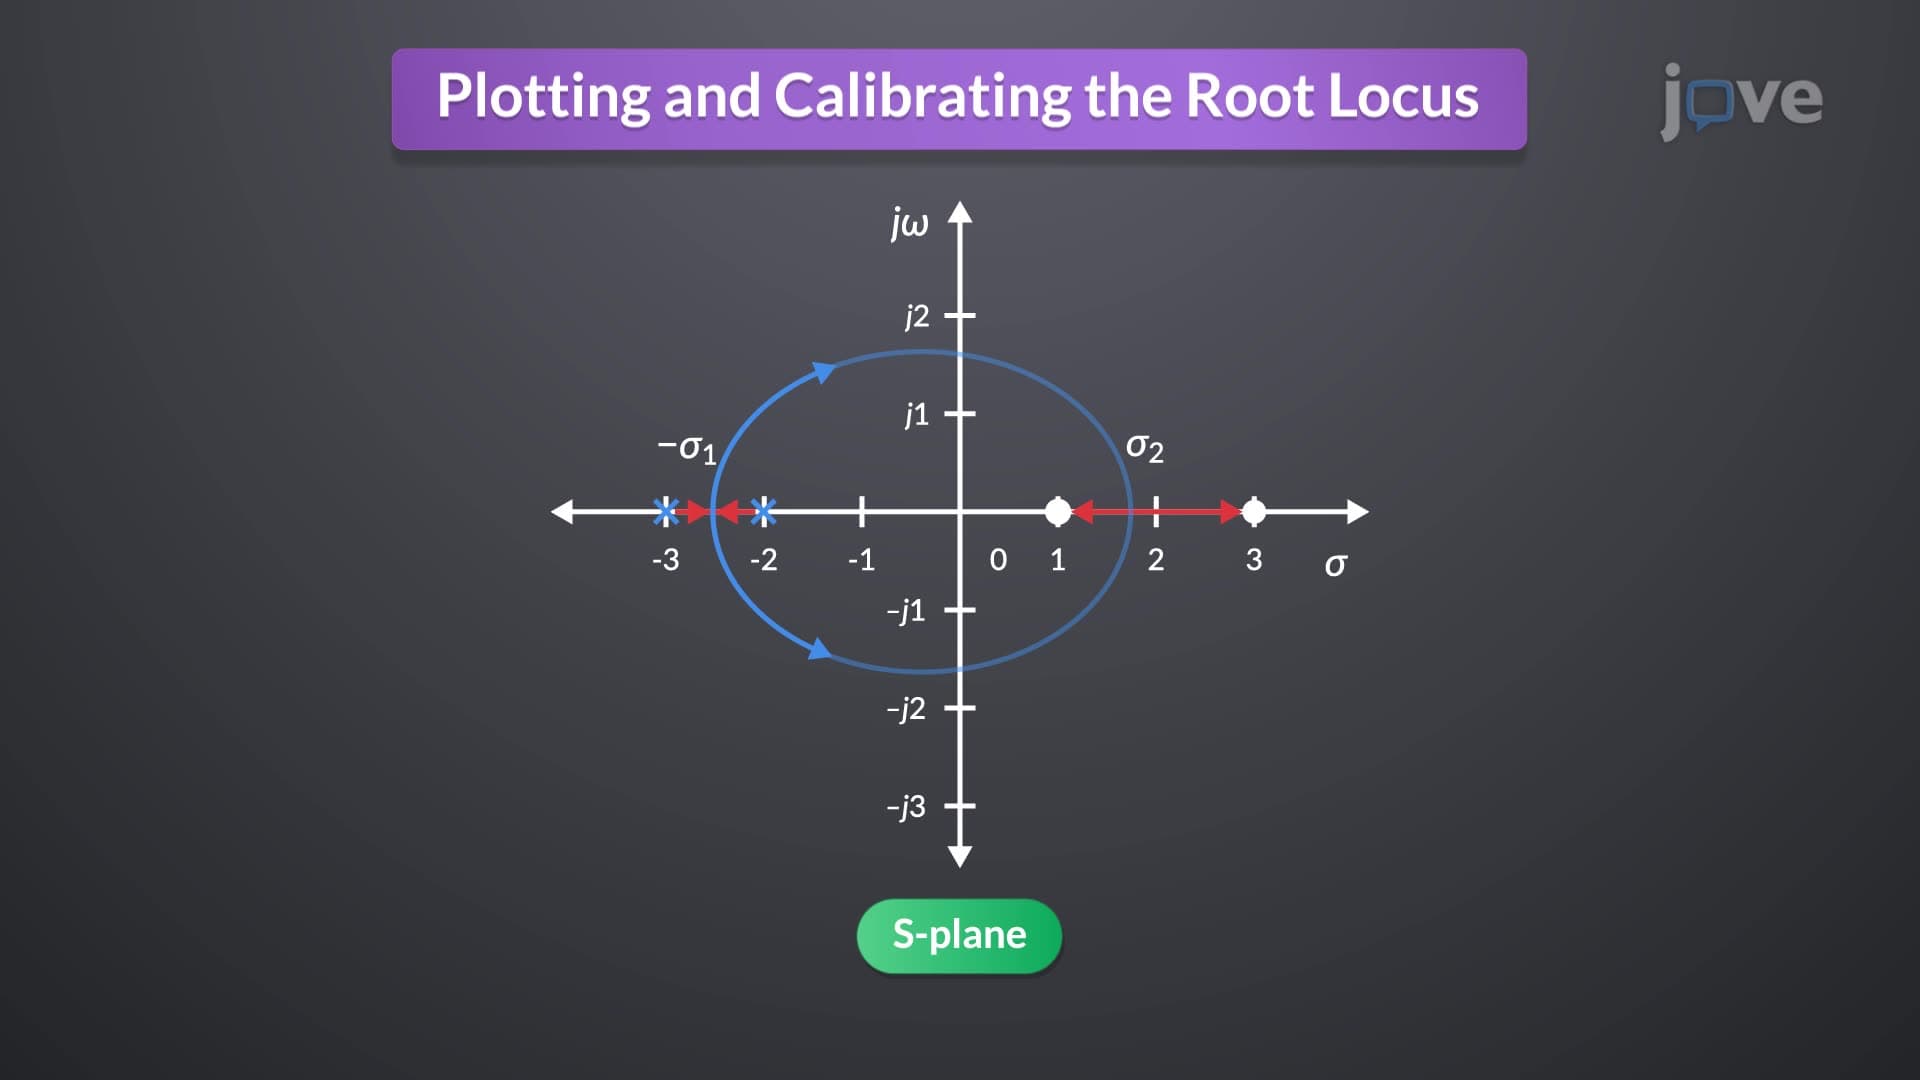
Plotting and Calibrating the Root Locus
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is observed...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system.
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires careful...
 01:19
Root-Locus Method
This system can be represented by a block diagram,...