Related Experiment Video
Updated: Sep 16, 2026

Experimental Investigation of Secondary Flow Structures Downstream of a Model Type IV Stent Failure in a 180° Curved Artery Test Section
Published on: July 19, 2016
Physics-Informed Tensor Velocity Reconstruction From 2-D Velocity Estimates Using Row-Column Probes

Abstract:
A method is presented for estimating 3-D velocity fields over space-time (tensor velocity fields) by combining 2-D velocity estimates acquired in multiple imaging planes with the continuity equation. The proposed tensor velocity estimator accurately reconstructs flow within the aliasing limit and mitigates motion-related artifacts observed in synthetic aperture (SA) and plane wave imaging (PWI) techniques, which typically reduce estimation accuracy at higher velocities. The estimator is demonstrated using both a short imaging sequence, which estimates the tensor velocity field in a thin volume (effectively a 2-D slice), and a longer sequence for reconstructing flow over a larger volume. A singular value decomposition (SVD) procedure for phase shift noise reduction is also proposed. In addition to improving the estimation precision, the method significantly reduces the required storage space and input size for the reconstruction algorithm: from approximately 20 GB-110 MB in one measurement. Furthermore, the procedure enables quick analysis of the SVD components' contributions to the flow. Flow-rig measurements of parabolic flow were acquired at various combinations of beam-to-flow angles (60°, 75°, and 90°) and flow-rotation angles (50° and 90°), with peak velocities ranging from approximately 10%-95% of the velocity aliasing limit. The average bias for the velocity magnitude was found to be -0.71% $ \pm ~2.96$ %, and the standard deviation (SD) was 0.57% $ \pm ~ 0.19\%$ . From Field II simulations of pulsatile carotid artery flows, the estimator reconstructs the velocity magnitude over a 3.5 s period with a normalized root-mean-square error (nRMSE) of 3.57%. In measurements of flow in a carotid artery phantom, the average velocity magnitude pulse profiles of the mean and peak velocities were estimated with SDs of 0.75% and 2.63%. Similarly, in vivo measurements of the carotid artery bifurcation yielded mean and peak velocity magnitude profiles with estimated SDs of 1.06% and 2.51%. These results demonstrate that the proposed estimator can accurately and precisely reconstruct tensor velocity fields in clinically relevant and high-velocity flow scenarios.
Related Concept Videos
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:12
Average and Instantaneous Velocity Vectors
 01:11
Relative Velocity in Two Dimensions
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
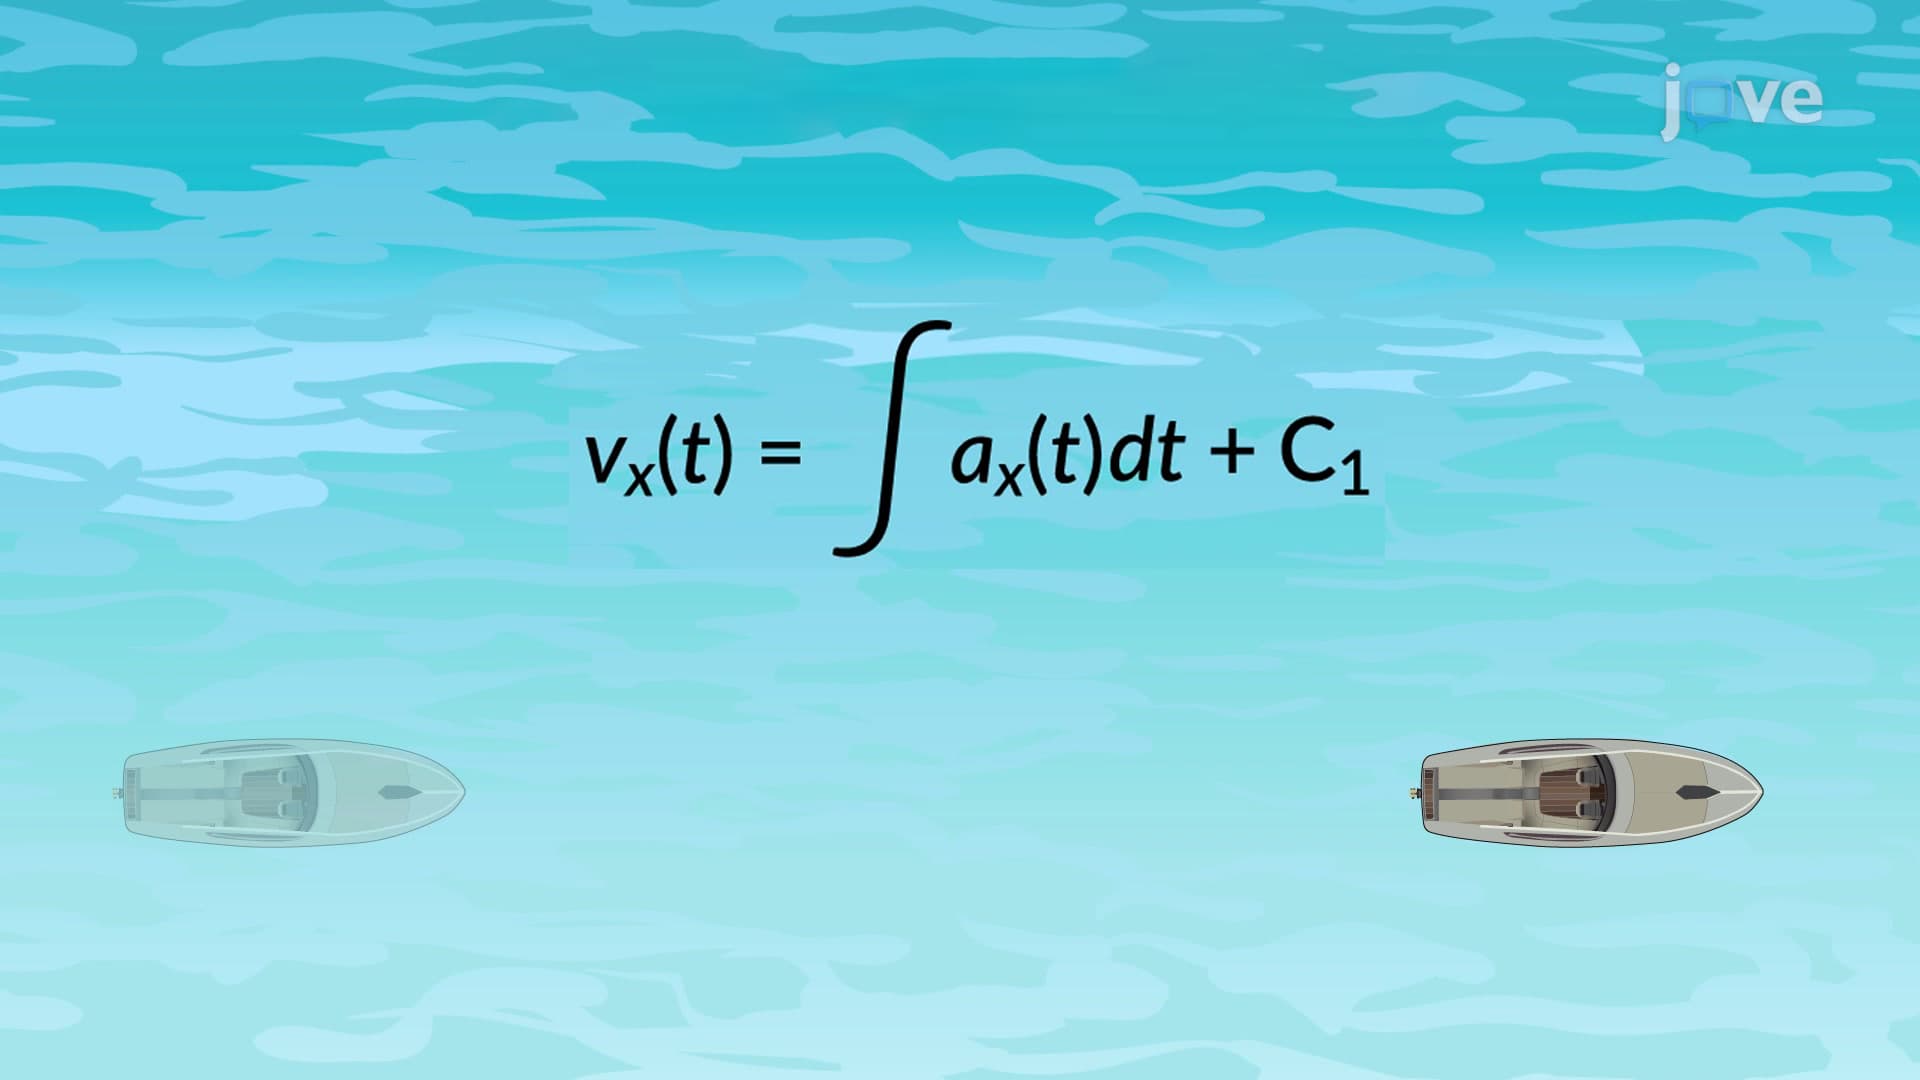 01:13
Velocity and Position by Integral Method
Consider an example to calculate the velocity and position from the acceleration function. A motorboat is traveling at a constant velocity of 5.0 m/s when it starts to decelerate to arrive at the dock. Its acceleration is...
 01:30
Vector Functions and Motion: Problem Solving