Related Experiment Video
Updated: Sep 16, 2026


WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
A novel autonomous bicycle based on control moment gyro technology
Jun Zhong1, Xia Lu1, Honghui Lan1
1College of Mechanical and Electrical Engineering, Hohai University, Changzhou, Jiangsu Province, 213200, China.

Abstract:
Momentum wheel balancing schemes for autonomous bicycles are limited in torque output, load capacity, and continuous-disturbance rejection. This paper presents a dual-rotor single-gimbal control moment gyroscope (SGCMG) stabilizer with dual-mode operation and doubled effective gyroscopic torque. The system is modeled via the Lagrangian method and linearized to a fourth-order state-space form. A fuzzy adaptive PID dual-loop cascade controller achieves the lowest tilt-angle overshoot (-0.05 rad vs. -0.09 rad for cascade PID) and zero steady-state error. Experiments on a 6.77 kg prototype demonstrate swing-up recovery from 8∘ within 7 s, stable balance under a 2 kg payload (maximum tilt deviation 0.17∘), convergence to ±0.2∘ after lateral disturbances, and curved motion at a 15∘ steering angle with tilt within ±0.6∘.

Related Concept Videos
 01:02
Gyroscope
 01:24
Gyroscope: Precession
 01:28
Moment of a Force About an Axis: Scalar
To better understand the concept of moment of force, consider the example of a cyclist riding a bicycle. When the cyclist applies force on...
 01:15
Torque Free Motion
 01:29
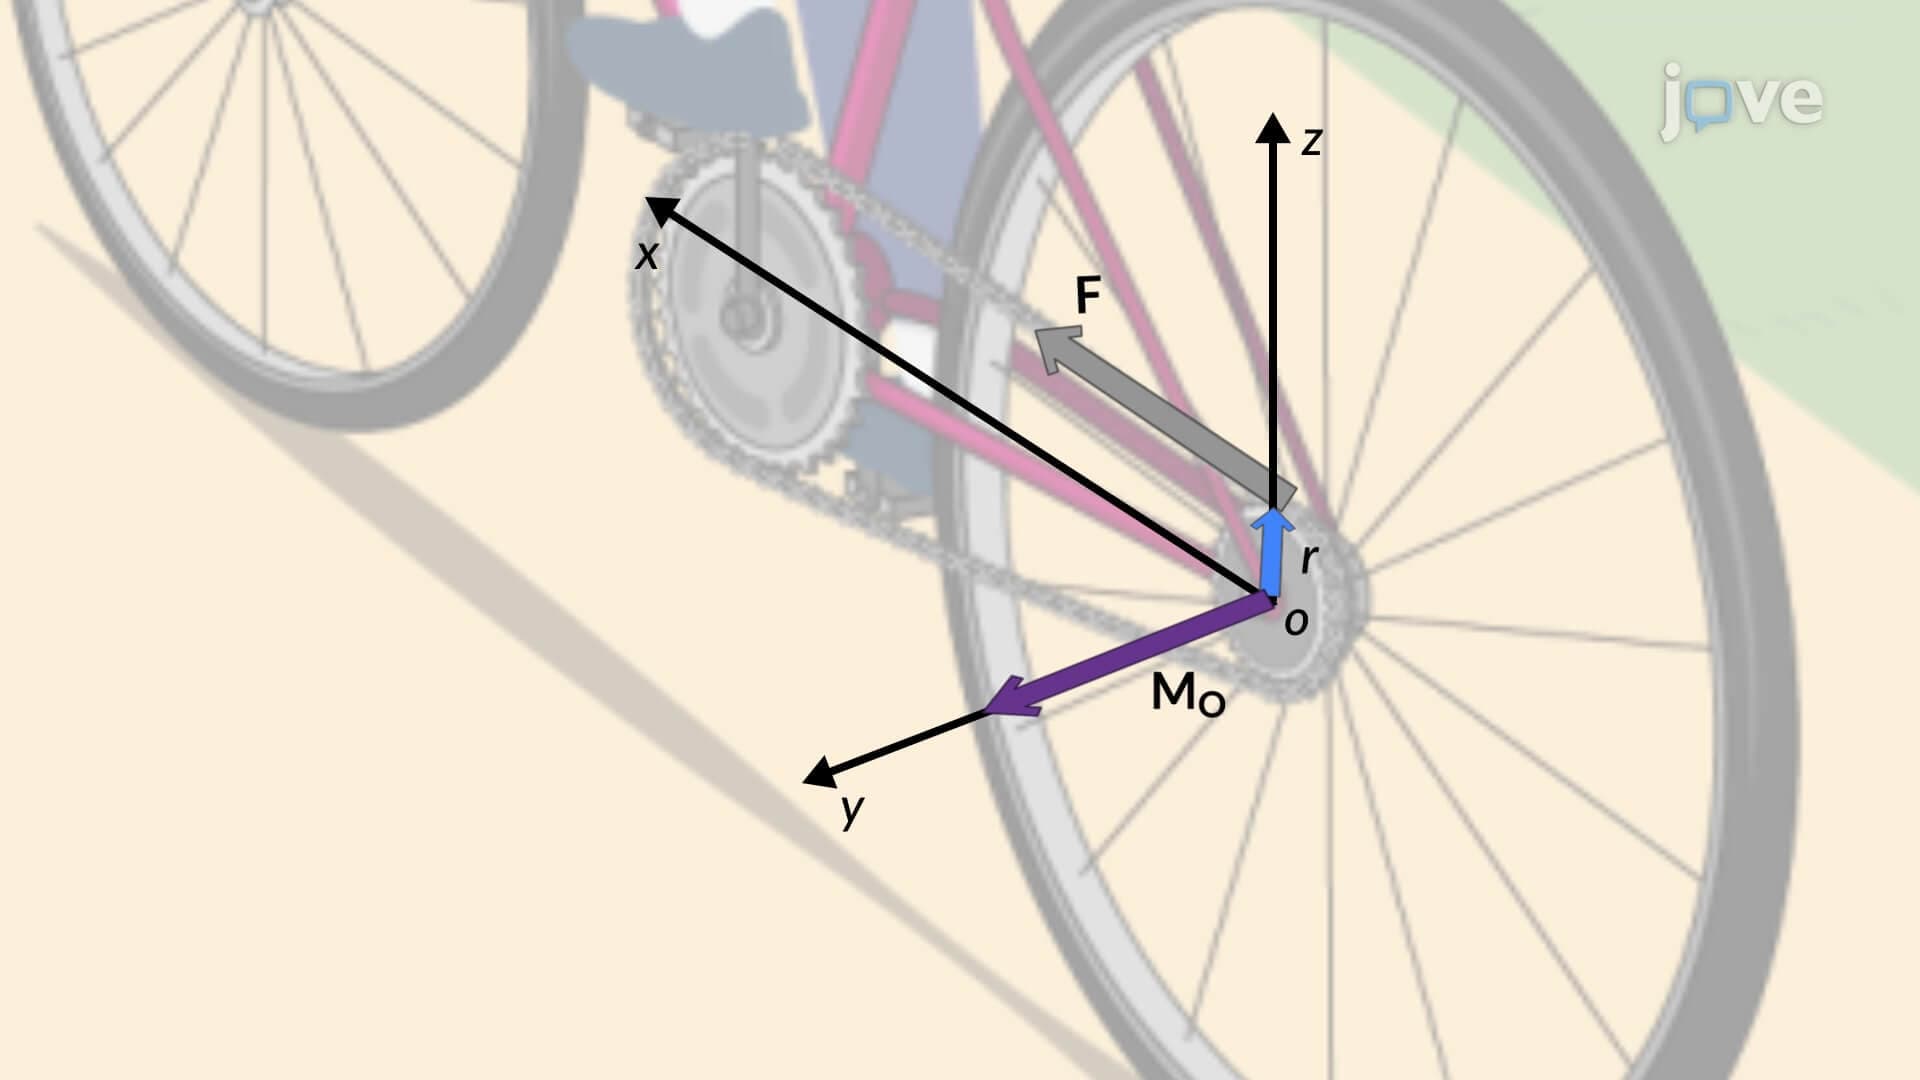
Moment of a Force About an Axis: Vector
First, establish a coordinate system to understand how the moment of a force works.
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...