Related Experiment Video
Updated: Sep 16, 2026

Monitoring the Mechanical Evolution of Tissue During Neural Tube Closure of Chick Embryo
Published on: November 10, 2023
BA-ARAP-NMA: A Local Geometry Control Nonlinear Normal-Mode Analysis Method
Zhenyu Zhang1,2, Dejian Liu1, Haiying Yu1
1State Key Laboratory of Microbial Diversity and Innovative Utilization, Institute of Microbiology, Chinese Academy of Sciences, Beijing 100101, China.

Abstract:
Low-frequency normal-mode analysis (NMA) is widely used to predict collective protein motions, but direct Cartesian scaling progressively distorts the alpha-carbon (Cα) backbone as the amplitude increases. We present backbone-angle-compatible as-rigid-as-possible normal-mode analysis (BA-ARAP-NMA), a nonlinear Cα structure-generation method that constrains first-order changes in adjacent and next-nearest Cα distances during anisotropic network model (ANM) calculations and applies a co-rotational as-rigid-as-possible (ARAP) correction during structure generation. Tests on 35 experimentally characterized two-state protein pairs showed that the geometric constraints retained most of the input-to-second-state displacement information. In 34 of 35 pairs, recalculating the constrained modes increased the concentration of the retained transition information in the leading low-frequency modes. Across matched displacements, BA-ARAP-NMA substantially reduced local Cα distance and angle distortions in every pair. At the protein-pair level, BA-ARAP-NMA generally yielded lower root mean square deviation (RMSD) to the paired state and higher transition coverage than linear Cα-ANM while maintaining improved virtual-angle accuracy. BA-ARAP-NMA therefore extends Cα normal-mode structure generation beyond direct linear scaling, retaining transition-related collective information while providing amplitude-ordered structures with frame-level geometric measurements for subsequent rebuilding and refinement.
Related Concept Videos
 01:27
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:10
Equations of Motion: Normal and Tangetial Components
Newton's second law of motion is employed to articulate the equation...
 01:24
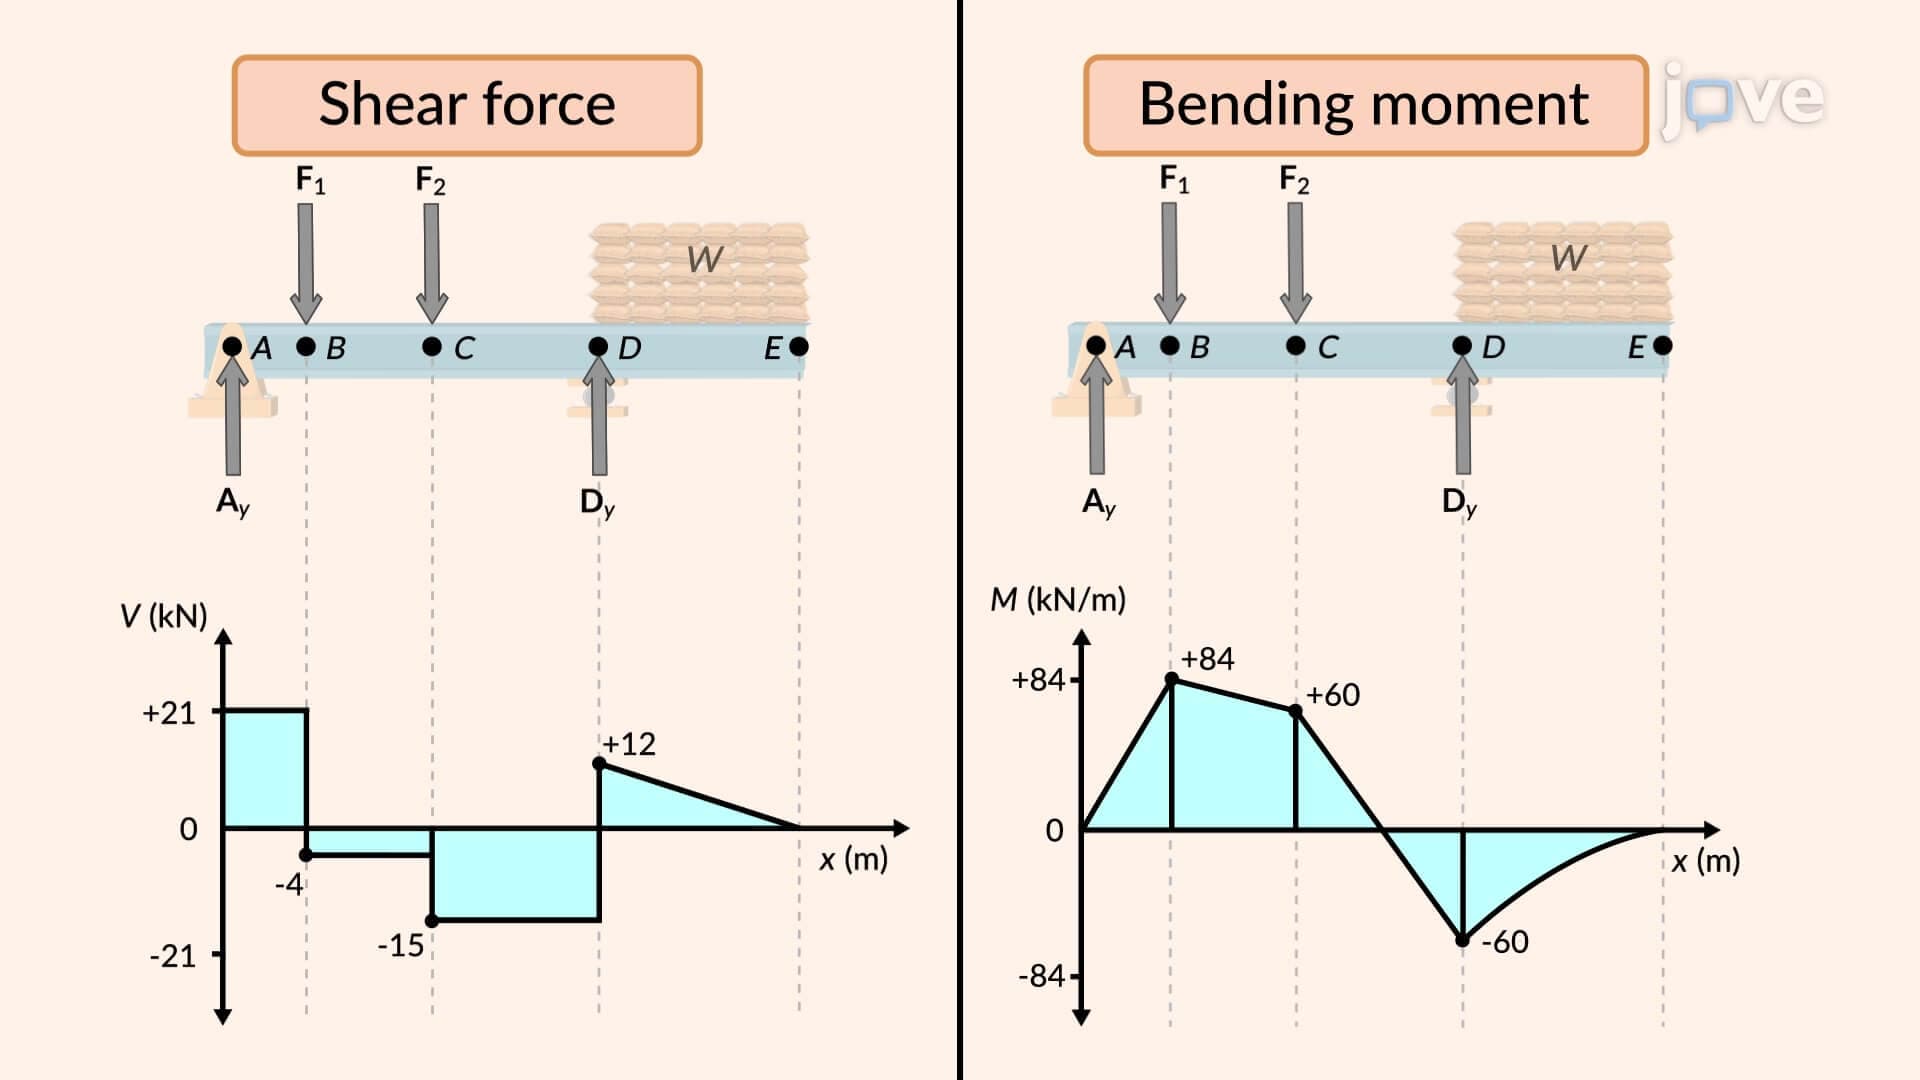
Shear and Bending Moment Diagram: Problem Solving
Draw a Free-Body Diagram: Start by drawing a free-body diagram of the entire beam, including the concentrated loads, distributed load, and reaction...
 01:15
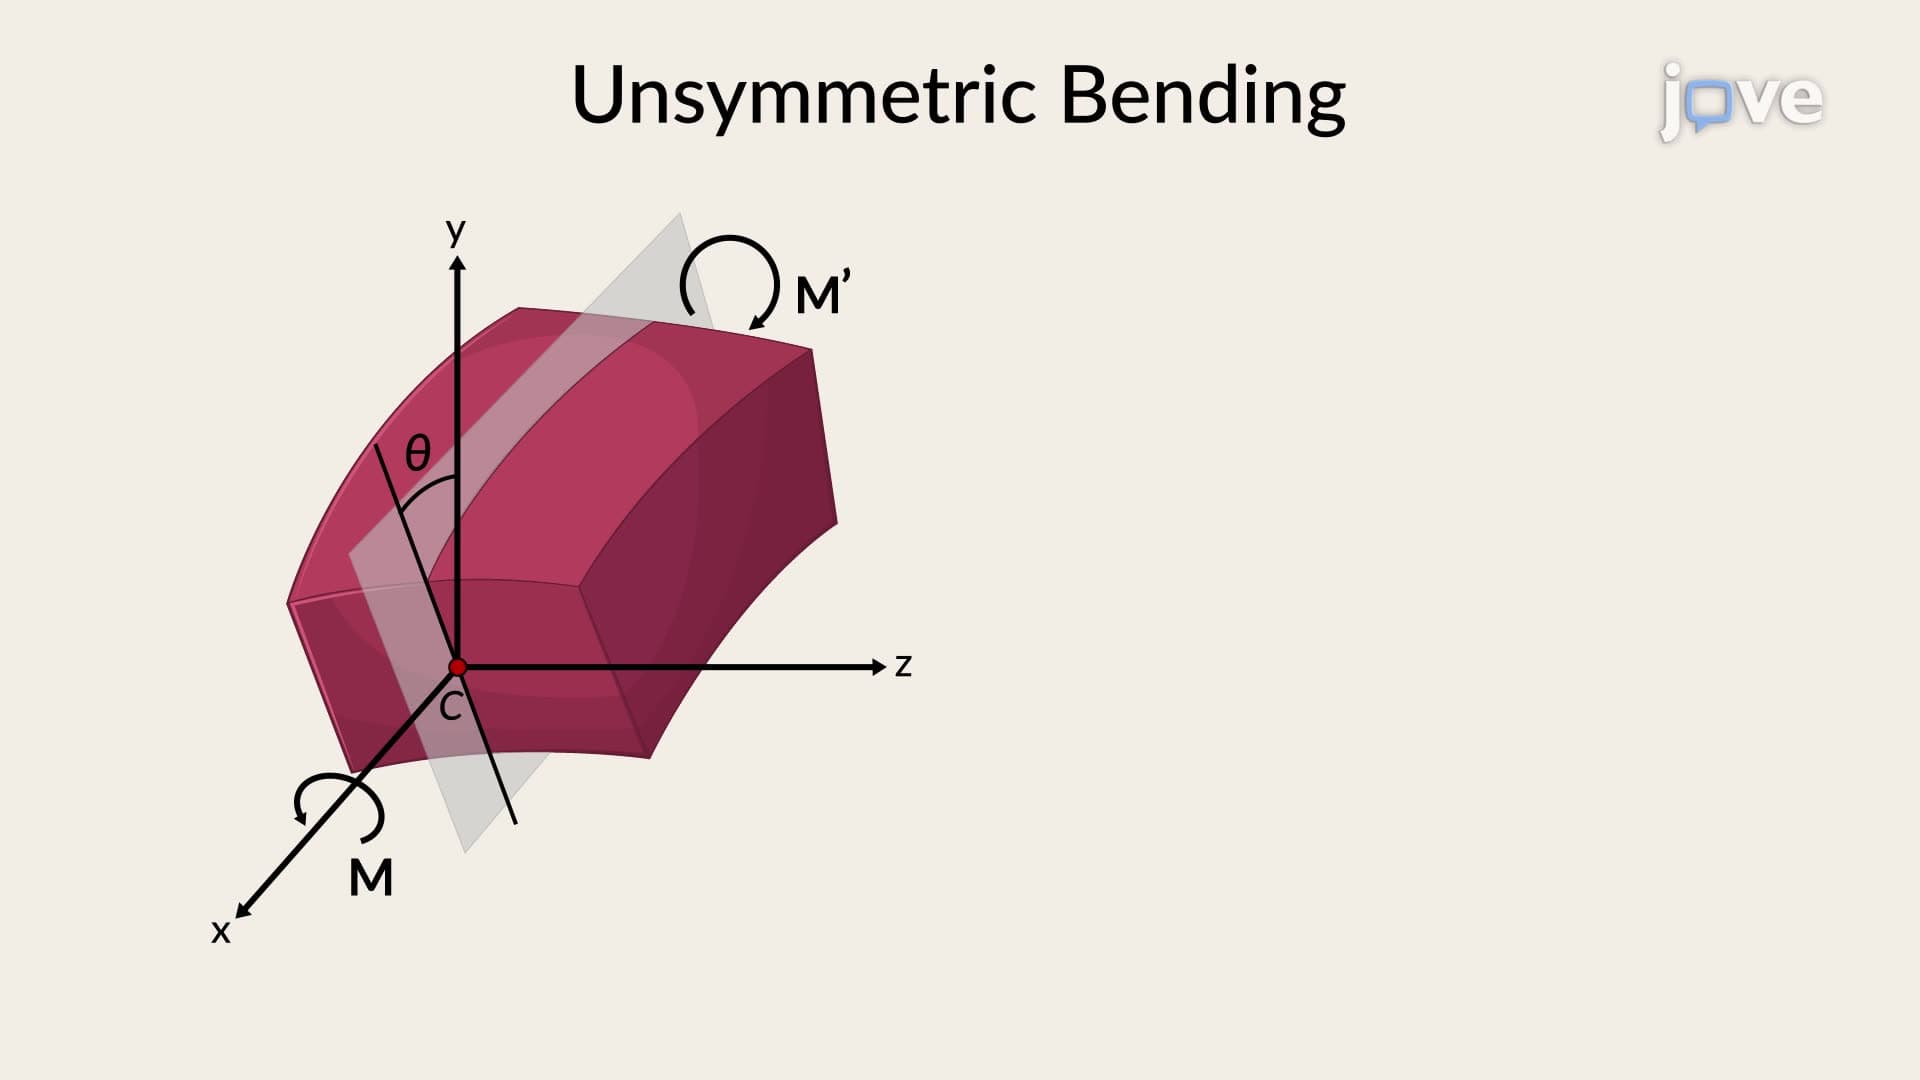
Unsymmetric Bending - Angle of Neutral Axis
When a bending moment is applied at an angle θ concerning the vertical axis of a symmetrical member, it can be resolved into components along the member's principal centroidal axes. The...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...