Related Experiment Video
Updated: Sep 16, 2026

Evaluating the Effect of Roadside Parking on a Dual-Direction Urban Street
Published on: January 20, 2023
Camera-GPS Sensor Fusion for Kinematic Characterization, Microsimulation Validation, and Macroscopic Capacity
Deo Chimba1, Wittness Mariki1, Sunam Shrestha1
1Department of Civil and Architectural Engineering, Tennessee State University, Nashville, TN 37209, USA.

Abstract:
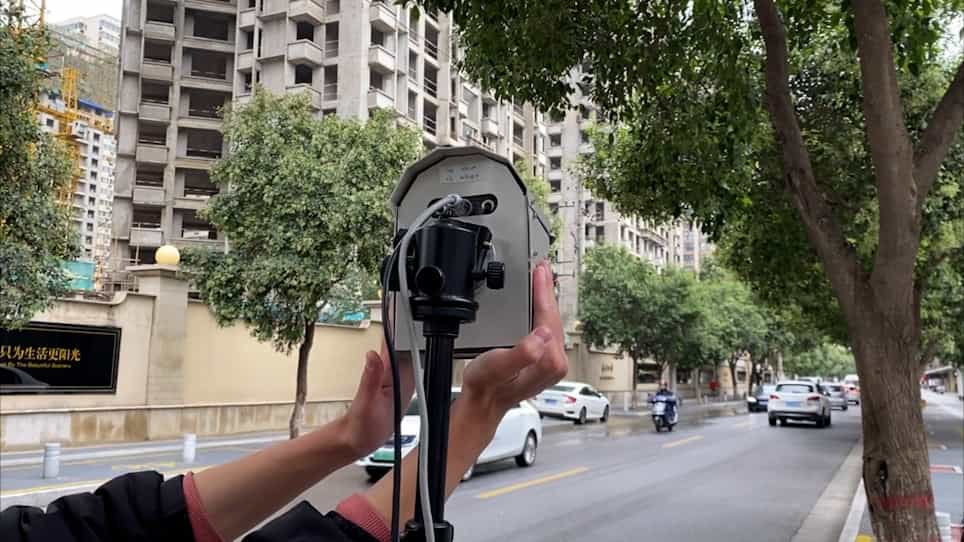
This study presents a sensor-fused field investigation and simulation-based analysis of four horizontal and vertical traffic-calming devices-two raised speed tables, a speed hump, and a raised crosswalk-installed along a 5250-ft two-lane residential collector in Nashville, TN, USA. A dual-sensor architecture combining a Miovision Scout video-based vehicle counter and WAAS/EGNOS-augmented GPS probe-vehicle logging (5 m 3-D RMS horizontal accuracy, 1 Hz sampling) was used to reconstruct 30 quality-controlled free-flow vehicle trajectories and 12-h per-lane volume counts. A spatial kinematic transform (a = v·dv/dx) was applied to extract device-specific approach-deceleration and post-device recovery-acceleration rates, and a three-parameter log-logistic cumulative-distribution function was fitted to the field-observed desired-speed percentiles (root-mean-square error below 0.043 for both speed-table devices). The camera- and GPS-derived observations were used to calibrate and statistically validate a PTV VISSIM microsimulation replica of the corridor, achieving a mean-speed calibration error of 0.71% or better at every device, a GEH statistic below 1.5 at all four analysis turning movements, and independent travel-time validation errors of 5.7-12.1%, within the accepted 15% threshold. The validated model was then used to reconstruct device- and spacing-specific May-Keller macroscopic speed-density-flow relationships, calibrated against simulated capacities of 650-775 vehicles per hour per lane at 350-, 700-, and 1050-ft device spacing. Results show capacity reductions of 20-33% relative to free-flow conditions and yield kinematically derived maximum recommended spacings of 265-630 ft to maintain crossing speeds at or below 15 mph, depending on device geometry. The findings demonstrate a reproducible, low-cost sensor-fusion workflow for quantifying the safety-capacity trade-off of traffic-calming corridors and for informing the design of sensor-in-the-loop adaptive-calming infrastructure.


Related Concept Videos
 01:17
Design Example: Alignment of a Road Line Using GIS
 01:28
Field Application of Global Positioning System
 01:25
Coplanar Forces
 01:30
Three-Dimensional Force System
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:30
Types of Global Positioning System Surveys