Related Experiment Video
Updated: Sep 16, 2026
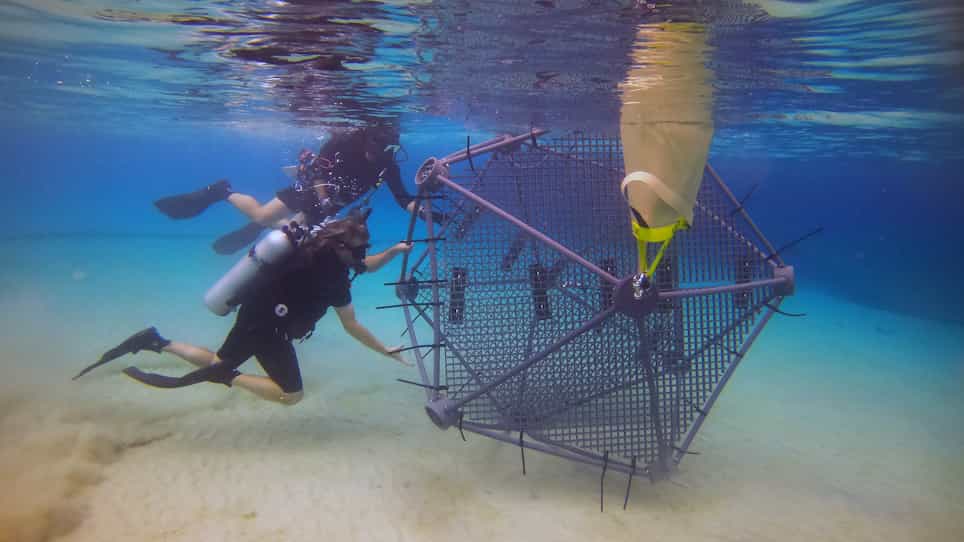

Coral Reef Arks: An In Situ Mesocosm and Toolkit for Assembling Reef Communities
Published on: January 6, 2023
VARE: Geometry-Anchored Bearing and Range Stabilization for USV Recovery
Chen Chen1,2, Ze Sun1,2, Jiale Zhang1,2
1Taihu Laboratory of Deepsea Technological Science, Wuxi 214082, China.

Abstract:
Reliable unmanned surface vehicle (USV) recovery requires near-field maritime remote sensing outputs that remain stable during the final approach. Planar fiducial geometry provides metric pose estimates, but its depth channel is sensitive to corner-localization noise, apparent marker shrinkage, glare, reflection, and vessel vibration. We present VARE (Visual-Adaptive Ranging and Estimation), a geometry-anchored perception pipeline that combines ArUco-based Perspective-n-Point pose recovery, dual-path bearing fusion, MiDaS-assisted range stabilization, depth-consistency confidence weighting, and innovation-adaptive temporal filtering. VARE is a system-level integration rather than a new neural architecture, PnP solver, or end-to-end docking controller. The pipeline explicitly separates image-centroid bearing, translation-vector bearing, marker-normal heading, camera-frame horizontal approach range, and lateral offset. Independent RTK-synchronized external references, with measured lever-arm corrections between the RTK antenna, camera optical center, and marker reference point, are used for pool and near-shore evaluation. In controlled land tests, VARE reduced independent-reference angular RMSE by 34.0-49.3% relative to the pixel-only baseline and by 22.0-36.4% relative to a static-filter PnP variant. Across 15 pool-based approach trials, the full vision-only configuration achieved a horizontal bearing RMSE of 0.46 degrees, a range MAE of 0.82 m, and a range RMSE of 0.90 m. Relative to the matched IPPE-square geometry baseline with One-Euro filtering, the corresponding descriptive reductions were 14.8%, 4.7%, and 5.3%; the modest range differences are not presented as universally significant. Trial-level summaries, confidence intervals, and data-availability provisions are added to support reproducibility. The results support VARE as a candidate perception module for RTK-referenced USV recovery guidance, while full six-degree-of-freedom validation, session-level dropout survival, and closed-loop capture success remain future work.
Related Concept Videos
 01:11
Buoyancy and Stability for Submerged and Floating Bodies
 01:19
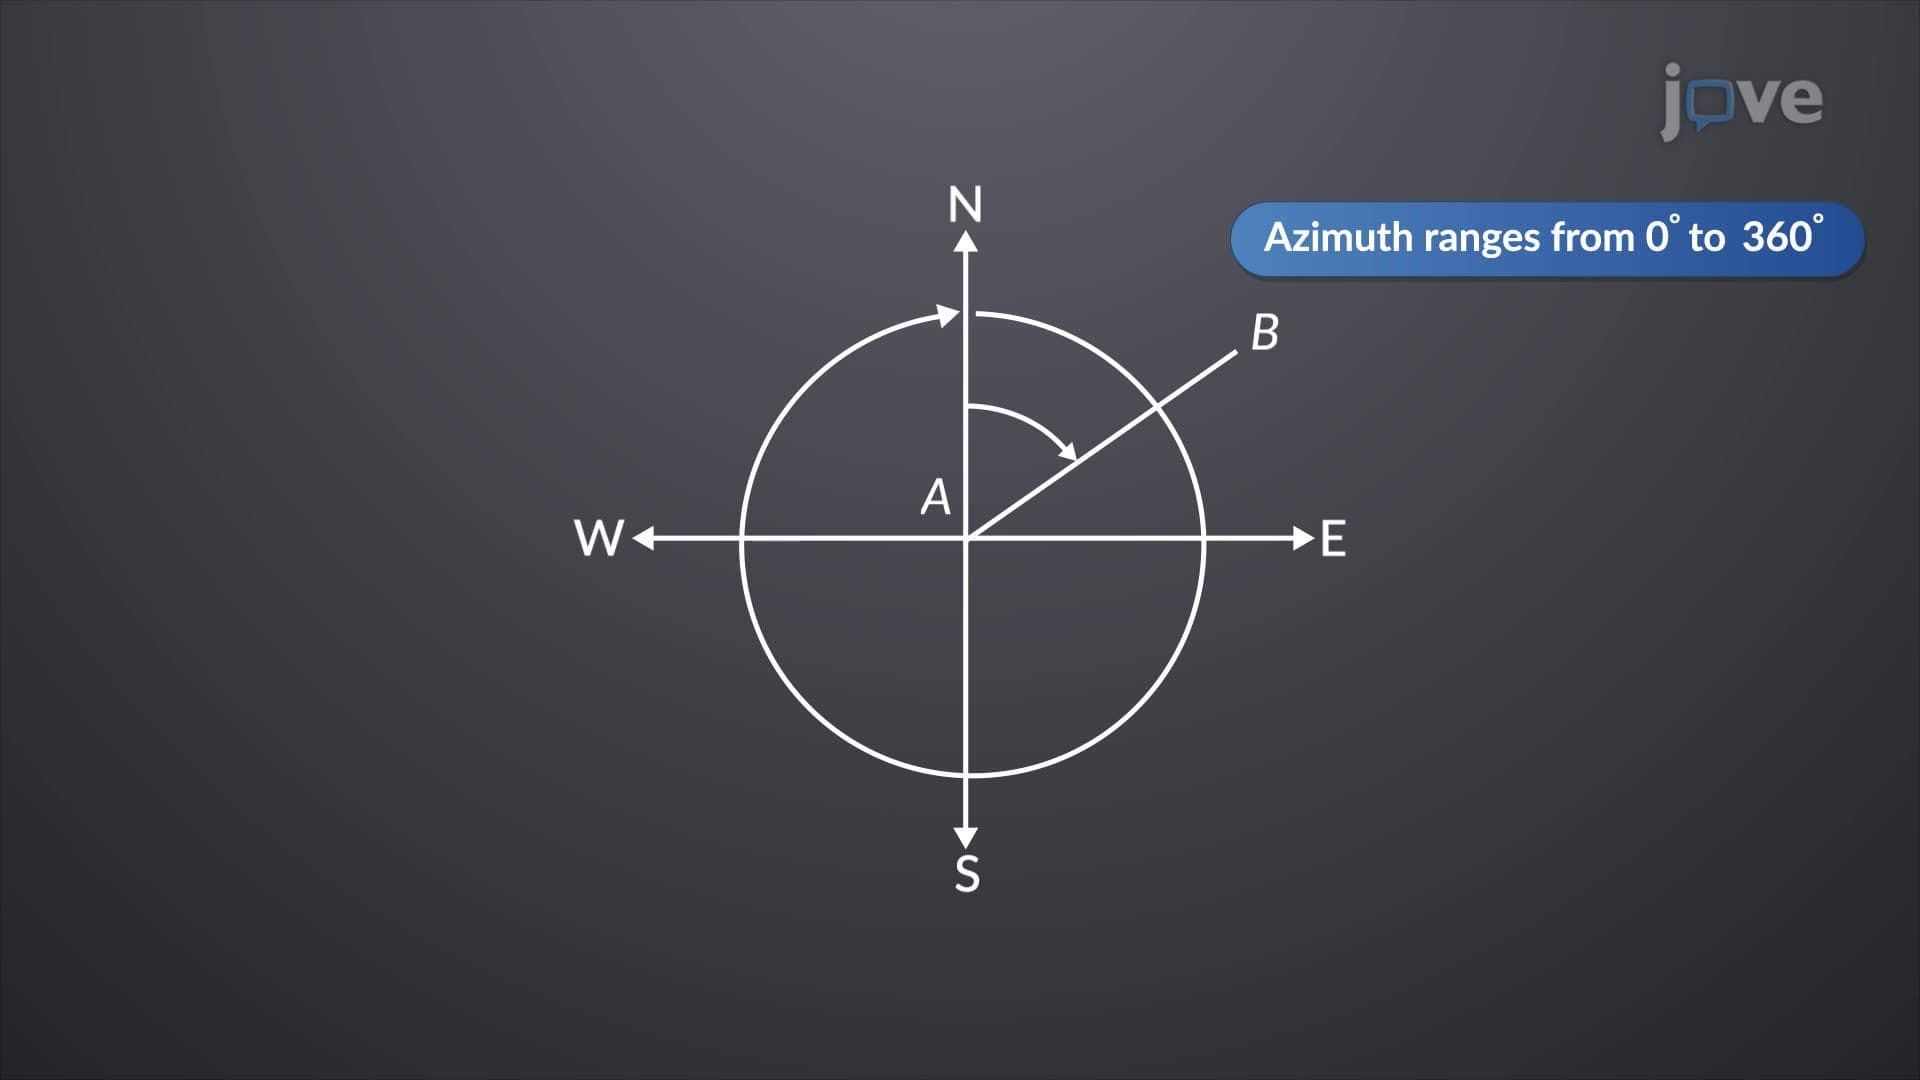
Azimuths and Bearings
 01:22
Bearing Stress
Due to the intricacy of these microforces, an average value, known as bearing stress, is often used by...
 01:30
Types of Global Positioning System Surveys
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's response.
 01:03
Anchoring Junctions