Related Experiment Video
Updated: Sep 16, 2026
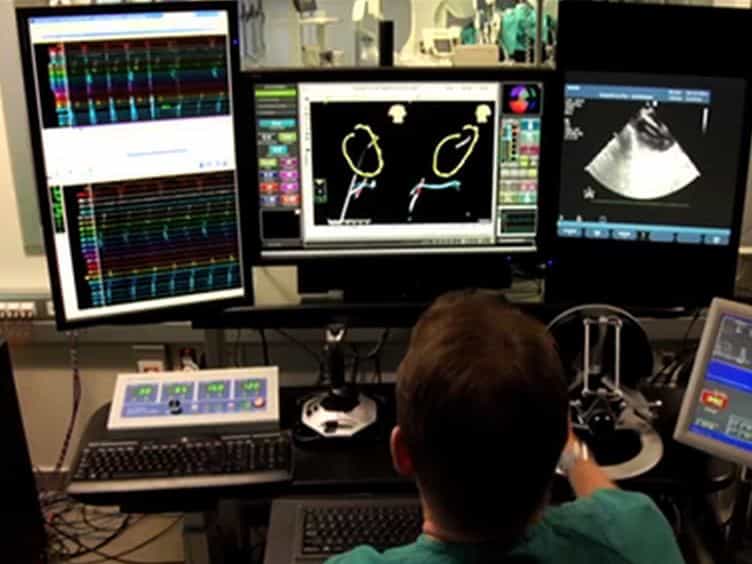

Remote Magnetic Navigation for Accurate, Real-time Catheter Positioning and Ablation in Cardiac Electrophysiology Procedures
Published on: April 21, 2013
SNR-Weighted Layer-Conditioned Magnetometer Array with Ellipsoid Calibration and Neural Network Initialization for
Omid Yaghoobian1, Khan A Wahid1
1Department of Electrical and Computer Engineering, University of Saskatchewan, 57 Campus Drive, Saskatoon, SK S7N 5A2, Canada.

Abstract:
Passive magnetic localization for wireless capsule endoscopy degrades under involuntary gastrointestinal motion: displacement toward one sensor layer simultaneously saturates near-side magnetometers while driving far-side sensors below the noise floor, a failure mode we term asymmetric layer visibility. Existing single-layer and multi-layer systems do not model this explicitly, and full-array Jacobian conditioning degrades progressively with displacement even where a layer-conditioned decomposition remains comparatively stable. We present a two-layer magnetometer array with three algorithmic contributions: per-sensor SNR gating excluding saturated or low-SNR sensors before optimization; layer-conditioned Levenberg-Marquardt estimation on a five-dimensional manifold via spherical parameterization; and SNR-weighted fusion with geodesic interpolation on S2, combined with layer-wise ellipsoid calibration and neural network initialization. Eight LIS3MDL tri-axial magnetometers in a 15×15×30 cm3 two-layer array were validated across 150 Monte Carlo trials using a 4-DOF robotic arm. Mean positional error was 2.32±0.35 mm and orientational error 2.15±0.88° at 12.4 Hz, with 93.85% convergence success under displacement-induced asymmetric visibility events of 1.00-4.00 cm-over 70% reduction over single-layer and layer-agnostic baselines. Hardware generalization was confirmed across three magnetometer types. The SNR weight ratio also yields a passive discriminant between capsule displacement and global array motion, cross-validated AUC 0.924±0.045, requiring no additional hardware. Reported accuracy is specific to the LIS3MDL magnetometer used in this study.