Related Experiment Video
Updated: Sep 16, 2026

Quantum State Engineering of Light with Continuous-wave Optical Parametric Oscillators
Published on: May 30, 2014
Parametric Amplification of Continuous-Variable Entangled State for Loss-Tolerant Quantum Distributed Sensing
1Department of Electrical and Electronic Engineering, The Hong Kong Polytechnic University, Hong Kong 999077, China.

Abstract:
Quantum metrology exploits quantum states to achieve an estimation sensitivity beyond classical limits. In the continuous-variable (CV) regime, the squeezed state has been used to implement deterministic quantum sensing, but the quantum metrology sensitivity of this state is significantly affected by losses or detection inefficiencies, which restrict its applications. In this work, quantum distributed sensing is proposed using optical parametric amplified multimode entanglement generated from squeezed states. It is found that the sensitivity is robust to loss or detection inefficiency when large-gain optical parametric amplification (OPA) is introduced, where a two-mode Einstein-Podolsky-Rosen-entangled state and a four-mode cluster state are exploited for analysis. The quantum sensitivity is greatly improved compared to that without OPA in almost all loss scenarios. The quantum Fisher matrix is calculated for both states to obtain the optimal bound in comparison with our scheme, and it is found that even with a small or moderate OPA gain, quantum sensing can be improved compared with the traditional scheme. The states are also compared with corresponding single-mode squeezed states, finding the parameter ranges where entangled states perform better. This study provides a method for realizing large-scale quantum metrology in real-world applications despite losses or detection inefficiencies.
Related Concept Videos
 00:59
Propagation of Uncertainty from Random Error
 01:10
Propagation of Uncertainty from Systematic Error
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:11
Sampling Continuous Time Signal
In the...
 01:14
The Entropy as a State Function
 01:10
Entropy Change in Reversible Processes
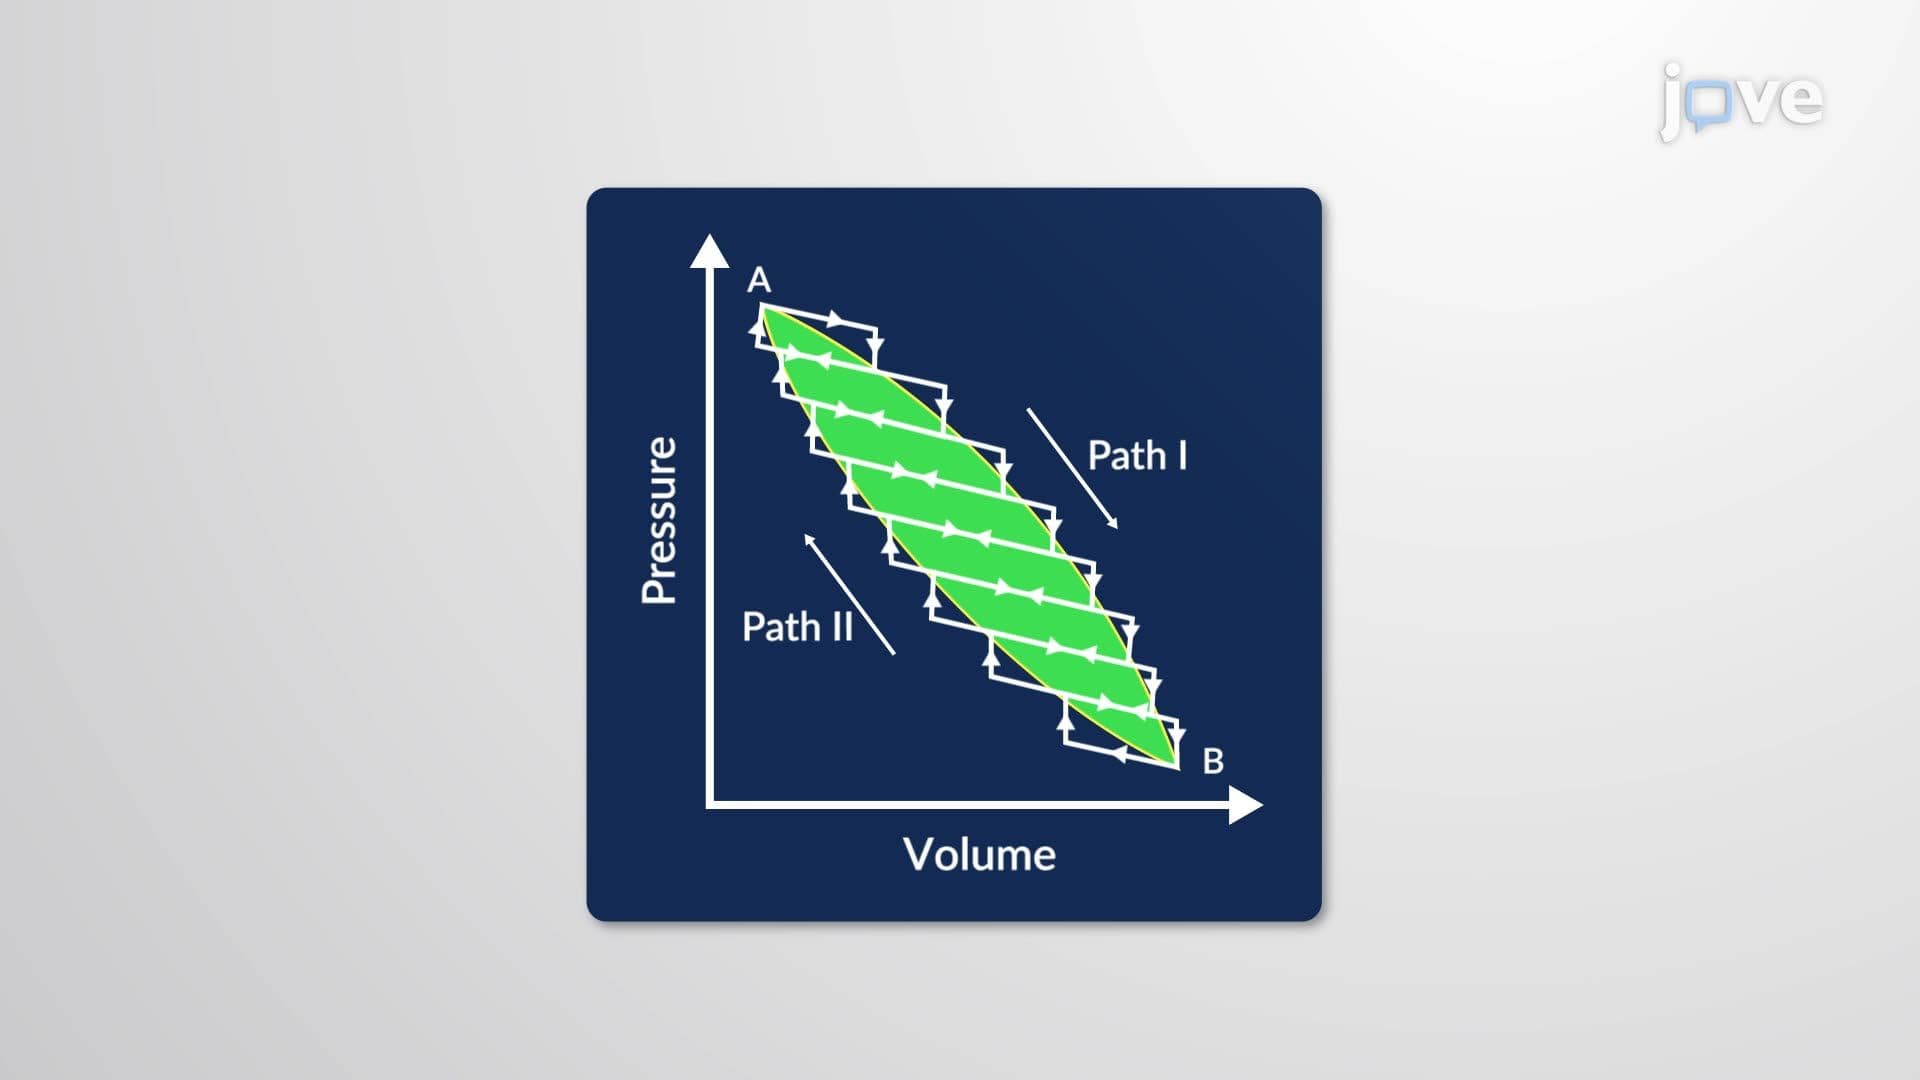
The statement can be further generalized to prove that entropy is a state function. Take a cyclic process between any two points on a p-V diagram.