Related Experiment Video
Updated: Sep 17, 2026
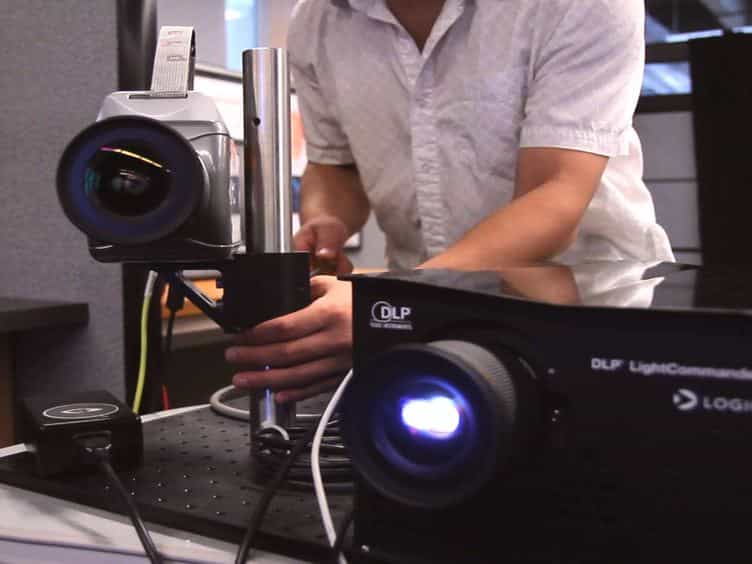

High-resolution, High-speed, Three-dimensional Video Imaging with Digital Fringe Projection Techniques
Published on: December 3, 2013
GSF-3DLane: Ground Surface Fitting for 3D Lane Detection Based on Monocular Depth Estimation

Abstract:
The task of 3D lane detection based on monocular cameras has been a hotspot in the research of autonomous driving systems. Previous studies that utilized monocular depth estimation to provide 3D spatial information have often introduced significant redundancy, resulting in biases in 3D lane detection. To address this issue, we propose a novel 3D lane detection framework, GSF-3DLane. This framework utilizes pseudo point cloud generated by monocular depth estimation and a new ground surface fitting method to provide more reliable 3D spatial information for the lane detection task. Specifically, we utilize a dynamic dual deformable attention mechanism based on query and key-value pairs to detect 3D lanes. Our approach generates 3D spatial information by dynamically estimating the ground surface and encoding positional data. On one hand, we propose a ground surface fitting method that employs learnable quadratic surface thresholds to yield precise results. By filtering out the cluttered point cloud situated above the ground plane and concentrating on the 3D Ground Surface, we can substantially mitigate the spatial errors stemming from monocular depth estimation. On the other hand, we introduce a dynamic ground point position encoding that leverages the ground surface to bolster the accuracy and stability of detection. This encoding offers spatial localization for lane queries. Furthermore, the GSF-3DLane framework does not depend on high-precision depth estimation models, thereby enhancing its practicality in a range of complex scenarios. Experimental results demonstrate that GSF-3DLane outperforms state-of-the-art methods on the real-world OpenLane dataset. The code is available at https://github.com/riversky2025/GSF-3DLane.