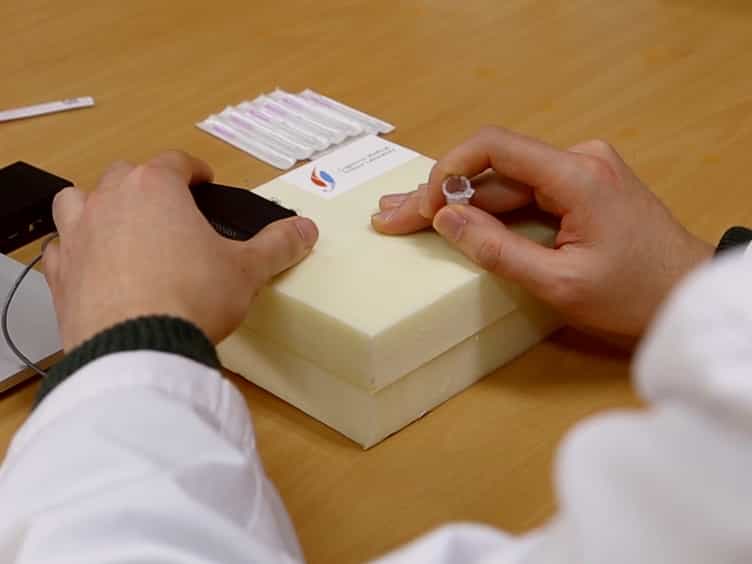
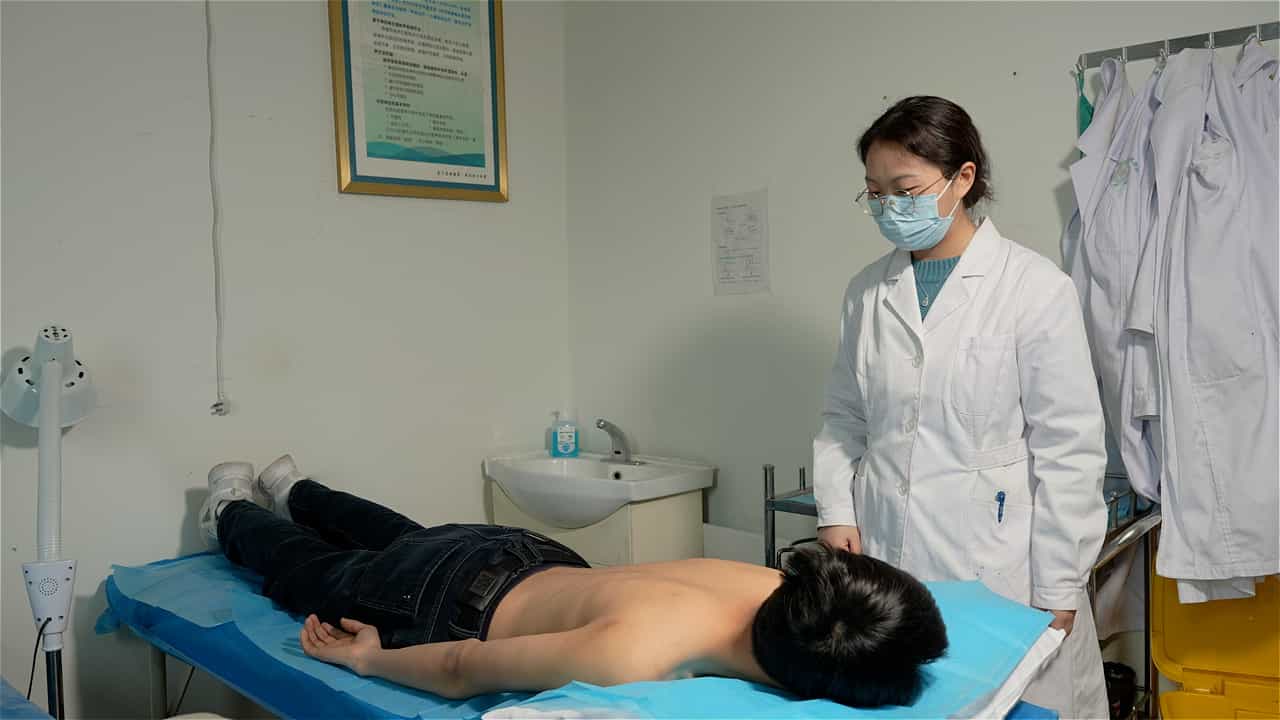
Related Experiment Video
Updated: Sep 17, 2026

A Mechanical Construction to Enhance the Stability and Safety of Lifting and Thrusting Manipulation of Acupuncture
Published on: January 10, 2025
[Research on manipulation acquisition and operational standardization assessment of dynamic moxibustion based on
Xuanlei Miao1, Yanjun Chen2, Suizhuo Wang3
1Jiangxi University of CM, Nanchang 330006, China; Affiliated Hospital of Jiangxi University of CM, Nanchang 330025.

Objective:
To develop an approach to in vivo acquisition and quantitative analysis of moxa-stick trajectories in dynamic moxibustion manipulation using computer vision technology, and validate its standardization in clinical practice.
Methods:
Using color-matching target detection and a sequence-matching-oriented machine learning algorithm, the three-dimensional trajectory coordinate sequence data were converted into actual displacement and velocity in real space,and were used to evaluate the standardization of manipulation trajectory. Thirty operators were divided into 3 groups based on their years of moxibustion experience, i.e., a high seniority group, a low seniority group, and an internship group, with 10 operators in each one. In each group, the operators collected data from both the 10-minute meridian-based round-trip moxibustion trajectory and the sparrow-pecking moxibustion trajectory. The moxibustion trajectory operated by the heat-sensitive moxibustion robot served as the standard reference. The differences in the dispersion of data across 4 dimensions (length, height, width, and rate) of moxibustion were analyzed among groups, and the scores of manipulation trajectory standardization were compared.
Results:
The computer vision technology was capable of detecting the trajectory of dynamic moxibustion techniques and recording their three-dimensional trajectories along with velocity parameters. In comparison with the heat-sensitive moxibustion robot, the high seniority group, the low seniority group and the internship group all demonstrated the increases in all trajectory parameters and velocity dispersion and the decreases in the standardization scores (P<0.01). Among the manual manipulation groups, as clinical proficiency decreased, the trajectory parameters and velocity dispersion of meridian-along round-trip moxibustion and sparrow-pecking moxibustion were elevated(P<0.01) and the standardization scores were reduced (P<0.01).
Conclusion:
The color-matching target detection and sequence-matching-oriented machine learning algorithm can objectively capture and record the trajectory of dynamic moxibustion, and it is suitable for the objective evaluation of the standardization of dynamic moxibustion techniques.