Related Experiment Video
Updated: Sep 18, 2026
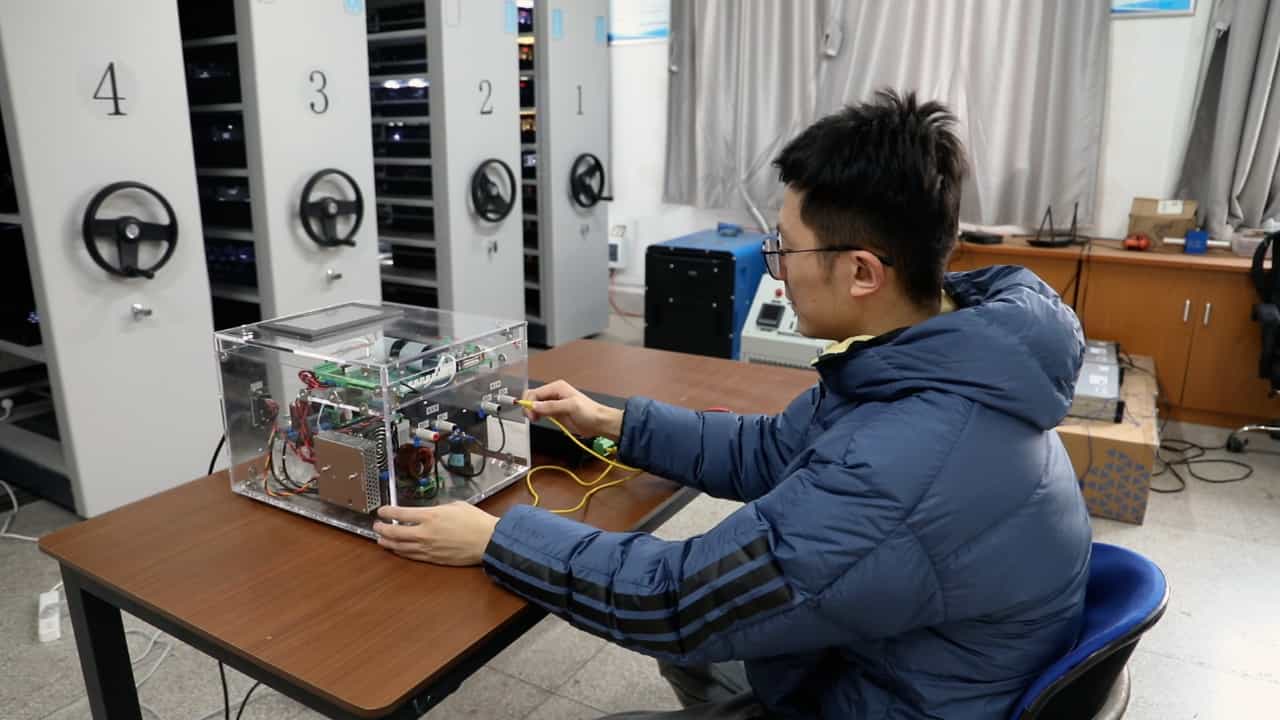

Experimental Investigation of the Hierarchical Control in DC Microgrids Using a Real-time Simulator
Published on: February 14, 2025
Improved linear active disturbance rejection control for mitigating subsynchronous control interaction in DFIG
Shengyu Chen1, Guidong Zhang1, Samson S Yu2
1School of Automation, Guangdong University of Technology, Guangzhou, 510006, China.

Abstract:
Series-compensated transmission networks can induce subsynchronous control interaction (SSCI) in doubly fed induction generator (DFIG) wind farms due to interactions between converter control dynamics and series capacitors. These interactions can amplify subsynchronous oscillations and threaten system stability. To mitigate this issue, this paper proposes an improved linear active disturbance rejection control (I-LADRC) strategy for the rotor-side converter inner current loop. The proposed I-LADRC reconstructs the error-feedback law of conventional LADRC (C-LADRC) by incorporating integral action while retaining active disturbance estimation and compensation, thereby providing partial structural separation between the tracking dynamics and observer-bandwidth tuning. Frequency-domain and small-signal stability analyses demonstrate that the proposed method provides improved SSCI damping and disturbance suppression compared with PI and C-LADRC. Based on these characteristics, a constrained Pareto-based parameter-design procedure is developed, in which full-system stability is enforced while SSCI-band disturbance attenuation is balanced against high-frequency measurement-noise transmission. Hardware-in-the-loop (HIL) experiments validate the theoretical findings and confirm the effectiveness and practical applicability of the proposed controller for SSCI mitigation in DFIG-based wind energy systems.
Related Concept Videos
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires careful...
 01:24
Frequency-Domain Interpretation of PD Control
The proportional control gain, combined with the system's...
 01:28
Load-frequency control
 01:21
Time and frequency -Domain Interpretation of Phase-lag Control
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any finite,...