Related Experiment Video
Updated: Sep 18, 2026


Manufacturing, Control, and Performance Evaluation of a Gecko-Inspired Soft Robot
Published on: June 10, 2020
Arthropod-Inspired Miniature Modular Vibration Direct-Drive Robot With Untethered Locomotion
Shijing Zhang1, Ziteng Liu1, Youwei Liu1
1State Key Laboratory of Robotics and Systems, Harbin Institute of Technology, Harbin, China.

Abstract:
Miniature vibration direct-drive robots hold immense potential for missions in confined spaces, such as pipeline inspection and environmental detection. However, conventional fixed-configuration designs are restricted to single functionality, failing to adapt to the multifaceted demands of diverse operational tasks. Here, we present an arthropod-inspired untethered miniature modular vibration direct-drive robot, which achieves on-demand reconfiguration through standardized 19 mm × 32.5 mm × 18 mm driving units. Core innovations include tool-less nested locking interfaces for rapid assembly; compliant silicone connectors designed to mitigate vibration-induced wear and provide vibration isolation; chevron-shaped feet optimizing vibration-to-locomotion conversion; and a highly integrated onboard control architecture enabling untethered operation. The robot reconfigures into quadruped, hexapod, octopod, and circular morphologies with stable performance. In the quadruped robot (58.4 g; 46 mm × 75 mm × 38.8 mm), it reaches a maximum linear speed of 580.74 mm/s and rotational speed of 16.64 rad/s. The octopod robot sustains 450 mm/s under a 60 g payload while traversing 2.8 mm obstacles, 30 mm gullies, and confined pipelines. This work breaks fixed-configuration limitations, providing a generalizable paradigm for synergizing modularity and vibration-driven efficiency at the centimeter scale, offering new insights for miniature robots, and a versatile platform for confined-space operations.

Related Concept Videos
 01:22
Mechanical Systems
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:15
Torque Free Motion
 01:11
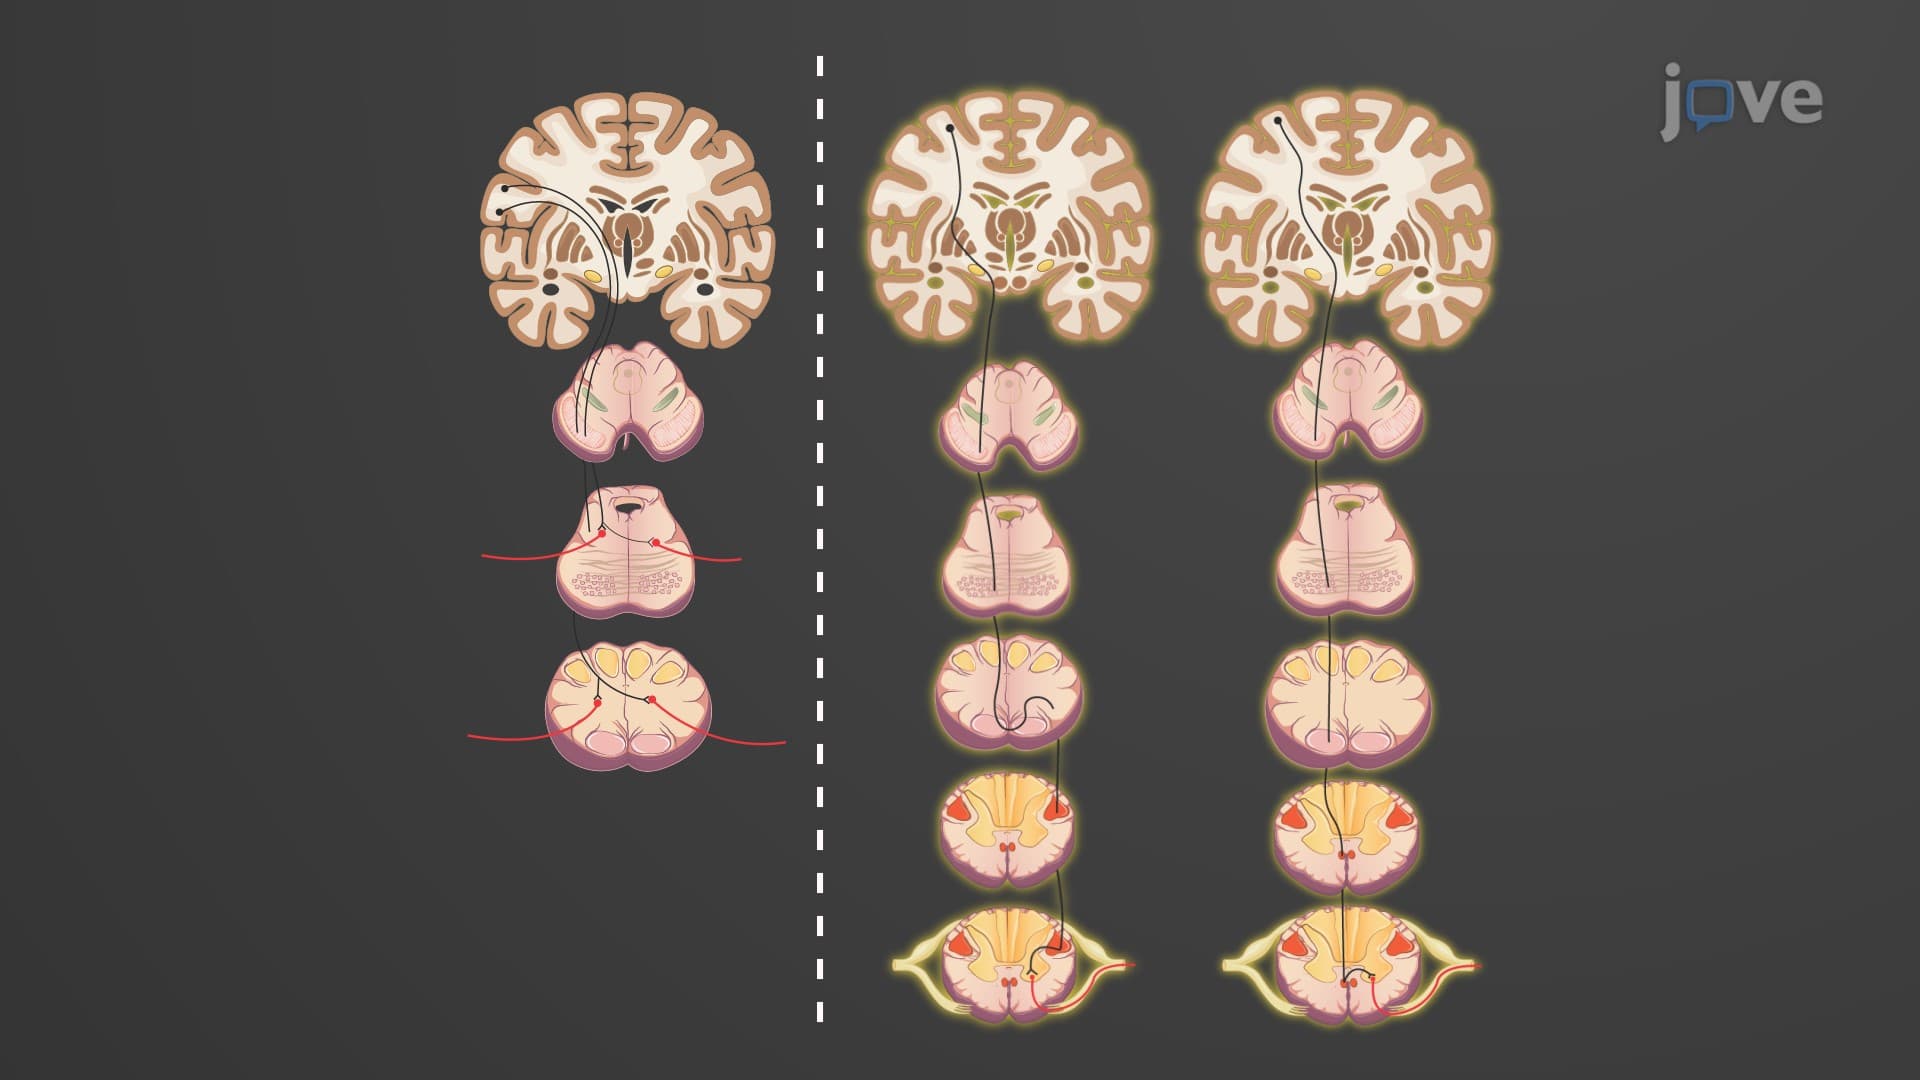
Direct Motor Pathways
The corticospinal tract is responsible for the voluntary movement of the limbs and trunk. It originates in the cerebral cortex of the brain and descends through the cerebrum's internal capsule and the...
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
 01:13
Motor Units
Motor units come in different sizes, with smaller units...