Related Experiment Video
Updated: Sep 19, 2026
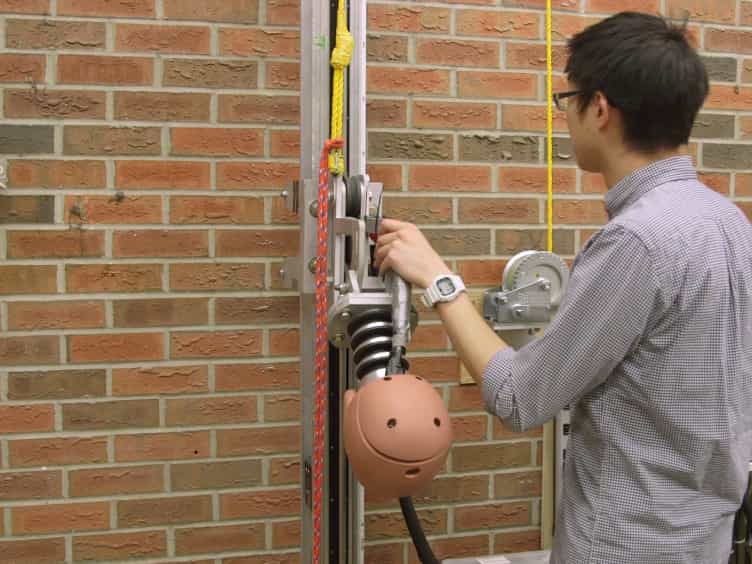

A Test Bed to Examine Helmet Fit and Retention and Biomechanical Measures of Head and Neck Injury in Simulated Impact
Published on: September 21, 2017
Comprehensive Mechanics-Based Metrics for Quantification of Head Impacts from Kinematics
Cole Smith1, Tanner M Filben2, Kristen F Nicholson1
1Department of Biomedical Engineering, Wake Forest University School of Medicine, Winston-Salem, NC, 27101; Virginia Tech - Wake Forest University School of Biomedical Engineering and Sciences, Winston-Salem, NC.

Abstract:
Mechanics-based metrics derived from principles of mechanical power and energy offer a comprehensive approach to characterizing head acceleration events (HAEs) recorded by impact sensing devices. However, systematic evaluation of diverse metric formulations remains limited. The objective of this study was to establish and compare a comprehensive set of 40 mechanics-based metrics for characterizing HAEs, applied to low-severity soccer headers as a demonstration dataset. A custom instrumented mouthpiece system collected head kinematic data from 18 subjects across 308 headers. Exploratory unsupervised analyses were intended to characterize the internal structure of the metric space rather than establish predictive validity or generalizability beyond this dataset. Principal components analysis revealed three latent metric families (proportional, rotational, translational/combined), with mechanics-based metrics demonstrating stronger loadings on principal components compared to peak resultant kinematics alone, suggesting they capture additional dimensions of biomechanical variability within this metric space. K-means clustering identified four distinct kinematic impact profiles, demonstrating that meaningful biomechanical structure exists even within a homogeneous sample of low-severity impacts. A minimal reporting set spanning traditional peak metrics, one energy or power metric, and one proportional metric is recommended to facilitate cross-study comparisons. The forty metrics presented should not be interpreted as immediate improvements in injury prediction; but rather they may provide comprehensive and complementary biomechanical characterization that is useful for future analyses of exposure assessment, feature selection, and metric validation studies.
Related Concept Videos
 01:30
Impact
When particles with different initial velocities collide, they induce deformation by applying equal and opposite impulses. At the point of maximum deformation, the particles move together with...
 01:30
Types of Impact
The coefficient of restitution is a metric for understanding the dynamics of impacts. It quantifies the ratio of relative velocity...
 01:13
Kinetic Energy for a Rigid Body
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:15
Kinematic Equations: Problem Solving