Related Experiment Video
Updated: Sep 19, 2026


Training Persons with Spinal Cord Injury to Ambulate Using a Powered Exoskeleton
Published on: June 16, 2016
Plantar-pressure-guided support-plate position control for a walker-assisted lower-limb rehabilitation exoskeleton
Yuhui Yang1, Wenyu Zhao2, Yuanxiang Guo1
1College of Mechanical and Marine Engineering, Beibu Gulf University, Qinzhou, China.

Introduction:
Maintaining appropriate foot-ground contact is important for walker-assisted lower-limb exoskeleton training. Excessive plantar loading may increase initial-contact impact and actuator load, whereas excessive unloading may reduce frictional contact and contact stability. Passive spring support can provide impact buffering, but it cannot adjust the support working point according to gait phase or plantar-pressure feedback.
Methods:
This study proposes a multi-zone plantar-pressure-guided position control method for the support-force adjustment plate of a walker-assisted lower-limb exoskeleton. The system combines a fixed-stiffness spring with a vertical screw-driven adjustment plate. Total plantar pressure was obtained by fusing signals from 18 pressure cells on each instrumented foot and served as the main feedback variable. Regional plantar pressures and the center of pressure supported gait-phase recognition and contact-state estimation. A phase-related plantar-pressure target band was used as an engineering constraint to maintain stable foot-ground contact. Experiments involved three healthy male participants under no-spring, passive-spring, and proposed-control conditions during low-speed frame-assisted walking.
Results And Discussion:
In the proposed-control condition, peak total plantar pressure was BW, 21.2% lower than in the no-spring condition and 6.7% lower than in the passive-spring condition. Relative to the no-spring condition, the loading rate decreased from to BW/s, and the initial-contact impact impulse decreased from to BW s. Hip-knee actuator electrical energy decreased from to J/gait cycle. After vertical-axis actuator energy was included, measured total actuator electrical energy was J/gait cycle and remained lower than in both comparison conditions. These preliminary results suggest that plantar-pressure feedback can regulate support-plate position, attenuate contact impact, and reduce measured robotic actuator effort during low-speed walker-assisted walking.
More Related Videos
 11:16
Engineering Platform and Experimental Protocol for Design and Evaluation of a Neurally-controlled Powered Transfemoral Prosthesis
Published on: July 22, 2014
 06:00
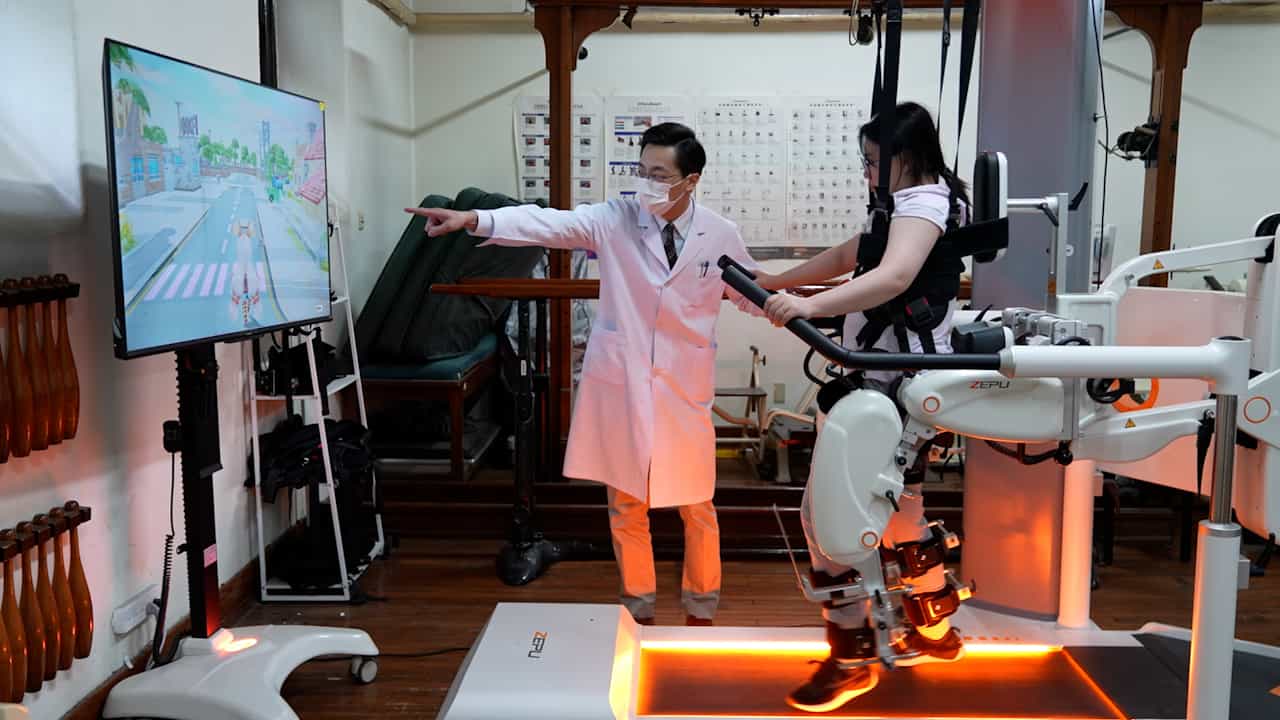
A Rehabilitation Program of Exoskeleton-assisted Body Weight-Supported Treadmill Training with Non-immersive Virtual Reality for Stroke Patients
Published on: May 16, 2025