Related Experiment Video
Updated: Sep 19, 2026
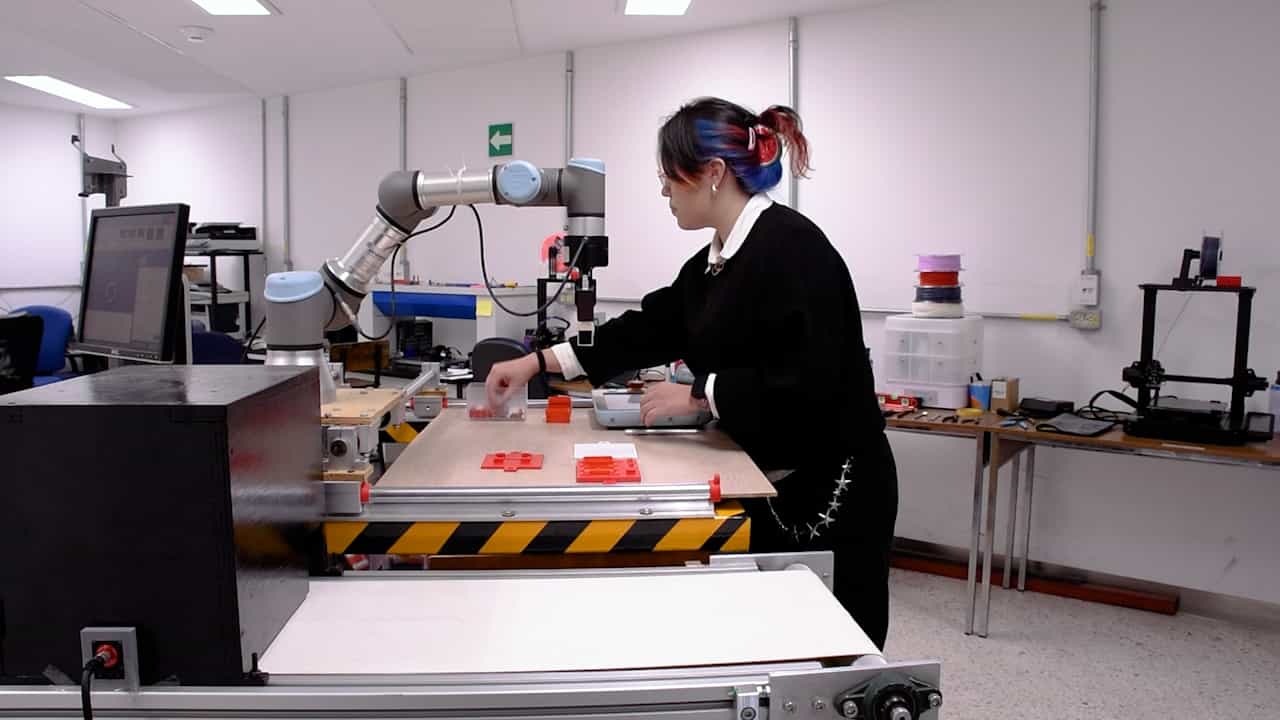
05:47

Simulation of a Scaled Assembly Process with Collaboration of a Robotic Arm and Monitoring through a Vision System for Quality Control
Published on: August 29, 2025
Correction: Predictive fatigue-aware human-robot collaboration: a real-time, open-source ROS 2 instantiation of a
Ranidu P Goonetilleke1, Azfar Khalid1
1Digital Innovation Research Group, Department of Engineering, School of Science and Technology, Nottingham Trent University, Nottingham, United Kingdom.
Frontiers in Robotics and AI
|September 18, 2026

Abstract:
[This corrects the article DOI: 10.3389/frobt.2026.1897261.].
Related Concept Videos
 01:24
One-Degree-of-Freedom System
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:06
Virtual Work for a System of Connected Rigid Bodies
Virtual work is a powerful method used to solve problems involving several connected rigid bodies. When the system is in equilibrium, virtual work is zero. This allows the calculation of the resulting forces when a system undergoes a virtual displacement. When attempting to analyze such a system, first, use a free-body diagram, where an independent coordinate represents the configuration of the links, and mark its deflected position resulting from the positive virtual displacement.
Next,...
Next,...
 01:17
Open and closed-loop control systems
Control systems are foundational elements in automation and engineering. They are broadly categorized into open-loop and closed-loop systems. These classifications hinge on the presence or absence of feedback mechanisms, significantly influencing the system's performance, complexity, and application.
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 02:16
Stereotype Content Model
The Stereotype Content Model (SCM) was first proposed by Susan Fiske and her colleagues (Fiske, Cuddy, Glick & Xu, 2002; see also Fiske, 2012 and Fiske, 2017). The SCM specifies that when someone encounters a new group, they will stereotype them based on two metrics: warmth—or that group’s perceived intent, and how likely they are to provide help or inflict harm—and competence—or their ability to carry out that objective. Depending on the warmth-competence categorization, a person will feel...
 01:15
Torque Free Motion
The torque-free motion refers to the movement of a rigid body in space when no external torques are acting upon it. This type of motion can be observed in environments where there are no external forces or frictions, like in outer space. For example, a rotation of Mars in space is a torque-free motion. Mars is an axisymmetric object, meaning it has an axis of symmetry along which it rotates, designated as the z-axis. The rotating frame of reference is defined such that the center of mass of...
 01:30
Three-Dimensional Force System:Problem Solving
A three-dimensional force system refers to a scenario in which three forces act simultaneously in three different directions. This type of problem is commonly encountered in physics and engineering, where it is necessary to calculate the resultant force on the system, which can then be used to predict or analyze the behavior of the object or structure under consideration.
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...