Related Experiment Video
Updated: Sep 20, 2026
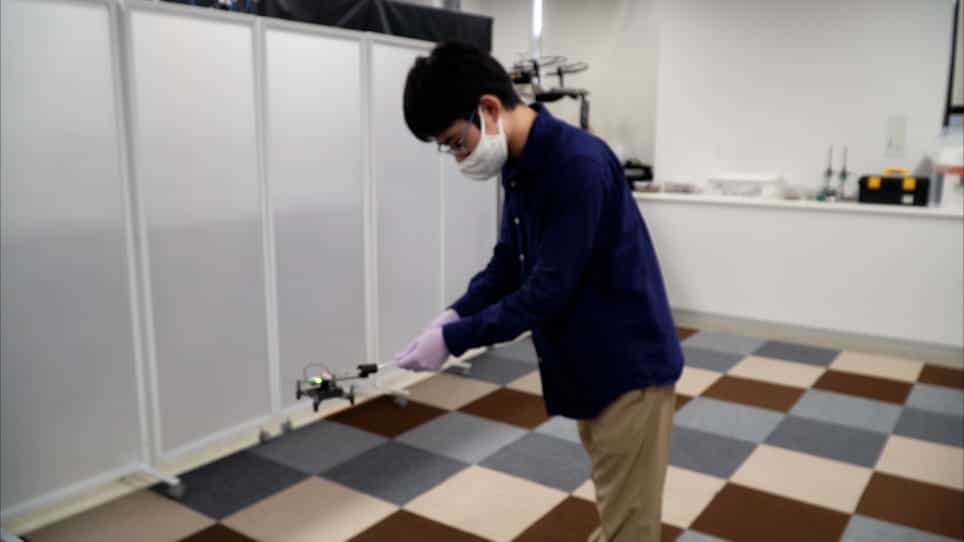

Electroantennography-based Bio-hybrid Odor-detecting Drone using Silkmoth Antennae for Odor Source Localization
Published on: August 27, 2021
Whisker-based tactile flight for tiny drones
Chaoxiang Ye1, Guido de Croon2, Salua Hamaza3
1BioMorphic Intelligence Lab, Faculty of Aerospace Engineering, TU Delft, Delft, The Netherlands. C.Ye@tudelft.nl.

Abstract:
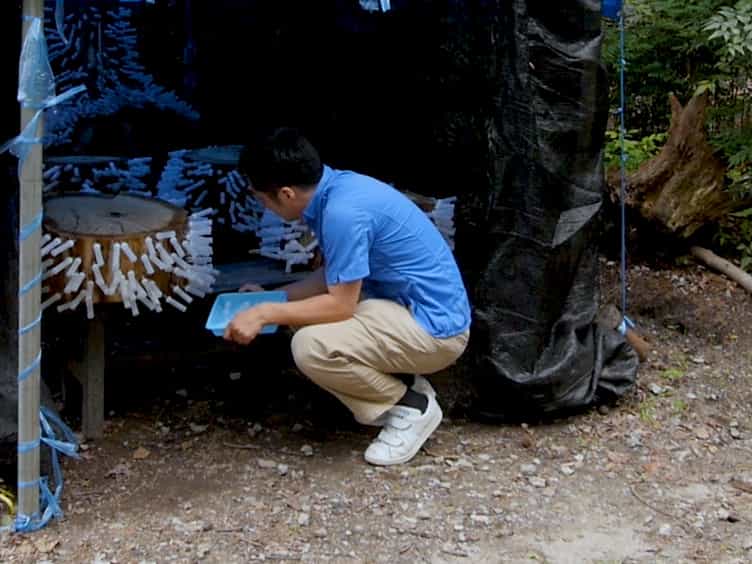
Tiny flying robots hold great potential for search-and-rescue, safety inspections, and environmental monitoring, but their small size and limited computational resources constrain onboard sensing capabilities. Inspired by animals such as rats and moles which rely on lightweight whiskers to navigate and perceive their surroundings through touch, we present a 3.2-gram whisker-based tactile sensing apparatus that enables tiny drones to perceive and interact with their environment through gentle physical contact, even in complete darkness. The apparatus employs barometers at the base of each whisker to estimate contact depth in flight, enabling obstacle localization while minimizing contact-induced destabilization. To compensate for sensor noise and drift during sustained contact, we develop a tactile depth estimation pipeline that achieves millimeter-scale depth estimation accuracy. Together, these innovations enable tiny drones to autonomously avoid obstacles, contour surfaces, and explore confined spaces, guided by onboard tactile sensing across both rigid and soft environments. Running entirely onboard a microcontroller with just 192 KB of memory, our system demonstrates autonomous tactile flight across various scenarios. This bio-inspired approach extends perception for mobile robots beyond vision, opening new possibilities for autonomous operations in visually degraded and GPS-denied environments.
Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:02
Gyroscope
 01:19
Drift Velocity