Related Experiment Video
Updated: Sep 23, 2026
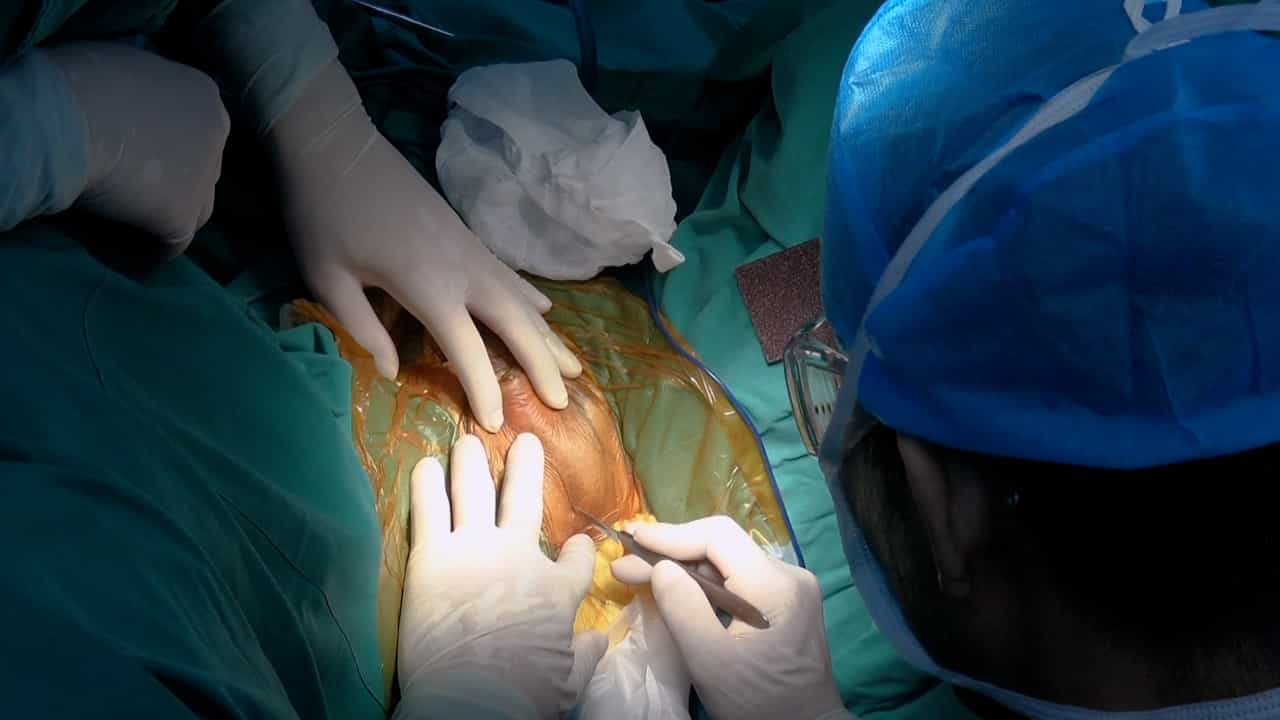

Transcorporal Artificial Urinary Sphincter Cuff Placement in a Case Requiring Revision for Urethral Atrophy
Published on: June 16, 2022
A New Double Uniform Radial Clamping Artificial Anal Sphincter Device
Minghui Wang1,2, Yinhao Wang1,2, Siyuan Chen1,2
1Institute of Intelligent Rehabilitation Engineering, University of Shanghai for Science and Technology, Shanghai, China.

Objectives:
Artificial anal sphincters are an important option for patients with severe anal incontinence. However, existing artificial anal sphincters still present safety and effectiveness concerns in animal experiments and clinical applications. Based on these problems, a novel double uniform radial clamping artificial anal sphincter device was proposed.
Methods:
In this study, a novel double uniform radial clamping artificial anal sphincter device was designed. The constant-force characteristics of the device and its mechanical interaction with intestinal tissue were evaluated using finite element analysis.
Results:
The simulation results showed that the maximum equivalent stresses on the outer and inner surfaces of the intestinal wall were approximately 147 and 159 kPa, respectively. Regions of elevated equivalent stress were mainly localized near the bilateral clamping regions. The reaction force of the shape memory alloy constant-force mechanism reached a peak value of 6.23 N at a displacement of 2.48 mm. Over the displacement range of 3.25-6.35 mm, the reaction force remained between 5.78 and 6.07 N, with a mean value of approximately 5.89 N, indicating an approximately constant-force plateau.
Conclusions:
The proposed artificial anal sphincter provides a novel double uniform radial clamping design. Finite element analysis characterized the local mechanical response of the intestinal wall and the constant-force behavior of the device, providing preliminary mechanical information for further experimental optimization and in vivo validation.