Related Experiment Video
Updated: Sep 23, 2026
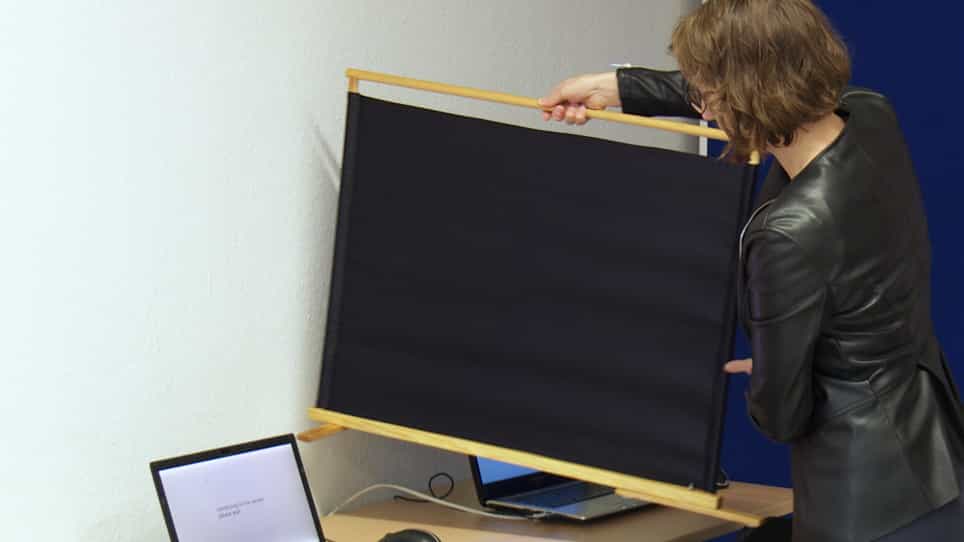

The HoneyComb Paradigm for Research on Collective Human Behavior
Published on: January 19, 2019
Cluster dynamics in a two-group Stuart-Landau model analyzed by the second-order phase reduction
Yernur Baibolatov1, Oleh E Omel'chenko2, Michael Rosenblum2
1Department of Physics, Kazakh National Women's Teacher Training University, Aiteke Bi str. 99, 050040 Almaty, Kazakhstan.

Abstract:
We analyze cluster states in an ensemble of Stuart-Landau oscillators with two subpopulations of different frequencies. Our main goal is to compare the descriptions of the system's dynamics obtained via the standard first-order phase approximation and the second-order phase reduction. We demonstrate that the second-order model not only provides quantitative improvements in the description but also reveals new dynamical states not present in the standard Kuramoto theory. In particular, it describes bistability of synchronous states in the minimal setup of two coupled oscillators and the existence of three-cluster states, forbidden in the first-order phase description by the Watanabe-Strogatz theory. The very good agreement between the second-order approximation results and the results of numerical simulations of the original Stuart-Landau network highlights the usefulness of high-order phase-reduction models.
More Related Videos

Related Concept Videos
 01:12
Reduced Mass Coordinates: Isolated Two-body Problem
 01:18
Second Order systems II
If ζ...
 01:20
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...
 01:13
Parameters Affecting Nonlinear Elimination: Zero-Order Input, First-Order Absorption and Two-Compartment Model
When a drug is administered through a constant intravenous infusion and eliminated via nonlinear pharmacokinetics, it follows zero-order input. For example, oral drugs undergo first-order absorption upon administration and are eliminated through nonlinear pharmacokinetics.
In the case of subcutaneously administered drugs,...
 01:18
First Law: Particles in Two-dimensional Equilibrium
Newton's first law tells us about the...
 01:23
Stability of Equilibrium Configuration
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...