Time series learning in a many-body Rydberg system with emergent collective amplification
Related Experiment Video
Updated: Sep 25, 2026
Gradient Echo Quantum Memory in Warm Atomic Vapor
Published on: November 11, 2013
Zongkai Liu1,2, Qiming Ren3,4, Chris Nill5,6
1State Key Laboratory of Quantum Optics Technologies and Devices, Institute of Laser Spectroscopy, Shanxi University, Taiyuan, China. lzk1997@sxu.edu.cn.

Abstract:
Interacting Rydberg atoms constitute a versatile platform for the realization of non-equilibrium states of matter. Close to phase transitions, they respond collectively to external perturbations, which can be harnessed for technological applications in the domain of quantum metrology and sensing. Owing to the controllable complexity and straightforward interpretability of Rydberg atoms, we can observe and tune the emergent collective amplification. Here, we investigate the application of an interacting Rydberg vapour for the purpose of time series prediction. The vapour is driven by a laser field whose Rabi frequency is modulated in order to input the time series. We find that close to a non-equilibrium phase transition, where collective effects are amplified, the capability of the system to learn the input becomes enhanced. This is reflected in an increase of the accuracy with which future values of the time series can be predicted. Using the Lorenz time series and temperature data as examples, our work demonstrates how emergent phenomena enhance the capability of noisy many-body systems for data processing and forecasting.
Related Concept Videos
 01:11
Types of Responses of Series RLC Circuits
 01:18
Second Order systems II
If ζ...
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:20
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:30
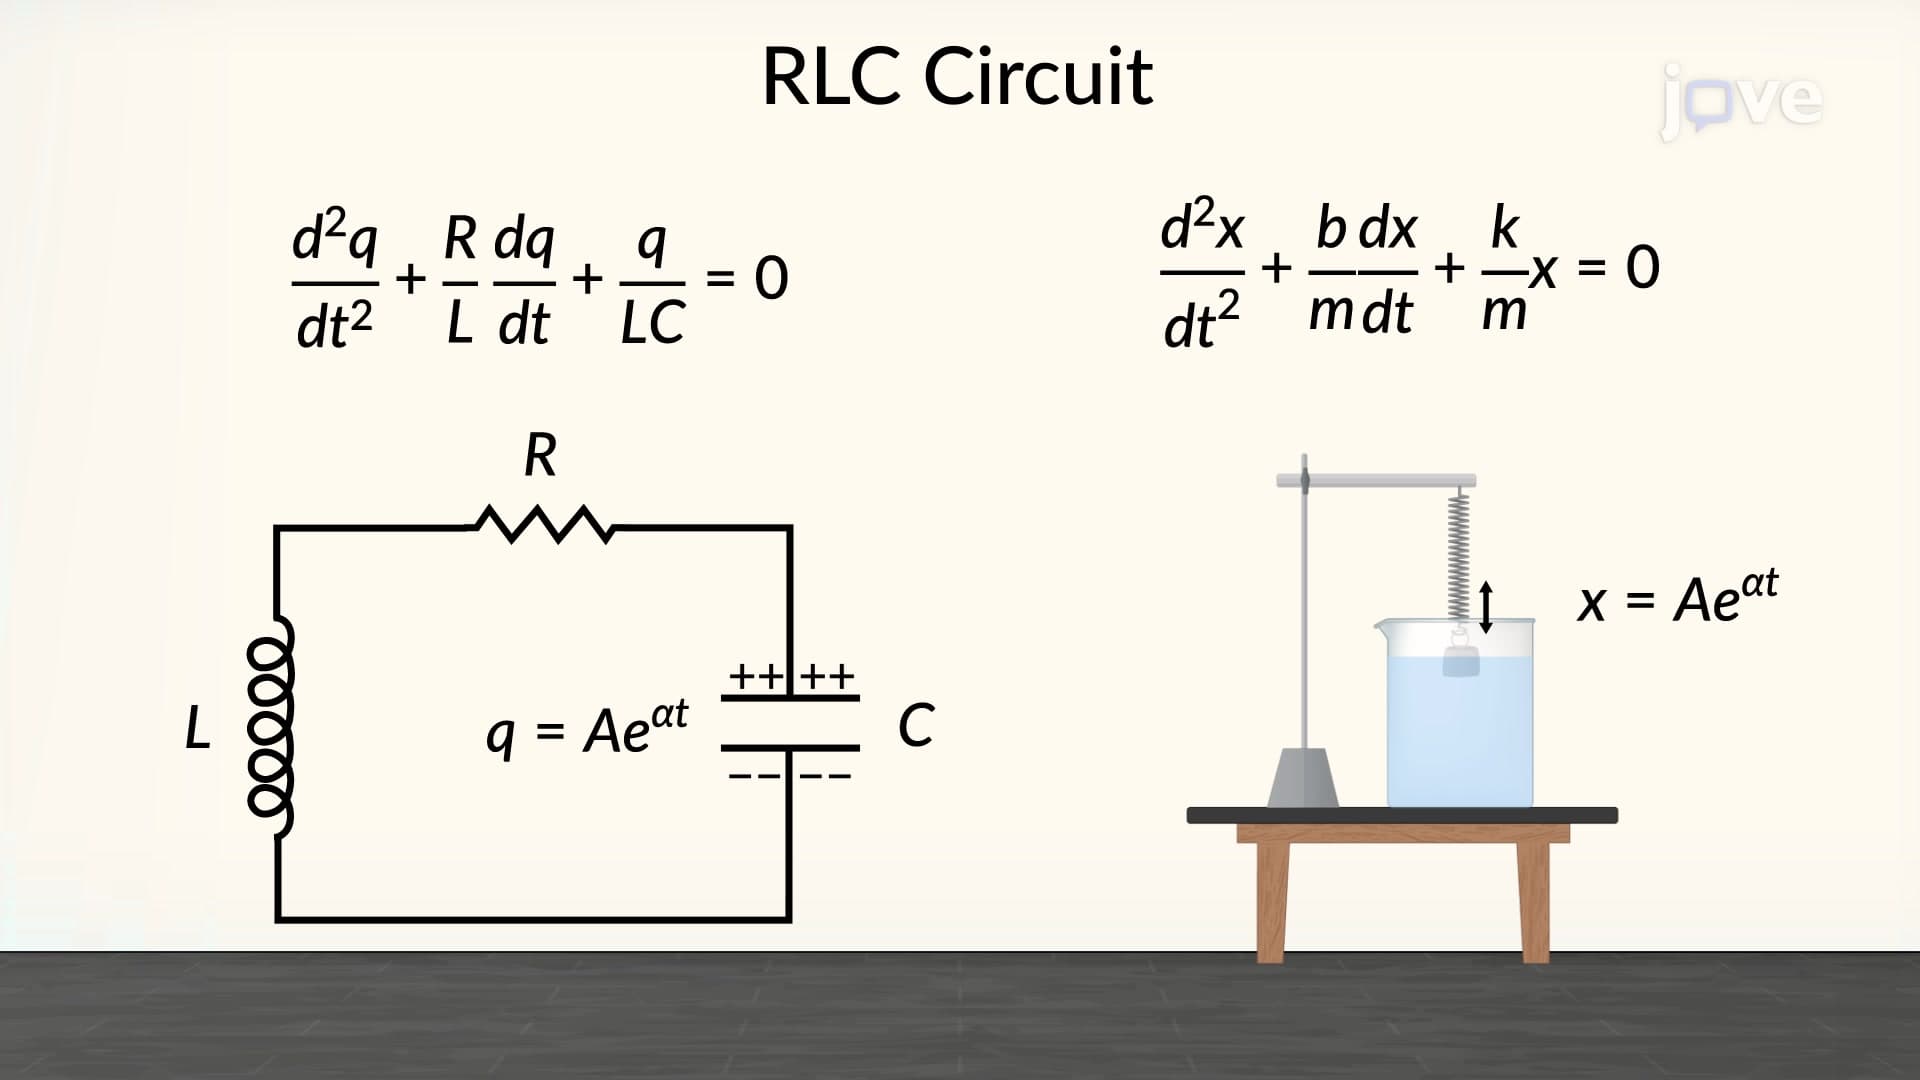
RLC Circuit as a Damped Oscillator
Consider a series RLC circuit. Here, the presence of resistance in the circuit leads to energy loss due to joule heating in the resistance. Therefore, the total electromagnetic energy in the circuit is no longer constant and decreases with time. Since the magnitude of charge, current, and potential difference continuously decreases, their oscillations are said to be damped. This is...