Related Experiment Video
Updated: Sep 25, 2026
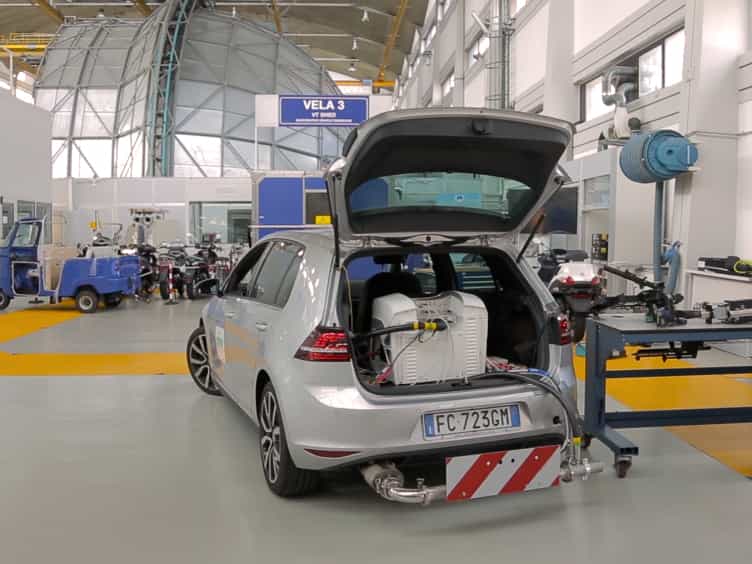

Implementation of Portable Emissions Measurement Systems (PEMS) for the Real-driving Emissions (RDE) Regulation in Europe
Published on: December 4, 2016
Operating-environment risk identification for dangerous goods transport vehicles based on unsafe driving behaviors
Longyue Zhu1, Dalin Qian1, Sixian Li2
1MOE Key Laboratory for Urban Transportation Complex Systems Theory and Technology, Beijing Jiaotong University, Beijing, China.

Objective:
Operating environments, including road infrastructure, traffic flow, weather conditions, and mileage, directly influence driving behavior. Because driving behavior ultimately determines road traffic safety, it is critical to determine whether operating environments create conditions that may induce unsafe driving practices. However, the relationship between operating environments and driving behavior is random, dynamic, and complex. These characteristics make it challenging to identify operating environment risks that are specific to driving behavior. To this end, this study develops a model to identify operating environment risks for road vehicles that transport dangerous goods.
Methods:
This study uses multi-modal data collected from in-vehicle terminals and integrates road, traffic, and weather information from MapInfo software, map APIs, and online weather pages to construct a dataset of vehicle operating environments. It then incorporates an enhanced attention mechanism to develop an explainable feature interaction graph neural network (AFi-GNN) that identifies operating environment risks.
Results:
The proposed model outperforms the baseline models, achieving an AUC of 0.9682, an accuracy of 0.8724and a F1-score of 0.8892. The attention and SHAP results indicate that road- and traffic-related variables played important roles in model discrimination. Traffic-density level, nearby vehicle count, road type, speed, and driving distance were identified as important operating-environment indicators, while their relative importance and contribution directions differed across unsafe driving behavior categories.
Conclusion:
The results suggest that operating-environment risk identification for dangerous goods transport vehicles should be understood from the perspective of multi-factor interaction patterns rather than from a single indicator alone. The proposed AFi-GNN provides an interpretable modeling framework for identifying behavior-specific operating-environment risk patterns and may support high-risk scenario screening and active safety management for dangerous goods transport vehicles.
Related Concept Videos
 01:28
Survey Safety
 01:26
Pharmaceutical Poisoning: Potential Scenarios
 01:21
Behavior Modification
A real-world application of operant conditioning principles is applied...
 01:07
Narcolepsy
 01:24
Drug Toxicity: Risk factors