Related Experiment Video
Updated: Sep 25, 2026
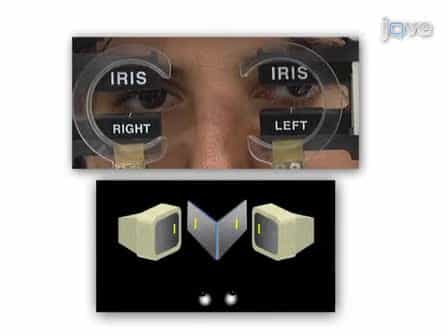

VisualEyes: A Modular Software System for Oculomotor Experimentation
Published on: March 25, 2011
EgoMotion: Hierarchical Vision-Language Learning and Diffusion for Egocentric Motion Generation

Abstract:
Faithfully modeling human behavior in dynamic environments is a foundational challenge for embodied intelligence. While conditional motion synthesis has achieved significant advances, egocentric motion generation remains largely underexplored due to the inherent complexity of first-person perception. In this work, we investigate Egocentric Vision-Language (Ego-VL) motion generation. This task requires synthesizing 3D human motion conditioned jointly on first-person visual observations and natural language instructions. We identify a critical optimization challenge in effectively transferring vision-language understanding to motion generation. Directly optimizing vision-language semantic learning and kinematic motion synthesis in an end-to-end manner can lead to optimization interference, limiting the quality of generated motions. To address this challenge, we propose EgoMotion, a two-stage framework for vision-language-guided egocentric motion generation. In the first stage, a vision-language model (VLM) learns motion-aware semantic representations from multimodal inputs through autoregressive motion token prediction. In the second stage, these learned VLM representations serve as expressive conditioning signals for a diffusion-based motion generator. By performing iterative denoising within a continuous latent space, the generator synthesizes physically plausible and temporally coherent trajectories. Extensive evaluations demonstrate that EgoMotion achieves state-of-the-art performance and produces motion sequences that are both semantically grounded and kinematically superior to existing approaches.

Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:30
Vector Functions and Motion: Problem Solving
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:18
Hierarchy of Motor Control
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...