Related Experiment Video
Updated: Sep 26, 2026
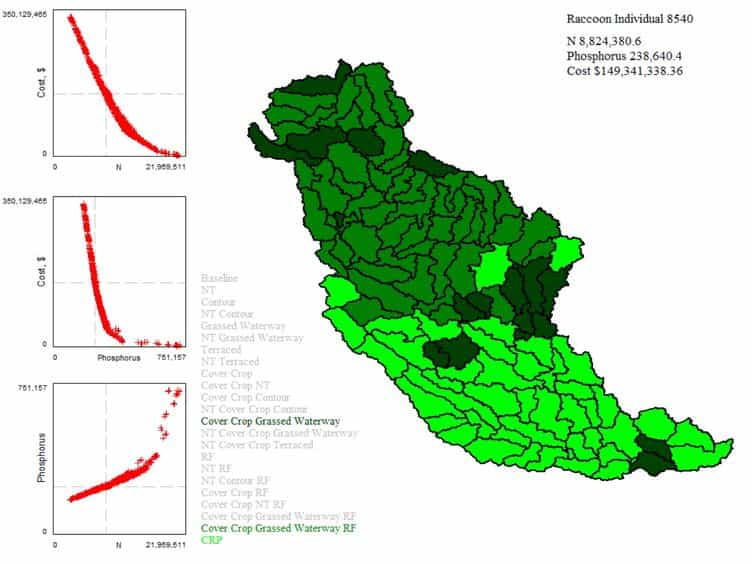
Spatial Multiobjective Optimization of Agricultural Conservation Practices using a SWAT Model and an Evolutionary Algorithm
Published on: December 9, 2012
A Multi-Strategy Enhanced Crested Porcupine Optimizer with Targeted Defense Mechanism Improvement for Global
Zhaoyong Fan1, Xi Li1, Zhenhua Xiao1
1School of Information and Artificial Intelligence, Nanchang Institute of Science and Technology, Nanchang 330108, China.

Abstract:
Metaheuristic algorithms are widely used to solve complex optimization problems, but the trade-off between exploration and exploitation often limits their performance. The Crested Porcupine Optimizer (CPO) employs four bio-inspired defense mechanisms and achieves competitive performance, but it still tends to converge prematurely, initialize populations poorly, and rely on static parameters that cannot adapt to different phases. This paper proposes a Multi-Strategy Enhanced Crested Porcupine Optimizer (MSCPO) with four phase-targeted enhancement strategies: (1) Kent Chaos Opposition-Based Learning Initialization (KCOL) improves the initial population distribution through chaotic-weighted reflection; (2) Arctic Puffin Optimization (APO)-Inspired Dual-Modal Evasion (APO-DME) reduces dependence on the global best solution and increases population diversity through dual-mode differential perturbation; (3) Adaptive Dual-Differential Perturbation (ADDP) refines the search by combining population diversity and elite guidance information; (4) Periodic Dynamic Adaptive Perturbation (PDAP) enhances exploitation through periodic trigonometric perturbation and a fitness-conditioned update rule. These strategies interact across the optimization process to strengthen each defense mechanism at the appropriate phase. On the CEC 2017 and CEC 2022 benchmark suites, MSCPO achieves the best overall mean rank among all compared algorithms, with an overall rank of 2.638 on CEC 2017 and 2.375 on CEC 2022. A full-factorial ablation over all 16 strategy combinations confirms that each strategy contributes positively: removing any single strategy degrades the overall mean rank, and the complete MSCPO achieves the best mean rank (3.34), significantly outperforming all single-strategy variants (Wilcoxon signed-rank test, p < 0.001). To verify the practical applicability of MSCPO, the algorithm is further applied to three engineering design problems: step-cone pulley design, hydrostatic thrust bearing design, and robotic gripper design. MSCPO ranks first on the hydrostatic thrust bearing problem, second on the step-cone pulley problem, and third on the robotic gripper problem. Future work will explore adaptive population sizing to further improve the scalability of MSCPO on very high-dimensional problems.
Related Concept Videos
 00:48
Optimal Foraging
 01:26
Optimization Problems
 01:30
Lagrange Multipliers: Problem Solving
 01:09
Decision Making: P-value Method
First, a specific claim about the population parameter is proposed. The claim is based on the research question and is stated in a simple form. Further, an opposing statement to the claim is also stated. These statements can act as null and alternative hypotheses: a null hypothesis would be a neutral statement while the alternative hypothesis can have a...
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
 01:29
Mechanistic Models: Compartment Models in Algorithms for Numerical Problem Solving
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...