Related Experiment Video
Updated: Sep 26, 2026
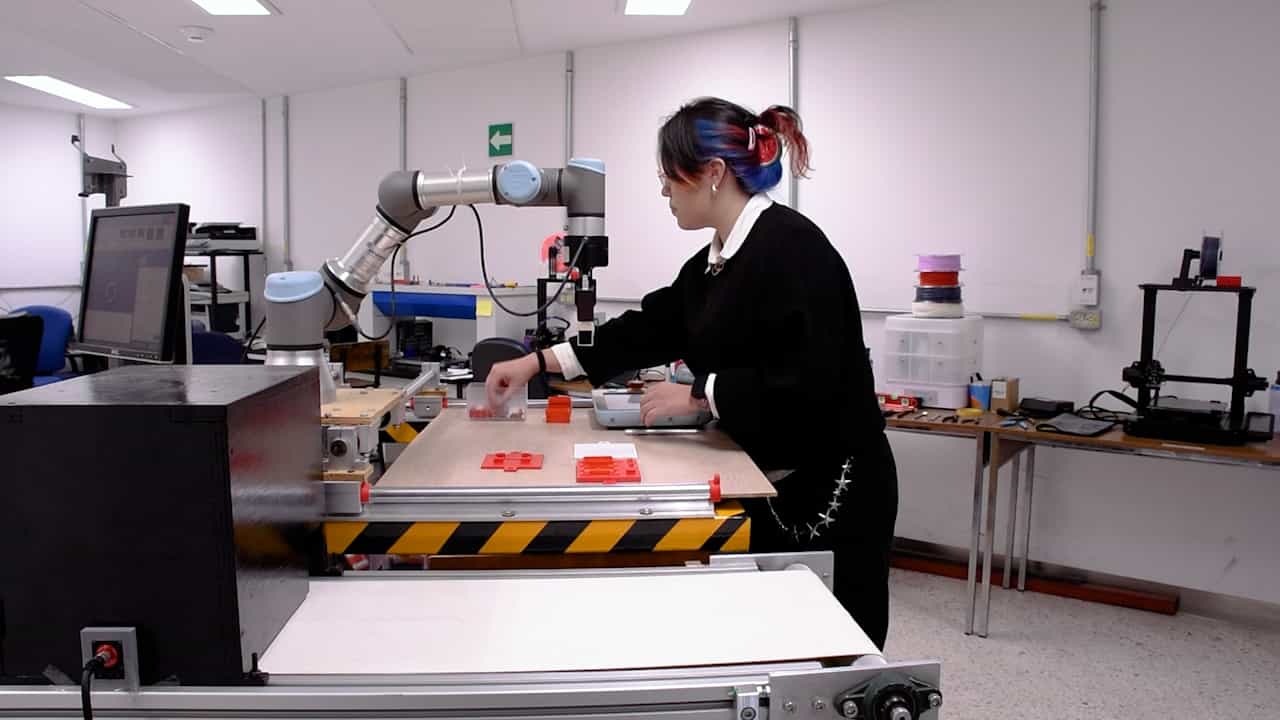

Simulation of a Scaled Assembly Process with Collaboration of a Robotic Arm and Monitoring through a Vision System for Quality Control
Published on: August 29, 2025
Close-Proximity Vision-Guided Control and Performance Evaluation of a Mobile Robot for Sit-to-Stand Assistance

Abstract:
A safe sit-to-stand (STS) transfer is an essential daily movement, but it can be difficult for older adults with reduced strength, balance, or coordination. Cost-effective STS assistance is therefore important for supporting independence. This paper presents a close-range, single RGB-D-camera solution for estimating pelvis motion and controlling a compact STS-assistive rollator. The robot provides two modes: a predefined fifth-order trajectory-following mode and a vision-adaptive mode that modulates the same nominal motion according to real-time pelvis-robot distance. In a feasibility study with healthy adults (N=6 analyzed), both modes reduced lower-limb loading relative to unassisted STS. The predefined mode followed a fixed 3-second trajectory. This trajectory was selected based on our previous SkyWalker implementation and the healthy-adult STS timing literature, and it served as a baseline that provided larger and more consistent support. In contrast, the vision-adaptive mode synchronized the robot timing with the user's real-time pelvis motion, allowing users to stand at their preferred pace and resulting in lower handle loads and smaller compensatory trunk motion. These results suggest that the two modes may serve different assistance needs, with predefined support favoring stronger offloading and vision-adaptive support favoring user-paced interaction.