Related Experiment Videos
SMFormer: A spatial-motional transformer for two-view correspondence pruning
Shunxing Chen1, Xiangyang Miao1, Yunmei Zhao2
1School of Computer Science and Technology, Tongji University, Shanghai, 201804, China.

Abstract:
In this paper, we propose a Spatial-Motional Transformer Network (SMFormer) for two-view correspondence pruning. Compared to most existing methods that mainly focus on spatial coordinates for correspondence learning, SMFormer jointly considers correspondence reliability and motion consistency by integrating feature screening and sparse motion representations. Specifically, we develop a robust feature learning framework that combines feature screening and spatial-motional interaction to enhance correspondence representation under heavy outlier contamination. We present a Feature Screening Transformer Block (FSTB) to selectively suppress low-confidence features and enhance feature reliability under heavy outlier contamination. In addition, we design a Spatial-Motional Interaction Module (SMIM) to perform cross-stream interaction and fusion between correspondence features and motion features. This module employs graph-based cross-attention aggregation over sparse spatial and motion graphs to further improve contextual feature representation. The proposed FSTB and SMIM collaboratively improve correspondence pruning by enhancing feature reliability and exploiting complementary spatial-motional cues. In consequence, our proposed SMFormer outperforms state-of-the-art methods by a significant margin, achieving a remarkable 9.75% improvement under an error threshold of 5∘ over the second-best method for the relative pose estimation task on an unknown outdoor dataset. Our source code will be available at: https://github.com/CSX777/SMFormer.
Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:12
Transformation of Plane Strain
Under plane strain conditions, typical for members where one dimension significantly exceeds the others, deformations and resultant strains are...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:27
Curvilinear Motion: Normal and Tangential Components
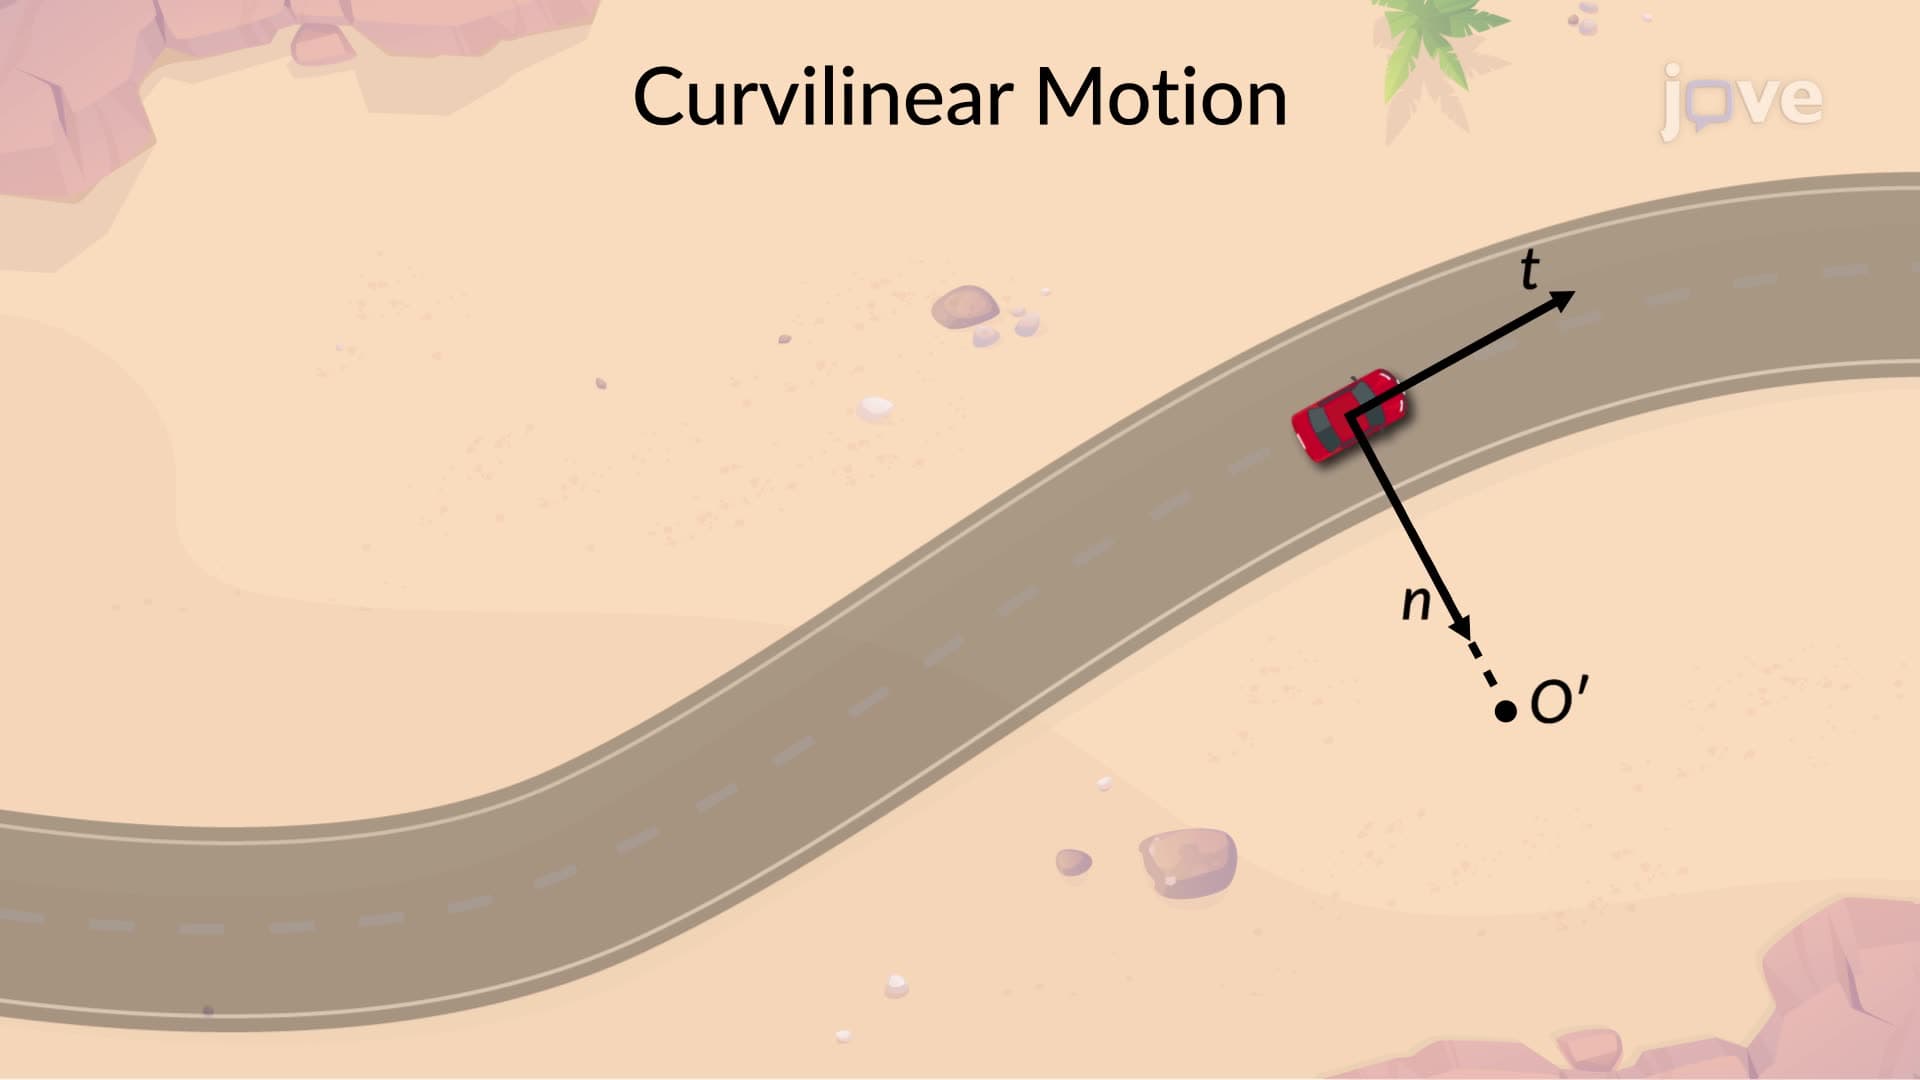
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...