Related Experiment Video
Updated: Sep 27, 2026
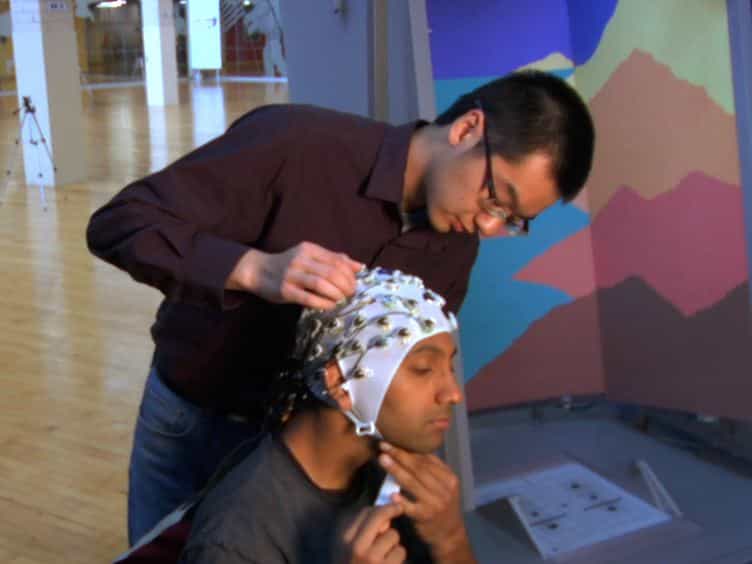

Simultaneous Scalp Electroencephalography (EEG), Electromyography (EMG), and Whole-body Segmental Inertial Recording for Multi-modal Neural Decoding
Published on: July 26, 2013
SARM: Benchtop Evaluation of a Task-Driven Two-Stage Deep Learning Framework for Stimulation Artifact Removal in

Objective:
This manuscript introduces a novel two-stage training framework and deep-learning model for recovering peripheral neural signals contaminated by electrical stimulation artifacts. The approach is designed to preserve motor-decoding accuracy during simultaneous neural recording and stimulation.
Methods:
In this work, We combine supervised learning with policy-gradient reinforcement learning based on REINFORCE using paired signals generated by a custom in-house analog data-synthesis system. A Convolutional Long Short-Term Memory (ConvLSTM) network captures spatial and temporal dependencies across multi-channel recordings. The model first undergoes supervised signal-reconstruction training and is then fine-tuned using Self-Critical Sequence Training (SCST) with task-driven rewards derived from motor-decoding performance. This strategy enables optimization despite non-differentiable downstream signal processing and feature extraction.
Results:
Using previously recorded peripheral nerve signals from an amputee participant with experimentally injected artifacts across multiple stimulation amplitudes, the proposed framework improved artifact suppression and signal recovery compared with conventional blanking and linear interpolation. It restored signal integrity across multiple channels and improved motor-decoding accuracy, particularly under high-amplitude stimulation.
Conclusion:
These results demonstrate the feasibility of task-driven artifact removal for peripheral neural decoding in a controlled benchtop setting. The proposed hybrid training approach provides a practical means of optimizing deep neural networks using decoding-aligned objectives. However, validation used replayed neural recordings and experimentally injected artifacts. Further in vivo closed-loop evaluation is needed to account for physiological electrode-tissue interactions, biological artifacts, and real-time sensorimotor feedback. This work provides a foundation for developing robust bidirectional peripheral neural interfaces that combine motor decoding with sensory feedback.
